Vzdálenost
Zvolte jednotku vzdálenosti: Metry(m), Stopy(ft), Míle(mi) nebo Kilometry(km)
Rychlost
Zvolte jednotku rychlosti: m/s, ft/s, mph nebo km/h
Zrychlení
Zvolte jednotku zrychlení: m/s² nebo G
Let 1113

Flight 1113

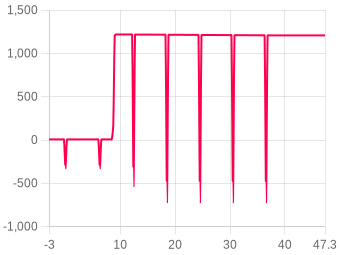
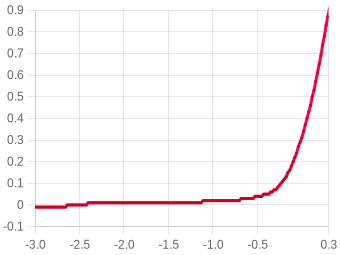
Mercury V1 Rev 2 · firmware 2.1Zjištěn testovací letZjištěn testovací letToto se jeví jako testovací nebo neraketový let (např. hod rukou, vakuový/tlakový test). Data nemusí představovat skutečný let rakety.High altitude with minimal acceleration (vacuum/pressure test)Reached high altitude impossibly fastNo motor burnout detectedGyroscope not responding (all zero readings)Accelerometer frozen/saturated (constant readings)Probably recovered log (detected)Probably recovered log (detected)This log looks like it was rebuilt from flash after a mid-flight reset, based on missing end-of-flight values. The altimeter firmware on this flight is older than v2.31 so this has been inferred rather than flagged by the device.
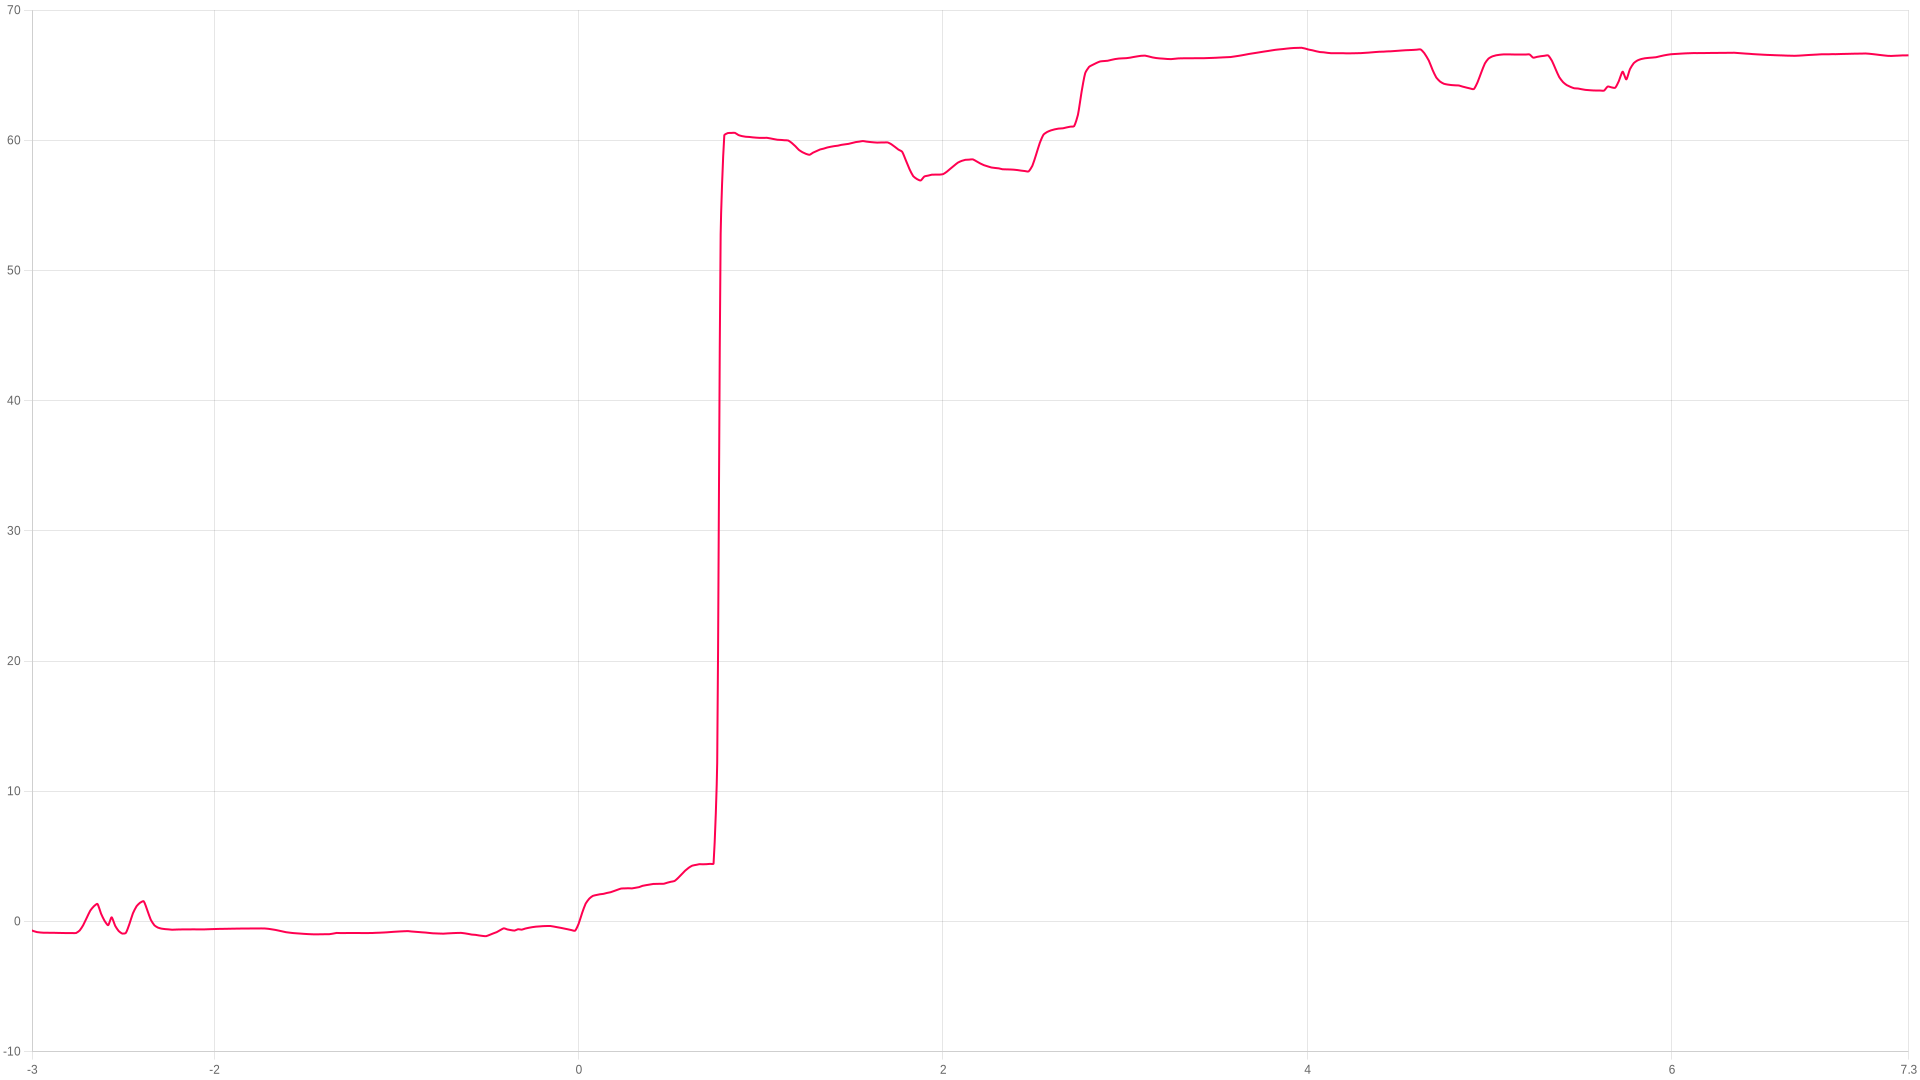
Apogeum
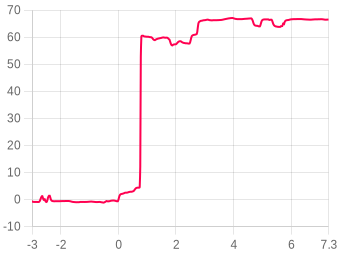
60.58m
0.86 s after launch
Max. stoupání
224.4m/s
peak ascent
Max. při spalování
0G
during the burn
Přistání
1000000s
touchdown 0.05 m/s
ZOOM TO
s
s
Zobrazit události
Upravit tepl. & tlak ?
Obrázek
Přiblížení
Klikněte a táhněte nebo použijte gesto
Porovnat let ?
Shrnutí letu

The flight, moment by moment

Liftoff
0 s
Náklon rampy115.56°
Thrust calc pad tilt
Vyhoření (první)
0 s
Výška-0.19 m
Rychlost0.000 m/s
Apogeum
0.85 s
Výška60.58 Metry
Max. náklon do vyhoření0.00°
Přistání
999999.99 s
Výška0 m
Max. klesání-10.76 m/s

Stabilita0.1%Špatný

Náklon při dohoření (20%)0
20% · Launch tilt 0°
Klápění/zatáčení (30%)0
25% · Coning 0/0°/s
Coning · boost (25%)0
25% · Spin 0°/s
Přímost tahu (15%)0
30% · Thrust 0%
Baterie & teplota 18% → 0% · Teplota začátek 22.45 → 0 °C · Start po zapnutí 15s

About the stability score

Worked out from the flight log between liftoff and 80% of apogee. It is independent of the angle the altimeter was mounted at, so it measures the flight rather than the fitting.

Náklon při dohoření (20%)20%How close to vertical it left the rod.
Klápění/zatáčení (30%)25%How much the nose swung off the rocket's own axis across the whole ascent.
Coning · boost (25%)25%The same swing during the burn, when it matters most.
Přímost tahu (15%)30%How cleanly the motor pushed along the body.

Spin about the rocket's own axis is not counted against it — a fast, straight spin is stable. The figures beside the score are the raw measurements behind these four.

Výška
Apogeum60.58 Metry
Čas do apogea0.85 s
Výška vyhoření-0.19 m
Výška max. rychlosti60.38 m
Výška vypuštění-0.19 m
Výška přistání0 m
Výška záznamu333.85 m
Rychlost
Max. stoupání224.4 m/s
Max. klesání-10.76 m/s
Při vyhoření0.000 m/s
Rychl. klesání3.290 m/s
Rychl. vypuštění8.91 m/s
Rychl. přistání-0.051 m/s
Zrychlení
Max. při spalování0 G
Max. stoupání0 G
Max. klesání0 G
Prúm. stoupání-0.93 G
Prúm. spalováníN/A
Časy
Vyhoření (první)0 s
Apogeum0.85 s
Možné vypuštění0 s
Přistání999999.99 s
Výstup #1 ZAP0 s
Výstup #1 VYP0 s
Úhly
Náklon rampy115.56°
Thrust calc pad tilt
Max. náklon do vyhoření0.00°
Klápění při startu137.62°
Klopní při startu54.25°
Max. rotace (spal.)0 dps
Prúm. rotace (spal.)0 dps
Recovery
Single deploy
No dual deploy detected on this flight.
Obecné
Datum nahrání22-Jan at 04:22
Datové vzorky565
Celkový čas záznamu11.200 s
Prúm. vzorký/s50.4
Počet blokování10
Start po zapnutí15s
Referenční osaZ
Baterie & teplota
Baterie začátek18%
Baterie konec0%
Teplota začátek22.45°C
Teplota konec0°C
Teplota MT1 start0°C
⚠ Nízká baterie — nabijte před dalším letem
Pravidla výstupu
Žádná pravidla
Uživatelské poznámky
Žádné poznámky
Přidejte toto zařízení ke svému účtu pro úpravy
Youtube video
Žádné video
Přidejte toto zařízení ke svému účtu pro úpravy
Obrázky letu 0
Žádné obrázky
Motory letu
K tomuto letu nebyly přidány žádné motory
Přidejte toto zařízení ke svému účtu pro úpravy
Propojená raketa
K tomuto letu není připojena žádná raketa
Pravidla výstupu
Pravidla umožňují Mercury provádět akce na základě podmínek letu. Každé pravidlo má až 4 podmínky (A-D).
Žádná pravidla
Přiřazení motoru (BETA)
No motor matches, try refreshing the page.

Linked flights

Connect flights that belong together: a second altimeter flown in the same rocket, or the same rocket flown again. Linked flights appear on each other’s pages.

No linked flights yet.

Místo startu, datum a čas

Klikněte na mapu pro označení místa startu. Přepínejte mezi mapou a satelitním pohledem.

Imagery © Esri, Maxar, Earthstar Geographics

Klikněte na mapu · Přetáhněte pro úpravu

Canopy height from the Meta and WRI High Resolution Canopy Height Maps v2 (Meta and World Resources Institute, 2026; source imagery © 2016 Vantor), used under CC BY 4.0. Ground elevation built from Terrain Tiles (Mapzen and AWS Open Data), derived from 3DEP and GMTED courtesy of the U.S. Geological Survey, SRTM courtesy of NASA, and ETOPO1 courtesy of NOAA. Map and imagery credited on the view above.

No launch site has been set for this flight.

Animace dat letu

FLIGHT 1113

60.58 Meters

ALTITUDE
0.00m
VELOCITY
0.00m/s
ACCEL
0.00G
TILT
0.00°
PITCH
0.00°
ROLL
0.00°
YAW
0.00°
TIME
0.00s
AWAITING LAUNCH
ALT
altimetercloud.com
LAUNCH T+0.00s LANDING

BURNOUT

Motor burn complete

Poznámka: Animace letu vyžaduje montáž výškoměru v pevné orientaci. Kalibrujte senzory pro nejlepší výsledky.
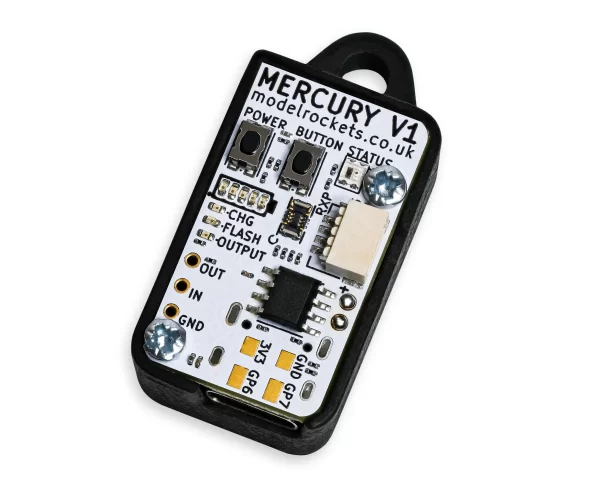
Mercury V1
Revision 2
Mercury V1
Tento let byl proveden na Mercury V1.
The hardware
Verze hardwareRev 2
Verze software2.1
Naposledy online27-Jan at 01:02
Snímač tlakuBosch BMP 390
Akcelerometr32G 3-axis
Gyroskop2000 dgps 3-axis
MagnetometrN/A

Settings, as they were for this flight

Obecná nastavení letu
Předpovězený tlak
i
Set this to your local forecast pressure at sea level. This will offer you slightly improved accuracty for your flight, although it's not 100% essential every little helps!

Xcweather.co.uk is a decent place to grab pressures from for your location and time.
999 mbar
Detekce startu
i
This is the altitude above the launch pad altitude where the altimeter will trigger itself into recording / flight mode.

The altimeter keeps a constant average of the pressure while waiting for launch, it uses a simple algorithm and the pre-flight buffers to do this. The most recent 120 samples (~4 seconds) are ignored so your pre-trigger altitude won't effect the ground baseline.

For almost all uses we suggest keeping this on the 25 Meter (~82 feet) default settings. If you want to test your altimeter by throwing it in the air, or are planning a very low flight you may want to lower the setting.
1 meters
Sample ratio
i
The altimeter runs at 50Hz however you can record every sample or every X samples in order to extend the log time. For example if you set the ratio to 1 it will save 1:1 samples, or if you set it to 3 it will save 1 in 3 samples.
1:1 (50Hz)
Max samples
i
This is the maximum samples the altimeter will log per flight. When it reaches this amount it will stop and save the recording.
12000
Recording stop
i
This setting is how the altimeter decides to stop recording. You can choose either 450 (~9s) or 900 (~18s) samples stable or it will record until the max samples limit unless you press the BUTTON in Manual stop mode.

The samples stable method waits for the devices altitude not to change for the set number of samples. This is defined by not changing by more than +/- 1.0 meters for 98% of the samples, it's a reliable method to stop the recording after landing within 8-10 seconds (300 sample) or 16-20 seconds (600 sample).
Auto: 450 samples stable (~9s)
Oversampling
i
Oversampling is a internal setting of the BMP 390 pressure sensor. It is how many samples are taken for each reading. By taking multiple samples for each pressure reading the altimeter reduces noise and increases the resolution of the output.

The sensor can run at 50 samples per second in 4X mode, so we suggest leaving it in this mode as it will offer the highest accuracy.
8x Oversampling
IIR filter
i
The IIR filter is another internal sensor for the BMP390 pressure sensor. It is a Infinite impulse response filter used to enhance pressure measurement accuracy by reducing noise. It's primarily for smoothing out rapid pressure changes.

We suggest not setting this too high as it will cause delay to changes in altitude if set very high.
COEFF 7
Pressure filter
i
This filter is a software Kalman filter that runs on the altimeters processor.

The Kalman filter uses a prediction step based on a system model and then a correction step using new measurements to refine its estimate, it creates accurate most certain results from data with noise in it.
Kalman 2 (default)
Lockout time
i
The Lockout time is how long the altimeter should stop making decisions and taking actions if it detects unusual high speed altitude changes that are unexpected.
These false readings can be caused by ejection charges (if the altimeter is in the same compartment as the motor ejection gases) or even when you transition to Mach speeds and can give false readings of altitude changes.

When these events are detected the system enters Lockout for the specified time while it stabalises. This effects things like triggering the output, or calculating other data.
750ms
Lockout change
i
This is how we detect a lockout. If the pressure changes by this much in a single sample downwards (pressure increase, lower altitude) then it's likely to be a false reading. Multiply the setting by 32 to get the speed in meters per second that it will trigger at.
1.5 meters
Sync sensors
i
The filters on the pressure sensor can cause it to lag very slightly behind the Accelerometer and Gyroscope data. The Sync sensors option detects how far out of sync these sensors are. It then corrects the Acceleration and Gyroscope readings to match the pressure sensor.
AKTIVOVÁNO
Orientation
i
This is the orientation you intend to install the Altimeter in your rocket. It's needed to ensure completly accurate angles and orientation charts and reports. Check out the Manual for more information on this.
Upwards (text up)
IMU filter
i
The IMU filter, or fusion filter takes the data from each axis of the Gyroscope and Accelerometer to calculate the Pitch, Roll, Yaw and tilt angle from vertical. These filters can build up some discrepency over time so it's important to calibrate your sensors to minimise this.
Madgwick 6-Axis
Launch ALP
i
This is prevention against accidental launch detection.

With this disabled the launch is based only on pressure and something that creates a low pressure can trigger the flight by accident. For example pulling your nose cone off can even trigger it.

With this enabled the rocket also needs to have seen 8 samples (0.25 seconds) of acceleration above this setting in the last 3 seconds as well as the pressure drop to trigger. There is a backup trigger of 1.05 seconds of altitude being above the launch detect setting too.

There are very few situations where this option would cause issues, so we suggest leaving it on.
1.4G
Launch lock
i
When enabled, the altimeter locks out recording for a set period after power on to prevent false triggering during setup.
DISABLED
Static temperature
i
A fixed temperature value used for altitude calculation when the external temperature sensor is disabled or not connected.
8.00 °C
Temp sensor
i
If an external MT1 temperature sensor is connected, this controls whether it is used for logging only or also for altitude calculations.
DISABLED
Nastavení výstupu
Výstup 1 aktivní
i
Disable or enable the output from being able to turn on or off.
DEAKTIVOVÁNO
Výstup 1 spouštěč
i
After apogee (altitude)
This method triggers when the altitude drops below the set altitude after apogee is detected.
After apogee (time)
This method triggers the defined seconds after apogee is detected.
After launch (altitude)
This method is activated if/once the altimeter exceeds the set altitude after launch.
After launch (time)
This option triggers the defined seconds after launch is detected.
After burnout (time)
This method triggers the defined seconds after burnout is detected.
After apogee (altitude)
Výstup 1 doba zapnutí
i
This is how long the output should trigger ON state when the rules are met.
2000ms
Výstup 1 výška
i
This is the altitude to trigger at if using a trigger method that works on altitude.

For example if you set this to 75m and After apogee (altitude) for the trigger then the output will turn on at 75m on descent above the launch altitude.
0 meters
Výstup 1 čas
i
This is the time variable for output triggers that work on time.

For example if you set this to 3 seconds and After apogee (time) as the trigger then the output will turn on 3 seconds after apogee.
0 seconds
Zámek výšky
i
Altitude lock is a safety feature that prevents the output from triggering if the altitude is below this level when the rules are met.
50.00 m
Zámek úhlu náklonu
i
This is another safety feature. It can be used to disable the output if the rocket has gone too far from vertical.

For example if you set the tilt angle lock to 40 degrees then the output will not fire if the rocket is more than 40 degrees from vertical. To disable set this to 0.
0.00 °
Kalibrace senzorú
Kalibrační offsety použité pro tento let.
Gyroskop⚠ Gyroskop nebyl zkalibrován
X0.000°
Y0.000°
Z0.000°
Akcelerometr
X-29.770 mG
Y-27.110 mG
Z55.880 mG
Nastavení zařízení
TAG zařízení
i
A custom name or tag assigned to this device for easy identification.
Merc8139
Jazyk
i
The language setting configured on the device.
en
Režim vypnutí
i
Controls what happens after recording. Standard shuts down normally, Delayed keeps WiFi on for 30 seconds after landing, Stay on keeps the device powered on.
Delayed 30s
Jas LED
i
The brightness level of the LED indicators on the Mercury. Lower values save battery.
20%
WiFi TX power
i
WiFi transmit power level. Higher gives better range but uses more battery.
5 dBm (default)
Režim spánku
i
Controls whether the device enters low-power sleep when idle.
Normal (sleep when idle)
Monitor baterie
i
Monitors battery voltage during the flight.
DISABLED
Cloud group
i
The cloud group / category this flight is assigned to.
Porty GP6 / GP7
Konfigurace portů GP6 a GP7 pro pyrokanály, serva nebo jiná zařízení.
Channel 6 mode
ON = HIGH
Ch6 min pulse (µs)
1000
Ch6 max pulse (µs)
2000
Ch6 frequency
50 Hz
Ch6 angle ON
170.00°
Ch6 angle OFF
10.00°
Ch6 on time
2.00s
Channel 7 mode
ON = HIGH
Ch7 min pulse (µs)
1000
Ch7 max pulse (µs)
2000
Ch7 frequency
50 Hz
Ch7 angle ON
170.00°
Ch7 angle OFF
10.00°
Ch7 on time
2.00s
Deska servo I2C PCA9685
Configuration for the external I2C PCA9685 servo expansion board. This board provides up to 6 additional servo channels.
No I2C servo board was connected for this flight.
Predikce a vzdušné brzdy
The Mercury can predict apogee while coasting after burnout. These settings control the prediction calculation and optional air brake system.
Dry mass
i
The total mass of the rocket after motor burnout (dry mass). This is used for the ballistic prediction of apogee altitude. Enter the mass without the motor propellant, or the mass at burnout.
0.0200 kg
Drag Cd
i
The aerodynamic drag coefficient (Cd) of the rocket. This is used with the rocket area to calculate aerodynamic drag during coast. A typical model rocket has a Cd of 0.4 to 0.8. You can find this value from OpenRocket or RockSim simulations.
1.000
Reference area
i
The cross-sectional reference area of the rocket in square meters. This is typically the area of a circle with the body tube diameter. For example a 38mm tube has an area of approximately 0.00113 m².
0.00400 m²
Gas constant
i
The specific gas constant for dry air, used in the atmospheric model for altitude and density calculations. The standard value is 287.05 J/(kg·K). You shouldn't need to change this unless you know what you're doing.
287.05 J/(kg·K)
The following settings configure the air brake system.
Air brake enabled
i
Enables or disables the active air braking system. When enabled, the Mercury will deploy air brakes via the configured servo channel to try and reach the target altitude. Firmware 2.1+ required.
OFF (default)
Servo channel
i
Which servo output channel the air brake mechanism is connected to. GP6 and GP7 are the two onboard servo headers, I2C channels are for an external servo expander board.
GP6
Deploy speed
i
The speed at which the air brakes deploy. The Mercury gradually increases the servo angle until the predicted apogee matches the target rather than going full on/off. This setting controls how quickly it ramps up to full braking.
Medium (default)
Target altitude
i
The target apogee altitude in meters. The air brake system will try to slow the rocket so it reaches this altitude.
300.00 m
Over shoot %
i
The percentage over the target altitude to aim for until within 15% of the target. This helps prevent undershooting if the prediction is slightly off early in the coast. For example, with a 1000m target and 5% early adjustment, the Mercury will aim for 1050m until it passes 850m.
5.00%
Activation altitude
i
The air brake system activates after burnout, but won't engage until the rocket has reached this percentage of the target altitude. This prevents the brakes from deploying too early when predictions may be less accurate.
20% (default)

Files

Where the altimeter signs its log, the file carries that signature and a tick beside it. A tick means the data is unchanged since the device wrote it, which is what a record claim needs.
CSV
1113.csv
The log as columns of text. Opens in a spreadsheet, and in every simulator that reads flight data.
44 KB
Adjusted CSV2904 recalculated in your browser
The log recomputed for your own sea-level pressure and temperature. Columns: time, altitude as recorded and adjusted, raw altitude as recorded and adjusted, pressure.

This file is built here from the signed log, so it carries no signature of its own. Anyone verifying a claim should be sent to the flight page and build their own from the original.

Let
Komentáře
Přihlásit se pro komentování.