Odległość
Wybierz jednostkę odległości: Metry(m), Stopy(ft), Mile(mi) lub Kilometry(km)
Prędkość
Wybierz jednostkę prędkości: m/s, ft/s, mph lub km/h
Przyspieszenie
Wybierz jednostkę przyspieszenia: m/s² lub G
Lot 2621

Iris Flight 3

Mercury V1 Rev 1 · firmware 2.40
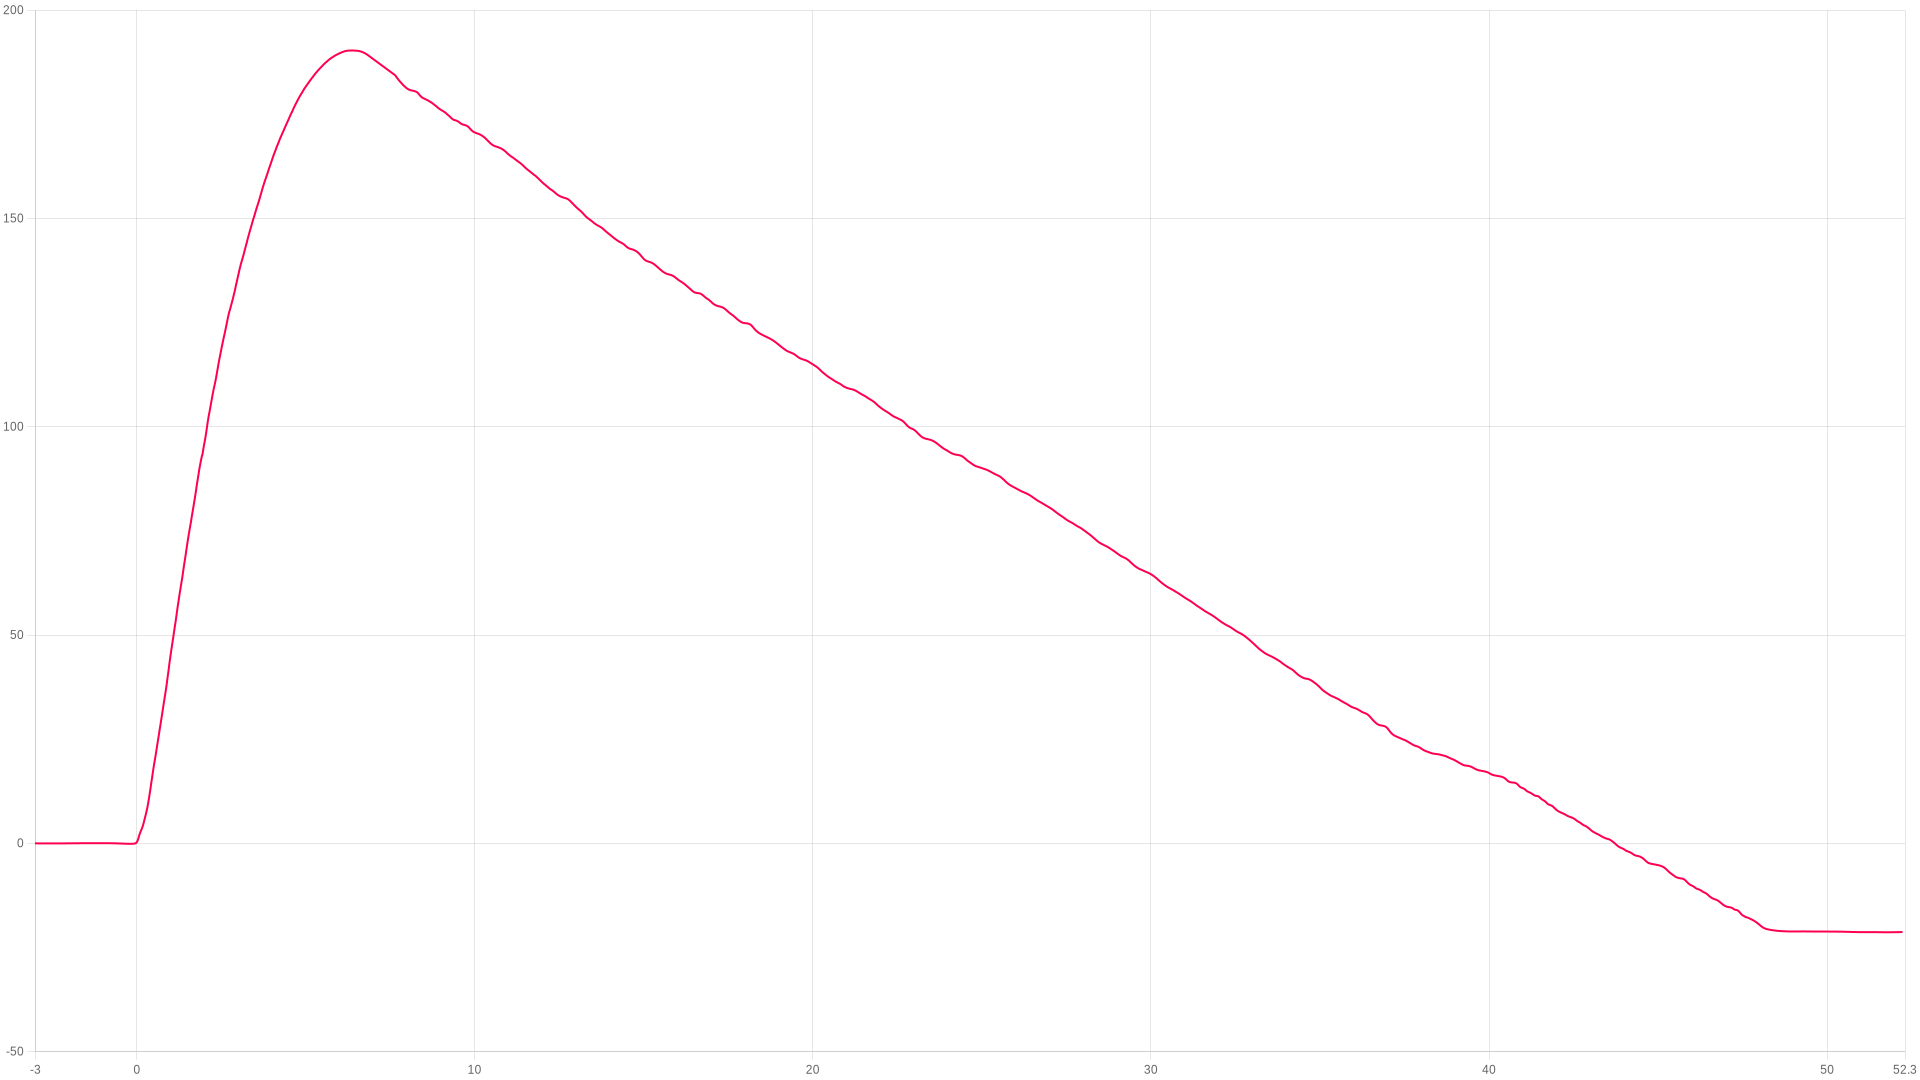
Apogeum
190.33m
6.37 s after launch
Maks. wznoszenie
57.67m/s
peak ascent
Maks. podczas spalania
11.01G
during the burn
Lądowanie
48.23s
touchdown 4.77 m/s
ZOOM TO
s
s
Pokaž zdarzenia
Dostosuj temp. & ciśnienie ?
Obraz
Powiększenie
Kliknij i przeciągnij lub užyj gestu
Porównaj lot ?
Podsumowanie lotu

The flight, moment by moment

Liftoff
0 s
Nachylenie rampy11.27°
Thrust calc pad tilt2.9°
Launch detected
0.835 s
Wysokość35.03 m
Prędkość54.98 m/s
Wypalenie (pierwszy)
1.93 s
Wysokość92.9 m
Prędkość48.050 m/s
Apogeum
6.37 s
Wysokość190.33 Metry
Maks. nachylenie do wypalenia35.63°
Možliwy wyrzut
7.066 s
Wysokość187.88 m
Prędkość-5.99 m/s
Lądowanie
48.23 s
Wysokość-20.62 m
Maks. opadanie-19.6 m/s

Stabilność68.8%Umiarkowany

Nachylenie przy wypaleniu (20%)92.5
20% · Launch tilt 2.9°
Prędkość pochylania/odchylania (30%)52.1
25% · Coning 95.8/107.4°/s
Coning · boost (25%)46.3
25% · Spin 71.9°/s
Prostoliniowość ciągu (15%)85.8
30% · Thrust 97%

Rocket information

Calculated from the flight data alone
Boost acceleration24.9 m/s²
average over the burn · 2.5 g
Coast deceleration10.8 m/s²
average · gravity plus drag
Ballistic coefficient231 kg/m²
fitted to the 4.44 s coast
Apogee lost to tilt0.24 m
flown vertical ≈ 190.5 m · from the thrust-calculated tilt
Chute opening peak22.19 G
largest deceleration after ejection
Average descent rate5.06 m/s
ejection to landing · 41.16 s
Bateria & temperatura 0% → 0% · Temperatura początek 24.95 → 25.09 °C · Start po włączeniu 3m 56s

About the stability score

Worked out from the flight log between liftoff and 80% of apogee. It is independent of the angle the altimeter was mounted at, so it measures the flight rather than the fitting.

Nachylenie przy wypaleniu (20%)20%How close to vertical it left the rod.
Prędkość pochylania/odchylania (30%)25%How much the nose swung off the rocket's own axis across the whole ascent.
Coning · boost (25%)25%The same swing during the burn, when it matters most.
Prostoliniowość ciągu (15%)30%How cleanly the motor pushed along the body.

Spin about the rocket's own axis is not counted against it — a fast, straight spin is stable. The figures beside the score are the raw measurements behind these four.

Wysokość
Apogeum190.33 Metry
Czas do apogeum6.37 s
Wysokość wypalenia92.9 m
Wys. maks. prędkości48.42 m
Wys. wyrzutu187.88 m
Wys. lądowania-20.62 m
Wysokość nagrywania232.46 m
Prędkość
Maks. wznoszenie57.67 m/s
Maks. opadanie-19.6 m/s
Przy wypaleniu48.050 m/s
Prędk. opadania-4.898 m/s
Prędk. wyrzutu-5.99 m/s
Prędk. lądowania-4.772 m/s
Przyspieszenie
Maks. podczas spalania11.01 G
Maks. wznoszenie11.01 G
Maks. opadanie22.19 G
Śr. wznoszenie0.36 G
Śr. spalanie3.07 G
Czasy
Wypalenie (pierwszy)1.93 s
Apogeum6.37 s
Možliwy wyrzut7.066 s
Lądowanie48.23 s
Wyjście #1 WŁ0 s
Wyjście #1 WYŁ0 s
Kąty
Nachylenie rampy11.27°
Thrust calc pad tilt2.9°
Maks. nachylenie do wypalenia35.63°
Przechylenie startowe4.85°
Pochylenie startowe-10.18°
Maks. obrót (spal.)614.98 dps
Śr. obrót (spal.)97.76 dps
Recovery
Single deploy
No dual deploy detected on this flight.
Ogólne
Data przesłania21-Jul at 13:14
Próbki danych8355
Całkowity czas nagrania64.400 s
Śr. próbki/s129.7
Liczba blokad1
Start po włączeniu3m 56s
Oś referencyjnaX
Bateria & temperatura
Bateria początek0%
Bateria koniec0%
Temperatura początek24.95°C
Temperatura koniec25.09°C
Temp. MT1 startowa0°C
Reguły wyjścia
Brak skonfigurowanych reguł
Notatki užytkownika
Brak notatek
Dodaj to urządzenie do swojego konta, aby edytować
Film Youtube
Brak filmu
Dodaj to urządzenie do swojego konta, aby edytować
Zdjęcia lotu 0
Brak zdjęć
Silniki lotu
1st stage · 7s delay
E26W-7AeroTechDetails
Burn time
1.18 s
Diameter
24.00 mm
Average thrust
23.5 N
Max thrust
27.89 N
Total weight
44.00 g
Propellant weight
18.30 g
Propellant type
White Lightning
Impulse27.85Ns
Max thrust27.8N
Burn time1.18s
Impulse classE
1st stage thrustloading curve…
Motor data by ThrustCurve.org
Dodaj to urządzenie do swojego konta, aby edytować
Powiązana rakieta
🚀
Active
Iris
LOC Precision — Park Flyer IRIS 1.6"
1 flight linked
Type
Kit build
Diameter
41.5mm
Length
838mm
Dry weight
300g
Loaded wt.
350g
Mod
Modified
Stages
1
Fins
4
Recovery
Parachute
Body
Kraft paper
💬 No comments yet
Rule events
No output rules fired during this flight.
Dopasowanie silnika (BETA)
Wciąż w trybie testowym! Pracujemy nad ustaleniem, jaki silnik był użyty.
Marka
Silnik
Wynik
Kształt
Spalanie
Contrail
G300
30
17.5%
66.7%
Estes
1/4A3T
19
1%
83.7%

Linked flights

Connect flights that belong together: a second altimeter flown in the same rocket, or the same rocket flown again. Linked flights appear on each other’s pages.

No linked flights yet.

Miejsce startu, data i godzina

Kliknij na mapę, aby oznaczyć miejsce startu. Przełączaj między widokiem mapy i satelity.

Imagery © Esri, Maxar, Earthstar Geographics

Kliknij na mapę · Przeciągnij, aby dostosować

Site nameUnnamed siteLat55.726646Lng-4.814018Ground level238.2 m · 782 ftData startu2026-07-11Godzina startu16:00
Animacja danych lotu

FLIGHT 2621

190.33 Meters

ALTITUDE
0.00m
VELOCITY
0.00m/s
ACCEL
0.00G
TILT
0.00°
PITCH
0.00°
ROLL
0.00°
YAW
0.00°
TIME
0.00s
AWAITING LAUNCH
ALT
altimetercloud.com
LAUNCH T+0.00s LANDING

BURNOUT

Motor burn complete

Uwaga: Animacja lotu wymaga montażu wysokościomierza w stałej orientacji. Skalibruj czujniki dla najlepszych wyników.
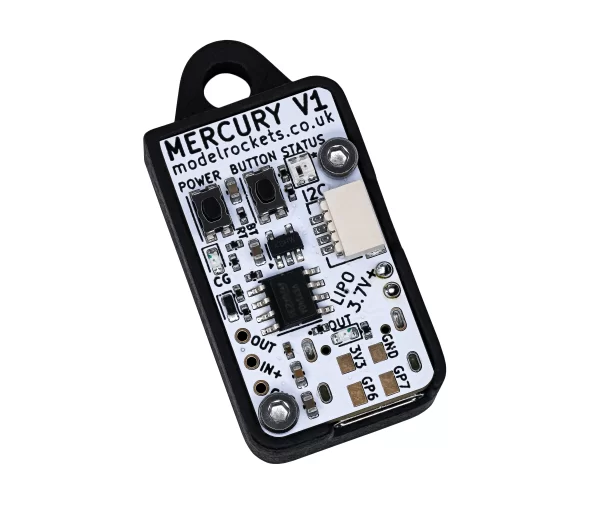
Mercury V1
Revision 1
Mercury V1
Ten lot został wykonany na Mercury V1.
The hardware
Wersja sprzętuRev 1
Wersja oprogramowania2.40
Ostatnio online21-Jul at 13:42
Czujnik ciśnieniaBosch BMP 390
Akcelerometr32G 3-axis
Gyroskop2000 dgps 3-axis
MagnetometrN/A

Settings, as they were for this flight

Ogólne ustawienia lotu
Ciśnienie prognozowane
i
Set this to your local forecast pressure at sea level. This will offer you slightly improved accuracty for your flight, although it's not 100% essential every little helps!

Xcweather.co.uk is a decent place to grab pressures from for your location and time.
1026 mbar
Detekcja startu
i
This is the altitude above the launch pad altitude where the altimeter will trigger itself into recording / flight mode.

The altimeter keeps a constant average of the pressure while waiting for launch, it uses a simple algorithm and the pre-flight buffers to do this. The most recent 120 samples (~4 seconds) are ignored so your pre-trigger altitude won't effect the ground baseline.

For almost all uses we suggest keeping this on the 25 Meter (~82 feet) default settings. If you want to test your altimeter by throwing it in the air, or are planning a very low flight you may want to lower the setting.
35 meters
Sample ratio
i
The altimeter runs at 50Hz however you can record every sample or every X samples in order to extend the log time. For example if you set the ratio to 1 it will save 1:1 samples, or if you set it to 3 it will save 1 in 3 samples.
1:5 (hybrid, reduces after apogee)
Max samples
i
This is the maximum samples the altimeter will log per flight. When it reaches this amount it will stop and save the recording.
18000
Recording stop
i
This setting is how the altimeter decides to stop recording. You can choose either 450 (~9s) or 900 (~18s) samples stable or it will record until the max samples limit unless you press the BUTTON in Manual stop mode.

The samples stable method waits for the devices altitude not to change for the set number of samples. This is defined by not changing by more than +/- 1.0 meters for 98% of the samples, it's a reliable method to stop the recording after landing within 8-10 seconds (300 sample) or 16-20 seconds (600 sample).
Auto: 450 samples stable (~9s)
Oversampling
i
Oversampling is a internal setting of the BMP 390 pressure sensor. It is how many samples are taken for each reading. By taking multiple samples for each pressure reading the altimeter reduces noise and increases the resolution of the output.

The sensor can run at 50 samples per second in 4X mode, so we suggest leaving it in this mode as it will offer the highest accuracy.
8x Oversampling
IIR filter
i
The IIR filter is another internal sensor for the BMP390 pressure sensor. It is a Infinite impulse response filter used to enhance pressure measurement accuracy by reducing noise. It's primarily for smoothing out rapid pressure changes.

We suggest not setting this too high as it will cause delay to changes in altitude if set very high.
COEFF 7
Pressure filter
i
This filter is a software Kalman filter that runs on the altimeters processor.

The Kalman filter uses a prediction step based on a system model and then a correction step using new measurements to refine its estimate, it creates accurate most certain results from data with noise in it.
Kalman 2 (default)
Lockout change
i
This is how we detect a lockout. If the pressure changes by this much in a single sample downwards (pressure increase, lower altitude) then it's likely to be a false reading. Multiply the setting by 32 to get the speed in meters per second that it will trigger at.
0.5 meters
Sync sensors
i
The filters on the pressure sensor can cause it to lag very slightly behind the Accelerometer and Gyroscope data. The Sync sensors option detects how far out of sync these sensors are. It then corrects the Acceleration and Gyroscope readings to match the pressure sensor.
WŁĄCZONY (75 samples / 300.00ms)
Orientation
i
This is the orientation you intend to install the Altimeter in your rocket. It's needed to ensure completly accurate angles and orientation charts and reports. Check out the Manual for more information on this.
Upwards (text up)
IMU filter
i
The IMU filter, or fusion filter takes the data from each axis of the Gyroscope and Accelerometer to calculate the Pitch, Roll, Yaw and tilt angle from vertical. These filters can build up some discrepency over time so it's important to calibrate your sensors to minimise this.
Madgwick 6-Axis
Launch ALP
i
This is prevention against accidental launch detection.

With this disabled the launch is based only on pressure and something that creates a low pressure can trigger the flight by accident. For example pulling your nose cone off can even trigger it.

With this enabled the rocket also needs to have seen 8 samples (0.25 seconds) of acceleration above this setting in the last 3 seconds as well as the pressure drop to trigger. There is a backup trigger of 1.05 seconds of altitude being above the launch detect setting too.

There are very few situations where this option would cause issues, so we suggest leaving it on.
1.4G
Launch lock
i
When enabled, the altimeter locks out recording for a set period after power on to prevent false triggering during setup.
DISABLED
Static temperature
i
A fixed temperature value used for altitude calculation when the external temperature sensor is disabled or not connected.
15 °C
Temp sensor
i
If an external MT1 temperature sensor is connected, this controls whether it is used for logging only or also for altitude calculations.
DISABLED
Ustawienia wyjścia
Arm switch
i
When enabled, GP6 is a hardware arm switch — outputs and rules are held off until the switch is closed to ground.
DISABLED
Startup lockout
i
Outputs and rules are blocked for this many seconds after power-on while sensors settle. 0 = off.
None
Launch confirm delay
i
After launch is detected, outputs and rules won't fire until this many seconds have passed.
2 s
Altitude floor
i
Outputs and rules are blocked until the rocket is at least this height above the launch pad.
50 m
Custom dataset 1
i
User-defined expression evaluated per sample, available for charting.
Custom dataset 2
Kalibracja czujników
Przesunięcia kalibracji użyte w tym locie.
Gyroskop⚠ Gyroskop nie został skalibrowany
X0.000°
Y0.000°
Z0.000°
Akcelerometr⚠ Akcelerometr nie został skalibrowany
X0.000 mG
Y0.000 mG
Z0.000 mG
Ustawienia urządzenia
TAG urządzenia
i
A custom name or tag assigned to this device for easy identification.
Merc9448
Język
i
The language setting configured on the device.
🇬🇧 English
Tryb wyłączania
i
Controls what happens after recording. Standard shuts down normally, Delayed keeps WiFi on for 30 seconds after landing, Stay on keeps the device powered on.
Standard
Jasność LED
i
The brightness level of the LED indicators on the Mercury. Lower values save battery.
20%
WiFi TX power
i
WiFi transmit power level. Higher gives better range but uses more battery.
2 dBm (low)
Tryb uśpienia
i
Controls whether the device enters low-power sleep when idle.
Normal (sleep when idle)
Monitor baterii
i
Monitors battery voltage during the flight.
DISABLED
Cloud group
i
The cloud group / category this flight is assigned to.
General use
Porty GP6 / GP7
Konfiguracja portów GP6 i GP7 dla kanałów pirotechnicznych, serw lub innych urządzeń.
Channel 6 mode
ON = HIGH
Ch6 min pulse (µs)
0
Ch6 max pulse (µs)
0
Ch6 frequency
0 Hz
Ch6 angle ON
Ch6 angle OFF
Ch6 on time
0s
Channel 7 mode
ON = HIGH
Ch7 min pulse (µs)
0
Ch7 max pulse (µs)
0
Ch7 frequency
0 Hz
Ch7 angle ON
Ch7 angle OFF
Ch7 on time
0s
Płytka servo I2C PCA9685
Configuration for the external I2C PCA9685 servo expansion board. This board provides up to 6 additional servo channels.
No I2C servo board was connected for this flight.
Prognoza i hamulce powietrzne
The Mercury can predict apogee while coasting after burnout. These settings control the prediction calculation and optional air brake system.
Dry mass
i
The total mass of the rocket after motor burnout (dry mass). This is used for the ballistic prediction of apogee altitude. Enter the mass without the motor propellant, or the mass at burnout.
0.15 kg
Drag Cd
i
The aerodynamic drag coefficient (Cd) of the rocket. This is used with the rocket area to calculate aerodynamic drag during coast. A typical model rocket has a Cd of 0.4 to 0.8. You can find this value from OpenRocket or RockSim simulations.
0.75
Reference area
i
The cross-sectional reference area of the rocket in square meters. This is typically the area of a circle with the body tube diameter. For example a 38mm tube has an area of approximately 0.00113 m².
0.001 m²
Gas constant
i
The specific gas constant for dry air, used in the atmospheric model for altitude and density calculations. The standard value is 287.05 J/(kg·K). You shouldn't need to change this unless you know what you're doing.
287.05 J/(kg·K)
The following settings configure the air brake system.
Air brake enabled
i
Enables or disables the active air braking system. When enabled, the Mercury will deploy air brakes via the configured servo channel to try and reach the target altitude. Firmware 2.1+ required.
OFF (default)
Servo channel
i
Which servo output channel the air brake mechanism is connected to. GP6 and GP7 are the two onboard servo headers, I2C channels are for an external servo expander board.
GP6
Deploy speed
i
The speed at which the air brakes deploy. The Mercury gradually increases the servo angle until the predicted apogee matches the target rather than going full on/off. This setting controls how quickly it ramps up to full braking.
Medium (default)
Target altitude
i
The target apogee altitude in meters. The air brake system will try to slow the rocket so it reaches this altitude.
300 m
Over shoot %
i
The percentage over the target altitude to aim for until within 15% of the target. This helps prevent undershooting if the prediction is slightly off early in the coast. For example, with a 1000m target and 5% early adjustment, the Mercury will aim for 1050m until it passes 850m.
5%
Activation altitude
i
The air brake system activates after burnout, but won't engage until the rocket has reached this percentage of the target altitude. This prevents the brakes from deploying too early when predictions may be less accurate.
20% (default)

Files

Where the altimeter signs its log, the file carries that signature and a tick beside it. A tick means the data is unchanged since the device wrote it, which is what a record claim needs.
CSV
2621.csv
The log as columns of text. Opens in a spreadsheet, and in every simulator that reads flight data.
693 KB
WX
2621_weather.json.gz
The weather for 48 hours either side of the launch, within 15 km of the launch site: NOAA GFS every hour, at the surface and up to about 31 km, and the NOAA GEFS ensemble where this site holds it. JSON, gzip compressed. Weather data by Open-Meteo.com (CC BY 4.0) and NOAA. For 2026-07-11 16:00 local time at 55.7266, -4.8140.
192 KB
Pobierz
Adjusted CSV2904 recalculated in your browser
The log recomputed for your own sea-level pressure and temperature. Columns: time, altitude as recorded and adjusted, raw altitude as recorded and adjusted, pressure.

This file is built here from the signed log, so it carries no signature of its own. Anyone verifying a claim should be sent to the flight page and build their own from the original.

Lot
Komentarze
Zaloguj się aby komentować.