Entfernung
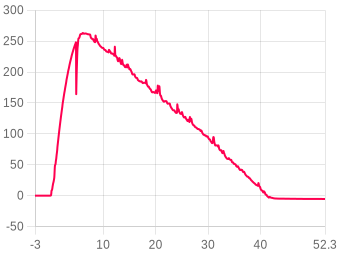
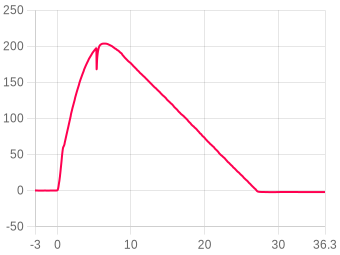
Wählen Sie die Entfernungseinheit: Meter(m), Fuß(ft), Meilen(mi) oder Kilometer(km)
Geschwindigkeit
Wählen Sie die Geschwindigkeitseinheit: m/s, ft/s, mph oder km/h
Beschleunigung
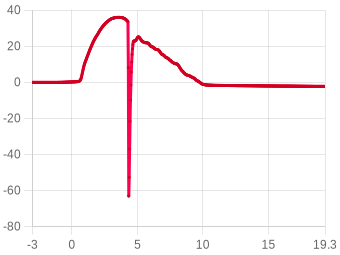
Wählen Sie die Beschleunigungseinheit: m/s² oder G
Flug 533

Flight 533

Mercury V1 Rev 1 · firmware 1.24B
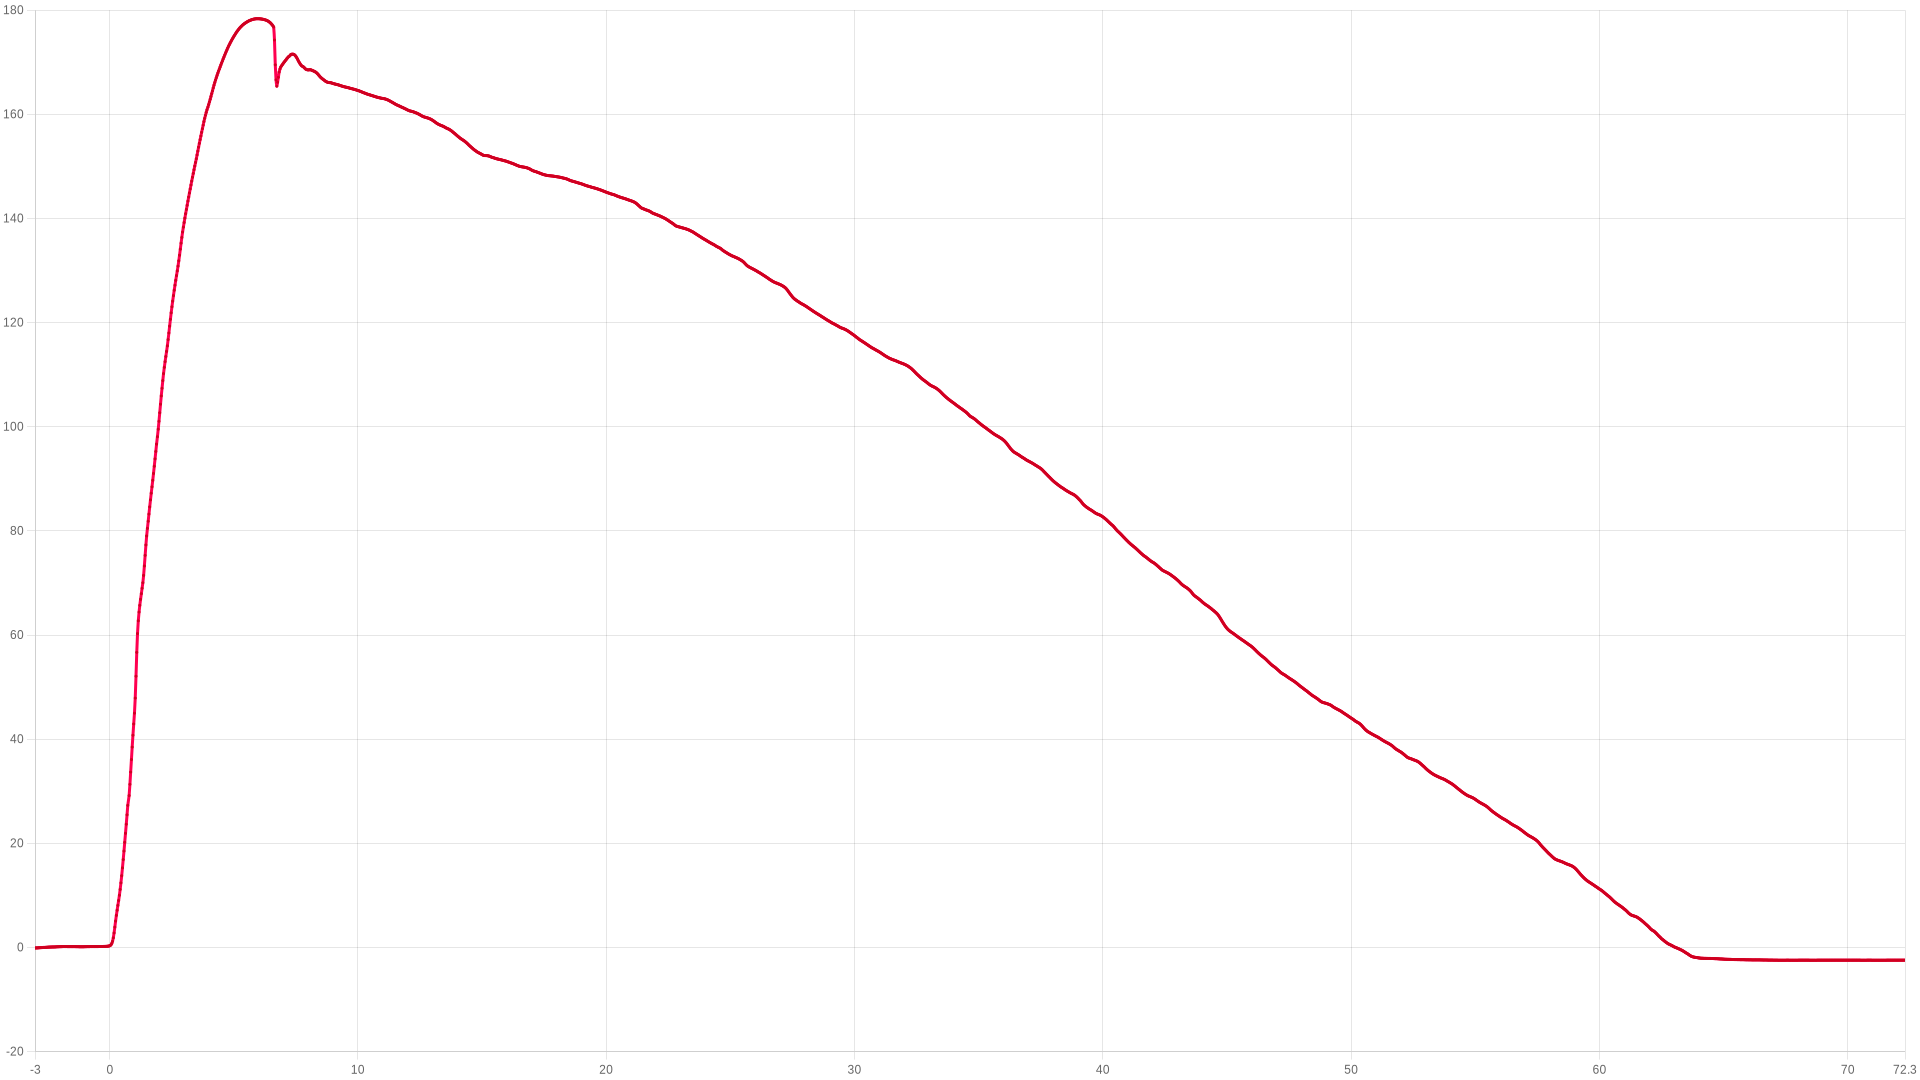
Apogäum
178.36m
5.99 s after launch
Max. Aufstieg
85.17m/s
peak ascent
Max. während Brennen
11.46G
during the burn
Landung
63.17s
touchdown 3.81 m/s
ZOOM TO
s
s
Ereignisse anzeigen
Herunterladen
Temp. & Druck anpassen ?
Bild
Zoom
Klicken und ziehen, oder auf Mobilgerät kneifen
Flug vergleichen ?
Flugzusammenfassung

The flight, moment by moment

Liftoff
0 s
Rampen-Neigung34.21°
Thrust calc pad tilt8.4°
Launch detected
0.706 s
Höhe25.47 m
Geschwindigkeit54.44 m/s
Brennschluss (erster)
3.86 s
Höhe159.82 m
Geschwindigkeit19.960 m/s
Apogäum
5.99 s
Höhe178.36 Meter
Max. Neigung bis Brennschluss127.22°
Möglicher Auswurf
6.799 s
Höhe167.11 m
Geschwindigkeit-0.92 m/s
Landung
63.16 s
Höhe-0.21 m
Max. Abstieg-6.9 m/s

Stabilität44.4%Ausreichend

⚠ Low confidence — altimeter may have moved in flight
Neigung bei Brennschluss (20%)78.8
20% · Launch tilt 8.4°
Nick/Gier-Rate (30%)15.7
25% · Coning 231.3/215.7°/s
Coning · boost (25%)17.6
25% · Spin 193.9°/s
Schubgeradheit (15%)67.6
30% · Thrust 93%

Rocket information

Calculated from the flight data alone
Boost acceleration5.2 m/s²
average over the burn · 0.5 g
Coast deceleration9.4 m/s²
average · gravity plus drag
Ballistic coefficient87 kg/m²
fitted to the 2.13 s coast
Apogee lost to tilt1.91 m
flown vertical ≈ 180.2 m · from the thrust-calculated tilt
Chute opening peak26.06 G
largest deceleration after ejection
Average descent rate2.96 m/s
ejection to landing · 56.36 s
Batterie & Temperatur 0% → 0% · Temperatur Start 21.07 → 19 °C · Start nach Einschalten 18m 54s

About the stability score

Worked out from the flight log between liftoff and 80% of apogee. It is independent of the angle the altimeter was mounted at, so it measures the flight rather than the fitting.

Neigung bei Brennschluss (20%)20%How close to vertical it left the rod.
Nick/Gier-Rate (30%)25%How much the nose swung off the rocket's own axis across the whole ascent.
Coning · boost (25%)25%The same swing during the burn, when it matters most.
Schubgeradheit (15%)30%How cleanly the motor pushed along the body.

Spin about the rocket's own axis is not counted against it — a fast, straight spin is stable. The figures beside the score are the raw measurements behind these four.

Höhe
Apogäum178.36 Meter
Zeit bis Apogäum5.99 s
Brennschluss-Höhe159.82 m
Max. Geschw.-Höhe52.09 m
Auswurf-Höhe167.11 m
Lande-Höhe-0.21 m
Aufnahme-Höhe152.34 m
Geschwindigkeit
Max. Aufstieg85.17 m/s
Max. Abstieg-6.9 m/s
Bei Brennschluss19.960 m/s
Abstiegsgeschw.-3.021 m/s
Auswurfgeschw.-0.92 m/s
Landegeschw.-3.814 m/s
Beschleunigung
Max. während Brennen11.46 G
Max. Aufstieg11.46 G
Max. Abstieg26.06 G
Durchschn. Aufstieg0.64 G
Durchschn. Brennen1.43 G
Zeiten
Brennschluss (erster)3.86 s
Apogäum5.99 s
Möglicher Auswurf6.799 s
Landung63.16 s
Ausgang #1 EIN0 s
Ausgang #1 AUS0 s
Winkel
Rampen-Neigung34.21°
Thrust calc pad tilt8.4°
Max. Neigung bis Brennschluss127.22°
Start-Roll-18.51°
Start-Nick-29.30°
Max. Drehung (Brennen)1421.7 dps
Durchschn. Drehung (Brennen)244.69 dps
Recovery
Single deploy
No dual deploy detected on this flight.
Allgemein
Upload-Datum14-Sep at 16:10
Datenpunkte2533
Gesamte Aufnahmezeit78.200 s
Durchschn. Abtastrate/s32.3
Anzahl Sperren1
Start nach Einschalten18m 54s
ReferenzachseX
Batterie & Temperatur
Batterie Start0%
Batterie Ende0%
Temperatur Start21.07°C
Temperatur Ende19°C
MT1 Starttemp.0°C
Ausgangsregeln
Keine Regeln konfiguriert
Benutzernotizen
Keine Notizen
Fügen Sie dieses Gerät Ihrem Konto hinzu, um zu bearbeiten
Youtube-Video
Kein Video
Fügen Sie dieses Gerät Ihrem Konto hinzu, um zu bearbeiten
Flugbilder 0
Keine Bilder
Flugmotoren
Keine Motoren zu diesem Flug hinzugefügt
Fügen Sie dieses Gerät Ihrem Konto hinzu, um zu bearbeiten
Verknüpfte Rakete
Keine Rakete mit diesem Flug verknüpft
Flight mass
No masses have been set for this flight.
Ausgangsregeln
Ausgangsregeln were not available until firmware 2.0
Motor-Zuordnung (BETA)
Noch im Testmodus! Wir arbeiten daran, den passenden Motor für einen Flug zu ermitteln.
Marke
Motor
Punkte
Form
Brennen
Contrail
G300
73
94.9%
81.8%
Estes
1/4A3T
12
25.4%
48.2%
Estes
1/2A6
0
3.8%
45.6%
Cesaroni
25-E75-VM-17A
0
58.3%
68.7%
Cesaroni
68-F240-VM-15A
0
70.5%
65.5%
AeroTech
H669N
0
70.1%
62.1%

Linked flights

Connect flights that belong together: a second altimeter flown in the same rocket, or the same rocket flown again. Linked flights appear on each other’s pages.

No linked flights yet.

Startplatz, Datum & Uhrzeit

Klicken Sie auf die Karte, um Ihren Startplatz zu markieren. Wechseln Sie zwischen Karten- und Satellitenansicht.

Imagery © Esri, Maxar, Earthstar Geographics

Klicken Sie auf die Karte · Ziehen zum Anpassen

Canopy height from the Meta and WRI High Resolution Canopy Height Maps v2 (Meta and World Resources Institute, 2026; source imagery © 2016 Vantor), used under CC BY 4.0. Ground elevation built from Terrain Tiles (Mapzen and AWS Open Data), derived from 3DEP and GMTED courtesy of the U.S. Geological Survey, SRTM courtesy of NASA, and ETOPO1 courtesy of NOAA. Map and imagery credited on the view above.

No launch site has been set for this flight.

Flugdaten-Animation

FLIGHT 533

178.36 Meters

ALTITUDE
0.00m
VELOCITY
0.00m/s
ACCEL
0.00G
TILT
0.00°
PITCH
0.00°
ROLL
0.00°
YAW
0.00°
TIME
0.00s
AWAITING LAUNCH
ALT
altimetercloud.com
LAUNCH T+0.00s LANDING

BURNOUT

Motor burn complete

Hinweis: Die Fluganimation erfordert eine feste Ausrichtung Ihres Höhenmessers. Kalibrieren Sie Ihre Sensoren für beste Ergebnisse.
Mercury V1
Revision 1
Mercury V1
Dieser Flug wurde mit einem geflogen: Mercury V1.
The hardware
HardwareversionRev 1
Softwareversion1.24B
Zuletzt online13-Apr at 19:37
DrucksensorBosch BMP 390
Beschleunigungssensor32G 3-axis
Gyroskop2000 dgps 3-axis
MagnetometerN/A

Settings, as they were for this flight

Allgemeine Flugeinstellungen
Prognosedruck
i
Set this to your local forecast pressure at sea level. This will offer you slightly improved accuracty for your flight, although it's not 100% essential every little helps!

Xcweather.co.uk is a decent place to grab pressures from for your location and time.
1013 mbar
Starterkennung
i
This is the altitude above the launch pad altitude where the altimeter will trigger itself into recording / flight mode.

The altimeter keeps a constant average of the pressure while waiting for launch, it uses a simple algorithm and the pre-flight buffers to do this. The most recent 120 samples (~4 seconds) are ignored so your pre-trigger altitude won't effect the ground baseline.

For almost all uses we suggest keeping this on the 25 Meter (~82 feet) default settings. If you want to test your altimeter by throwing it in the air, or are planning a very low flight you may want to lower the setting.
25 meters
Abtastrate
i
The base sample rate of the altimeter's sensors in samples per second. This setting was deprecated in firmware 2.0+.
32 Hz
Abtastverhältnis
i
The altimeter runs at 50Hz however you can record every sample or every X samples in order to extend the log time. For example if you set the ratio to 1 it will save 1:1 samples, or if you set it to 3 it will save 1 in 3 samples.
1:
Max. Abtastungen
i
This is the maximum samples the altimeter will log per flight. When it reaches this amount it will stop and save the recording.
0
Aufnahme-Stopp
i
This setting is how the altimeter decides to stop recording. You can choose either 450 (~9s) or 900 (~18s) samples stable or it will record until the max samples limit unless you press the BUTTON in Manual stop mode.

The samples stable method waits for the devices altitude not to change for the set number of samples. This is defined by not changing by more than +/- 1.0 meters for 98% of the samples, it's a reliable method to stop the recording after landing within 8-10 seconds (300 sample) or 16-20 seconds (600 sample).
Auto: 450 samples stable (~9s)
Oversampling
i
Oversampling is a internal setting of the BMP 390 pressure sensor. It is how many samples are taken for each reading. By taking multiple samples for each pressure reading the altimeter reduces noise and increases the resolution of the output.

The sensor can run at 50 samples per second in 4X mode, so we suggest leaving it in this mode as it will offer the highest accuracy.
4x Oversampling
IIR-Filter
i
The IIR filter is another internal sensor for the BMP390 pressure sensor. It is a Infinite impulse response filter used to enhance pressure measurement accuracy by reducing noise. It's primarily for smoothing out rapid pressure changes.

We suggest not setting this too high as it will cause delay to changes in altitude if set very high.
COEFF 3
Druckfilter
i
This filter is a software Kalman filter that runs on the altimeters processor.

The Kalman filter uses a prediction step based on a system model and then a correction step using new measurements to refine its estimate, it creates accurate most certain results from data with noise in it.
Kalman 2 (default)
Sperrzeit
i
The Lockout time is how long the altimeter should stop making decisions and taking actions if it detects unusual high speed altitude changes that are unexpected.
These false readings can be caused by ejection charges (if the altimeter is in the same compartment as the motor ejection gases) or even when you transition to Mach speeds and can give false readings of altitude changes.

When these events are detected the system enters Lockout for the specified time while it stabalises. This effects things like triggering the output, or calculating other data.
750ms
Sperränderung
i
This is how we detect a lockout. If the pressure changes by this much in a single sample downwards (pressure increase, lower altitude) then it's likely to be a false reading. Multiply the setting by 32 to get the speed in meters per second that it will trigger at.
1.5 meters
Sensorsynchronisation
i
The filters on the pressure sensor can cause it to lag very slightly behind the Accelerometer and Gyroscope data. The Sync sensors option detects how far out of sync these sensors are. It then corrects the Acceleration and Gyroscope readings to match the pressure sensor.
AKTIVIERT (6 samples / 189.00ms)
Ausrichtung
i
This is the orientation you intend to install the Altimeter in your rocket. It's needed to ensure completly accurate angles and orientation charts and reports. Check out the Manual for more information on this.
Upwards (text up)
IMU-Filter
i
The IMU filter, or fusion filter takes the data from each axis of the Gyroscope and Accelerometer to calculate the Pitch, Roll, Yaw and tilt angle from vertical. These filters can build up some discrepency over time so it's important to calibrate your sensors to minimise this.
Madgwick 6-Axis
Start-ALP
i
This is prevention against accidental launch detection.

With this disabled the launch is based only on pressure and something that creates a low pressure can trigger the flight by accident. For example pulling your nose cone off can even trigger it.

With this enabled the rocket also needs to have seen 8 samples (0.25 seconds) of acceleration above this setting in the last 3 seconds as well as the pressure drop to trigger. There is a backup trigger of 1.05 seconds of altitude being above the launch detect setting too.

There are very few situations where this option would cause issues, so we suggest leaving it on.
1.4G
Startsperre
i
When enabled, the altimeter locks out recording for a set period after power on to prevent false triggering during setup.
DISABLED
Statische Temperatur
i
A fixed temperature value used for altitude calculation when the external temperature sensor is disabled or not connected.
15 °C
Temp.-Sensor
i
If an external MT1 temperature sensor is connected, this controls whether it is used for logging only or also for altitude calculations.
Ausgangseinstellungen
Ausgang 1 aktiviert
i
Disable or enable the output from being able to turn on or off.
DEAKTIVIERT
Ausgang 1 Auslöser
i
After apogee (altitude)
This method triggers when the altitude drops below the set altitude after apogee is detected.
After apogee (time)
This method triggers the defined seconds after apogee is detected.
After launch (altitude)
This method is activated if/once the altimeter exceeds the set altitude after launch.
After launch (time)
This option triggers the defined seconds after launch is detected.
After burnout (time)
This method triggers the defined seconds after burnout is detected.
After apogee (altitude)
Ausgang 1 Einschaltzeit
i
This is how long the output should trigger ON state when the rules are met.
2000ms
Ausgang 1 Höhe
i
This is the altitude to trigger at if using a trigger method that works on altitude.

For example if you set this to 75m and After apogee (altitude) for the trigger then the output will turn on at 75m on descent above the launch altitude.
0 meters
Ausgang 1 Zeit
i
This is the time variable for output triggers that work on time.

For example if you set this to 3 seconds and After apogee (time) as the trigger then the output will turn on 3 seconds after apogee.
0 seconds
Höhensperre
i
Altitude lock is a safety feature that prevents the output from triggering if the altitude is below this level when the rules are met.
50.00 m
Neigungssperre
i
This is another safety feature. It can be used to disable the output if the rocket has gone too far from vertical.

For example if you set the tilt angle lock to 40 degrees then the output will not fire if the rocket is more than 40 degrees from vertical. To disable set this to 0.
0.00 °
Sensorkalibrierung
Kalibrierungsversätze für diesen Flug.
Gyroskop⚠ Gyroskop wurde nicht kalibriert
X0.000°
Y0.000°
Z0.000°
Beschleunigungssensor⚠ Beschleunigungssensor wurde nicht kalibriert
X0.000 mG
Y0.000 mG
Z0.000 mG
Geräteeinstellungen
Geräte-TAG
i
A custom name or tag assigned to this device for easy identification.
Merc5486
Sprache
i
The language setting configured on the device.
en
Abschaltmodus
i
Controls what happens after recording. Standard shuts down normally, Delayed keeps WiFi on for 30 seconds after landing, Stay on keeps the device powered on.
Standard
LED-Helligkeit
i
The brightness level of the LED indicators on the Mercury. Lower values save battery.
WLAN-Sendeleistung
i
WiFi transmit power level. Higher gives better range but uses more battery.
Schlafmodus
i
Controls whether the device enters low-power sleep when idle.
Stay awake
Batterieüberwachung
i
Monitors battery voltage during the flight.
ENABLED
Cloud-Gruppe
i
The cloud group / category this flight is assigned to.
GP6 / GP7 Anschlüsse
GP-Portsteuerung war erst ab Firmware 2.0 verfügbar
I2C PCA9685 Servoplatine
GP-Portsteuerung war erst ab Firmware 2.0 verfügbar
Vorhersage und Luftbremsen
Diese Funktion war erst ab Version 2.10+ verfügbar

Files

Where the altimeter signs its log, the file carries that signature and a tick beside it. A tick means the data is unchanged since the device wrote it, which is what a record claim needs.
CSV
533.csv
The log as columns of text. Opens in a spreadsheet, and in every simulator that reads flight data.
216 KB
Adjusted CSV2904 recalculated in your browser
The log recomputed for your own sea-level pressure and temperature. Columns: time, altitude as recorded and adjusted, raw altitude as recorded and adjusted, pressure.

This file is built here from the signed log, so it carries no signature of its own. Anyone verifying a claim should be sent to the flight page and build their own from the original.

Custom CSVbuilt in your browser
Pick any of the chart’s data sets, the worked-out ones included, and the part of the flight to cover. Values come in the units the chart is set to.
Data sets
Time span

One row for every time any chosen data set has a sample. A data set with no sample at that time is left blank rather than filled in. Built from the chart’s data, so it carries no signature.

Flug
Kommentare
Anmelden um zu kommentieren.