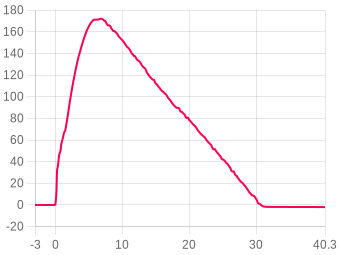
Distancia
Elija la unidad de distancia: Metros(m), Pies(ft), Millas(mi) o Kilómetros(km)
Velocidad
Elija la unidad de velocidad: m/s, ft/s, mph o km/h
Aceleración
Elija la unidad de aceleración: m/s² o G

Flight 3068

Mercury V1 Rev 1 · firmware 2.3
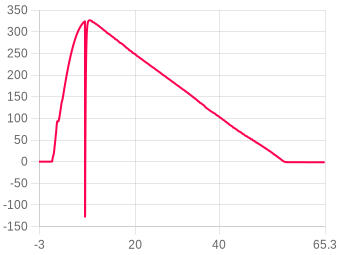
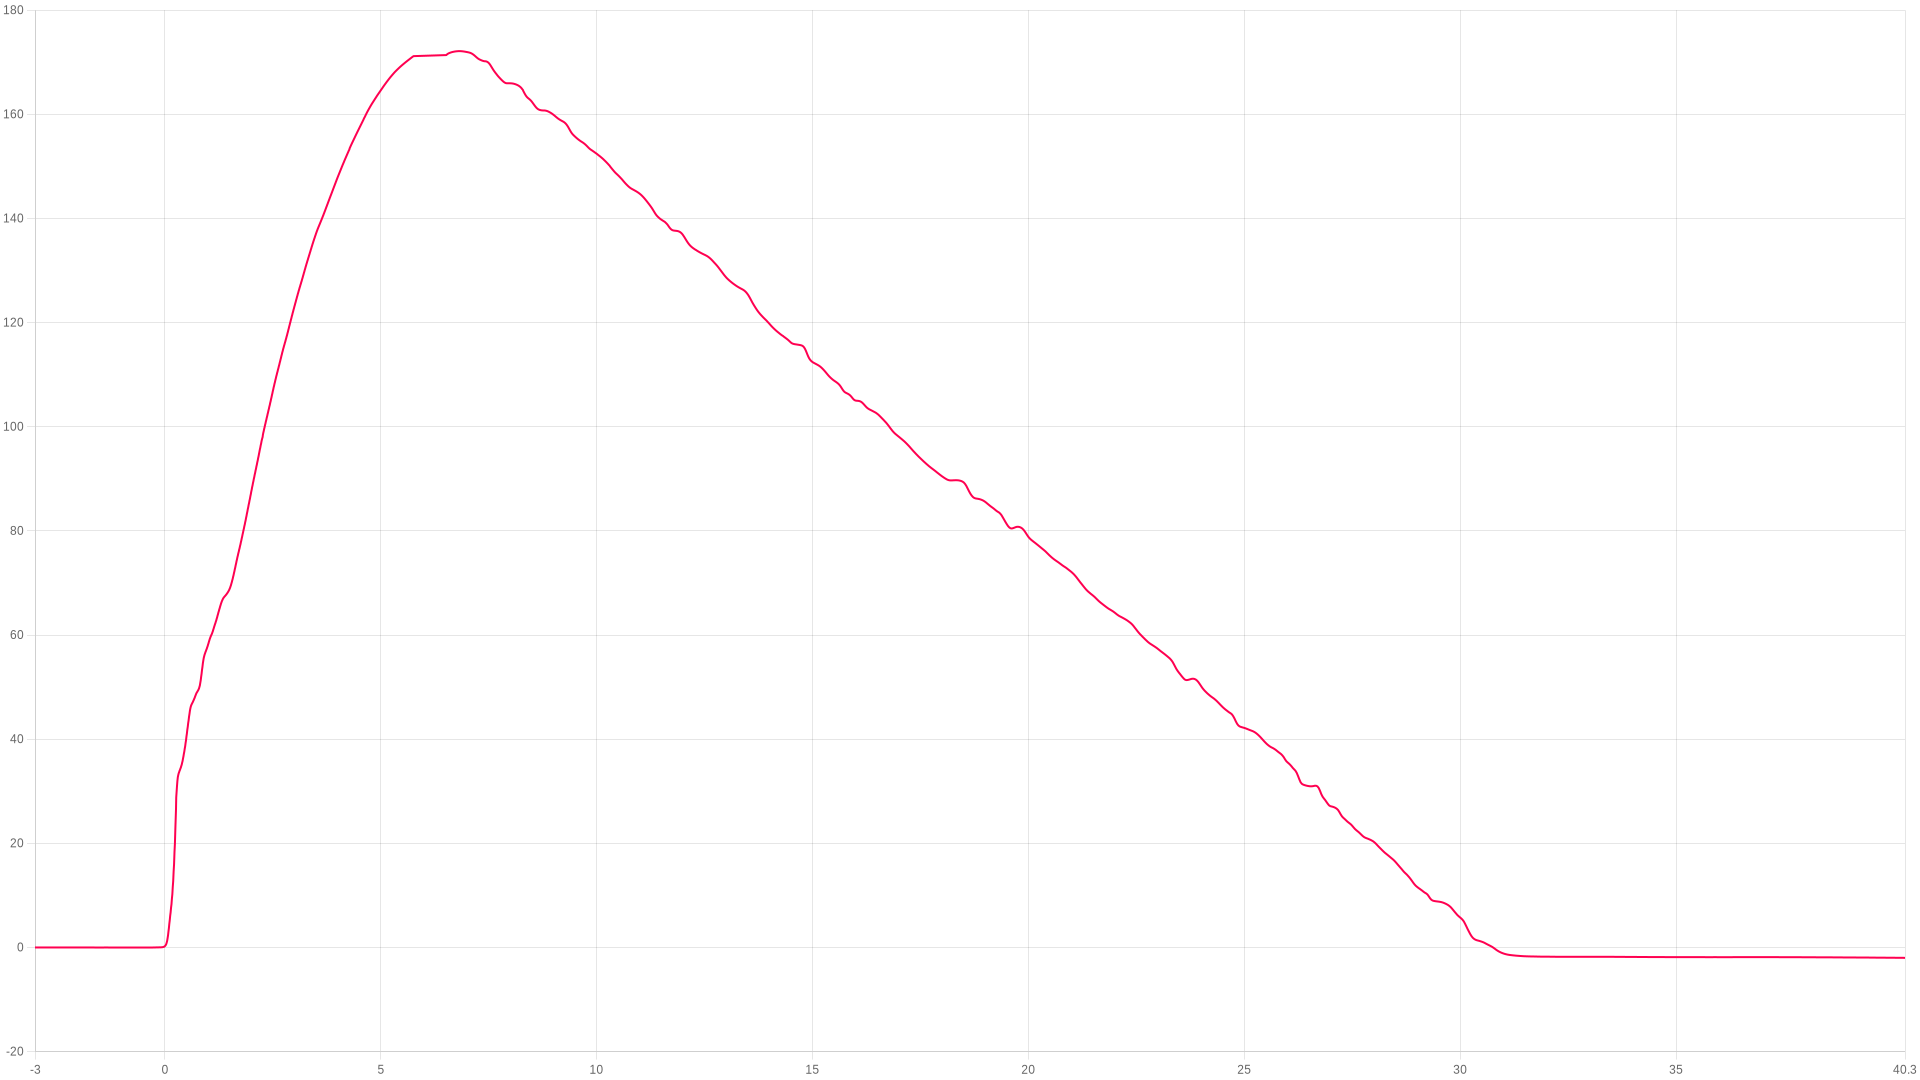
Apogeo
171.3m
5.79 s after launch
Máx. ascenso
132.7m/s
peak ascent
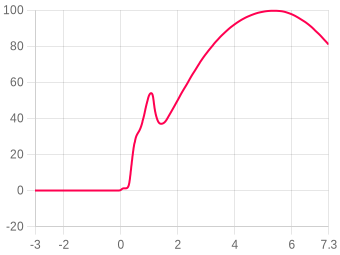
Máx. durante combustión
22.95G
during the burn
Aterrizaje
30.95s
touchdown 7.51 m/s
ZOOM TO
s
s
Mostrar eventos
Descargar
Ajustar temp. & presión ?
Imagen
Zoom
Clic y arrastre, o pellizco en móvil
Comparar vuelo ?
Resumen del vuelo

The flight, moment by moment

Liftoff
0 s
Ángulo de rampa18.2°
Orientación76.02°
Fin combustión (primero)
1.14 s
Altitud61.54 m
Velocidad25.240 m/s
Apogeo
5.78 s
Altitud171.3 Metros
Incl. máx. hasta fin comb.60.54°
Posible eyección
5.795 s
Altitud171.18 m
Velocidad2.97 m/s
Aterrizaje
30.95 s
Altitud-0.99 m
Máx. descenso-13.77 m/s

Estabilidad21.1%Pobre

⚠ Low confidence — altimeter may have moved in flight
Inclinación al apagado (20%)54.3
20% · Rail angle 18.2°
Cabeceo/guiñada (30%)27.8
25% · Coning 160.9/256.3°/s
Coning · boost (25%)13.2
25% · Spin 152.1°/s
Rectitud de empuje (15%)0
30% · Thrust 77.2%

Rocket information

Calculated from the flight data alone
Boost acceleration22.1 m/s²
average over the burn · 2.3 g
Coast deceleration5.4 m/s²
average · gravity plus drag
Apogee lost to tilt8.56 m
flown vertical ≈ 179.8 m · from the rail angle
Chute opening peak18.85 G
largest deceleration after ejection
Average descent rate6.84 m/s
ejection to landing · 25.16 s
Batería & temperatura 0% → 0% · Temperatura inicio 22.05 → 18.64 °C · Lanzamiento tras encendido 6m 36s

About the stability score

Worked out from the flight log between liftoff and 80% of apogee. It is independent of the angle the altimeter was mounted at, so it measures the flight rather than the fitting.

Inclinación al apagado (20%)20%How close to vertical it left the rod.
Cabeceo/guiñada (30%)25%How much the nose swung off the rocket's own axis across the whole ascent.
Coning · boost (25%)25%The same swing during the burn, when it matters most.
Rectitud de empuje (15%)30%How cleanly the motor pushed along the body.

Spin about the rocket's own axis is not counted against it — a fast, straight spin is stable. The figures beside the score are the raw measurements behind these four.

Altitud
Apogeo171.3 Metros
Tiempo al apogeo5.78 s
Altitud fin combustión61.54 m
Altitud vel. máx.11.63 m
Altitud eyección171.18 m
Altitud aterrizaje-0.99 m
Altitud grabación-148.37 m
Velocidad
Máx. ascenso132.69 m/s
Máx. descenso-13.77 m/s
En fin combustión25.240 m/s
Vel. descenso-6.653 m/s
Vel. eyección2.97 m/s
Vel. aterrizaje-7.508 m/s
Aceleración
Máx. durante combustión22.95 G
Máx. ascenso22.95 G
Máx. descenso18.85 G
Prom. ascenso0.58 G
Prom. combustión4.96 G
Tiempos
Fin combustión (primero)1.14 s
Apogeo5.78 s
Posible eyección5.795 s
Aterrizaje30.95 s
Salida #1 ON0 s
Salida #1 OFF0 s
Ángulos
Ángulo de rampa ?18.2° ± 0.84°
Desvío de rampa ?no medido
Incl. máx. hasta fin comb. ?60.54°
Orientación ?76.02°
Desalineación de montaje ?no medido
Alabeo al lanzamiento71.53°
Cabeceo al lanzamiento40.32°
Giro máx. (comb.)2105.42 dps
Giro prom. (comb.)340.09 dps
Recovery
Single deploy
No dual deploy detected on this flight.
General
Fecha subida18-Oct at 14:58
Muestras de datos2662
Tiempo total grabación44.800 s
Prom. muestras/s59.4
Número de bloqueos1
Lanzamiento tras encendido6m 36s
Eje de referenciaY
Batería & temperatura
Batería inicio0%
Batería fin0%
Temperatura inicio22.05°C
Temperatura fin18.64°C
Temp. MT1 lanzamiento0°C
Reglas de salida
Sin reglas configuradas
Notas del usuario
Sin notas
Añada este dispositivo a su cuenta para editar
Vídeo Youtube
Sin vídeo
Añada este dispositivo a su cuenta para editar
Imágenes del vuelo 0
Sin imágenes
Flown as
Rocket
None
not linked
Motor configuration
None
no motor recorded
Loaded weight
None
not entered
Motores del vuelo
No se han añadido motores a este vuelo
Añada este dispositivo a su cuenta para editar
Cohete vinculado
Ningún cohete vinculado a este vuelo
Reglas de salida
Las reglas permiten al Mercury realizar acciones según las condiciones de vuelo. Cada regla tiene hasta 4 condiciones (A-D).
Rule 1
After launch onlyANY condition (OR)Active during lockout
ACTION:OUTPUT #1
Conditions
AAltitude above pad (m)>0
BAltitude above pad (m)>0
CAltitude above pad (m)>0
DAltitude above pad (m)>0
❌No se activó
Rule 2
After launch onlyANY condition (OR)Active during lockout
ACTION:OUTPUT #1
Conditions
AAltitude above pad (m)>0
BAltitude above pad (m)>0
CAltitude above pad (m)>0
DAltitude above pad (m)>0
❌No se activó
Rule 3
After launch onlyANY condition (OR)Active during lockout
ACTION:OUTPUT #1
Conditions
AAltitude above pad (m)>0
BAltitude above pad (m)>0
CAltitude above pad (m)>0
DAltitude above pad (m)>0
❌No se activó
Rule 4
After launch onlyANY condition (OR)Active during lockout
ACTION:OUTPUT #1
Conditions
AAltitude above pad (m)>0
BAltitude above pad (m)>0
CAltitude above pad (m)>0
DAltitude above pad (m)>0
❌No se activó
Rule 5
After launch onlyANY condition (OR)Active during lockout
ACTION:OUTPUT #1
Conditions
AAltitude above pad (m)>0
BAltitude above pad (m)>0
CAltitude above pad (m)>0
DAltitude above pad (m)>0
❌No se activó
Rule 6
After launch onlyANY condition (OR)Active during lockout
ACTION:OUTPUT #1
Conditions
AAltitude above pad (m)>0
BAltitude above pad (m)>0
CAltitude above pad (m)>0
DAltitude above pad (m)>0
❌No se activó
Coincidencia motor (BETA)
Aún en modo de prueba. Estamos averiguando qué motor se usó en el vuelo.
Marca
Motor
Puntos
Forma
Comb.
Estes
1/4A3T
15
77.9%
37.7%
Contrail
G300
12
-67.7%
20.4%

Linked flights

Connect flights that belong together: a second altimeter flown in the same rocket, or the same rocket flown again. Linked flights appear on each other’s pages.

No linked flights yet.

Sitio de lanzamiento, fecha y hora

Haga clic en el mapa para marcar su sitio de lanzamiento. Cambie entre vista de mapa y satélite.

Imagery © Esri, Maxar, Earthstar Geographics

Clic en el mapa · Arrastre para ajustar

Canopy height from the Meta and WRI High Resolution Canopy Height Maps v2 (Meta and World Resources Institute, 2026; source imagery © 2016 Vantor), used under CC BY 4.0. Ground elevation built from Terrain Tiles (Mapzen and AWS Open Data), derived from 3DEP and GMTED courtesy of the U.S. Geological Survey, SRTM courtesy of NASA, and ETOPO1 courtesy of NOAA. Map and imagery credited on the view above.

No launch site has been set for this flight.

Animación de datos

FLIGHT 3068

171.3 Meters

ALTITUDE
0.00m
VELOCITY
0.00m/s
ACCEL
0.00G
TILT
0.00°
PITCH
0.00°
ROLL
0.00°
YAW
0.00°
TIME
0.00s
AWAITING LAUNCH
ALT
altimetercloud.com
LAUNCH T+0.00s LANDING

BURNOUT

Motor burn complete

Nota: La animación de vuelo requiere que su altímetro esté montado en una orientación fija. Calibre sus sensores para mejores resultados.
Mercury V1
Revision 1
Mercury V1
Este vuelo se realizó con un Mercury V1.
The hardware
Versión hardwareRev 1
Versión software2.3
Última conexión18-Oct at 22:24
Sensor presiónBosch BMP 390
Acelerómetro32G 3-axis
Giroscopio2000 dgps 3-axis
MagnetómetroN/A

Settings, as they were for this flight

Ajustes generales del vuelo
Presión prevista
i
Set this to your local forecast pressure at sea level. This will offer you slightly improved accuracty for your flight, although it's not 100% essential every little helps!

Xcweather.co.uk is a decent place to grab pressures from for your location and time.
1013.25 mbar
Detección lanzamiento
i
This is the altitude above the launch pad altitude where the altimeter will trigger itself into recording / flight mode.

The altimeter keeps a constant average of the pressure while waiting for launch, it uses a simple algorithm and the pre-flight buffers to do this. The most recent 120 samples (~4 seconds) are ignored so your pre-trigger altitude won't effect the ground baseline.

For almost all uses we suggest keeping this on the 25 Meter (~82 feet) default settings. If you want to test your altimeter by throwing it in the air, or are planning a very low flight you may want to lower the setting.
meters
Sample ratio
i
The altimeter runs at 50Hz however you can record every sample or every X samples in order to extend the log time. For example if you set the ratio to 1 it will save 1:1 samples, or if you set it to 3 it will save 1 in 3 samples.
1:
Max samples
i
This is the maximum samples the altimeter will log per flight. When it reaches this amount it will stop and save the recording.
0
Recording stop
i
This setting is how the altimeter decides to stop recording. You can choose either 450 (~9s) or 900 (~18s) samples stable or it will record until the max samples limit unless you press the BUTTON in Manual stop mode.

The samples stable method waits for the devices altitude not to change for the set number of samples. This is defined by not changing by more than +/- 1.0 meters for 98% of the samples, it's a reliable method to stop the recording after landing within 8-10 seconds (300 sample) or 16-20 seconds (600 sample).
Oversampling
i
Oversampling is a internal setting of the BMP 390 pressure sensor. It is how many samples are taken for each reading. By taking multiple samples for each pressure reading the altimeter reduces noise and increases the resolution of the output.

The sensor can run at 50 samples per second in 4X mode, so we suggest leaving it in this mode as it will offer the highest accuracy.
DESACTIVADO
IIR filter
i
The IIR filter is another internal sensor for the BMP390 pressure sensor. It is a Infinite impulse response filter used to enhance pressure measurement accuracy by reducing noise. It's primarily for smoothing out rapid pressure changes.

We suggest not setting this too high as it will cause delay to changes in altitude if set very high.
DESACTIVADO
Pressure filter
i
This filter is a software Kalman filter that runs on the altimeters processor.

The Kalman filter uses a prediction step based on a system model and then a correction step using new measurements to refine its estimate, it creates accurate most certain results from data with noise in it.
Sync sensors
i
The filters on the pressure sensor can cause it to lag very slightly behind the Accelerometer and Gyroscope data. The Sync sensors option detects how far out of sync these sensors are. It then corrects the Acceleration and Gyroscope readings to match the pressure sensor.
DESACTIVADO
Orientation
i
This is the orientation you intend to install the Altimeter in your rocket. It's needed to ensure completly accurate angles and orientation charts and reports. Check out the Manual for more information on this.
Upwards (text up)
IMU filter
i
The IMU filter, or fusion filter takes the data from each axis of the Gyroscope and Accelerometer to calculate the Pitch, Roll, Yaw and tilt angle from vertical. These filters can build up some discrepency over time so it's important to calibrate your sensors to minimise this.
Mahony 6-Axis
Launch ALP
i
This is prevention against accidental launch detection.

With this disabled the launch is based only on pressure and something that creates a low pressure can trigger the flight by accident. For example pulling your nose cone off can even trigger it.

With this enabled the rocket also needs to have seen 8 samples (0.25 seconds) of acceleration above this setting in the last 3 seconds as well as the pressure drop to trigger. There is a backup trigger of 1.05 seconds of altitude being above the launch detect setting too.

There are very few situations where this option would cause issues, so we suggest leaving it on.
Disabled
Launch lock
i
When enabled, the altimeter locks out recording for a set period after power on to prevent false triggering during setup.
DISABLED
Static temperature
i
A fixed temperature value used for altitude calculation when the external temperature sensor is disabled or not connected.
15 °C
Temp sensor
i
If an external MT1 temperature sensor is connected, this controls whether it is used for logging only or also for altitude calculations.
Ajustes de salida
Salida 1 activada
i
Disable or enable the output from being able to turn on or off.
Salida 1 disparador
i
After apogee (altitude)
This method triggers when the altitude drops below the set altitude after apogee is detected.
After apogee (time)
This method triggers the defined seconds after apogee is detected.
After launch (altitude)
This method is activated if/once the altimeter exceeds the set altitude after launch.
After launch (time)
This option triggers the defined seconds after launch is detected.
After burnout (time)
This method triggers the defined seconds after burnout is detected.
Salida 1 tiempo encendido
i
This is how long the output should trigger ON state when the rules are met.
Salida 1 altitud
i
This is the altitude to trigger at if using a trigger method that works on altitude.

For example if you set this to 75m and After apogee (altitude) for the trigger then the output will turn on at 75m on descent above the launch altitude.
0 meters
Salida 1 tiempo
i
This is the time variable for output triggers that work on time.

For example if you set this to 3 seconds and After apogee (time) as the trigger then the output will turn on 3 seconds after apogee.
0 seconds
Bloqueo altitud
i
Altitude lock is a safety feature that prevents the output from triggering if the altitude is below this level when the rules are met.
0.00 m
Bloqueo inclinación
i
This is another safety feature. It can be used to disable the output if the rocket has gone too far from vertical.

For example if you set the tilt angle lock to 40 degrees then the output will not fire if the rocket is more than 40 degrees from vertical. To disable set this to 0.
0.00 °
Calibración de sensores
Compensaciones de calibración usadas en este vuelo.
Giroscopio⚠ El giroscopio no ha sido calibrado
X0.000°
Y0.000°
Z0.000°
Acelerómetro⚠ El acelerómetro no ha sido calibrado
X0.000 mG
Y0.000 mG
Z0.000 mG
Ajustes del dispositivo
TAG dispositivo
i
A custom name or tag assigned to this device for easy identification.
Idioma
i
The language setting configured on the device.
Modo apagado
i
Controls what happens after recording. Standard shuts down normally, Delayed keeps WiFi on for 30 seconds after landing, Stay on keeps the device powered on.
Brillo LED
i
The brightness level of the LED indicators on the Mercury. Lower values save battery.
Potencia WiFi TX
i
WiFi transmit power level. Higher gives better range but uses more battery.
Modo reposo
i
Controls whether the device enters low-power sleep when idle.
Stay awake
Monitor batería
i
Monitors battery voltage during the flight.
ENABLED
Grupo cloud
i
The cloud group / category this flight is assigned to.
Puertos GP6 / GP7
Configuración de los puertos GP6 y GP7 para canales pirotécnicos, servos u otros.
Modo canal 6
Ch6 min pulse (µs)
Ch6 max pulse (µs)
Ch6 frequency
Hz
Ch6 angle ON
°
Ch6 angle OFF
°
Ch6 on time
s
Modo canal 7
Ch7 min pulse (µs)
Ch7 max pulse (µs)
Ch7 frequency
Hz
Ch7 angle ON
°
Ch7 angle OFF
°
Ch7 on time
s
Placa servo I2C PCA9685
Configuration for the external I2C PCA9685 servo expansion board. This board provides up to 6 additional servo channels.
Servo board
i
Enable or disable the external I2C PCA9685 servo expansion board.
ENABLED
Oscillator freq
i
The oscillator frequency of the PCA9685 chip. Default is 25000000 (25 MHz). Adjust only if your board has a different crystal.
Hz
Min pulse width
i
The minimum pulse width in microseconds for the servo range. Standard servos typically use 500-600 µs as minimum.
µs
Max pulse width
i
The maximum pulse width in microseconds for the servo range. Standard servos typically use 2400-2500 µs as maximum.
µs
PWM frequency
i
The PWM frequency for all servos on the board. Standard servos use 50 Hz.
Hz
Servo 1
OFF: °
ON: °
Time: s
Servo 2
OFF: °
ON: °
Time: s
Servo 3
OFF: °
ON: °
Time: s
Servo 4
OFF: °
ON: °
Time: s
Servo 5
OFF: °
ON: °
Time: s
Servo 6
OFF: °
ON: °
Time: s
Predicción y aerofrenos
El Mercury puede predecir el apogeo durante la fase de planeo. Estos ajustes controlan el cálculo y el aerofreno.
Masa seca
i
The total mass of the rocket after motor burnout (dry mass). This is used for the ballistic prediction of apogee altitude. Enter the mass without the motor propellant, or the mass at burnout.
$tc_not_configured
Coef. arrastre
i
The aerodynamic drag coefficient (Cd) of the rocket. This is used with the rocket area to calculate aerodynamic drag during coast. A typical model rocket has a Cd of 0.4 to 0.8. You can find this value from OpenRocket or RockSim simulations.
$tc_not_configured
Área referencia
i
The cross-sectional reference area of the rocket in square meters. This is typically the area of a circle with the body tube diameter. For example a 38mm tube has an area of approximately 0.00113 m².
$tc_not_configured
Gas constant
i
The specific gas constant for dry air, used in the atmospheric model for altitude and density calculations. The standard value is 287.05 J/(kg·K). You shouldn't need to change this unless you know what you're doing.
$tc_not_configured
Los siguientes ajustes configuran el sistema de aerofreno.
Aerofreno activado
i
Enables or disables the active air braking system. When enabled, the Mercury will deploy air brakes via the configured servo channel to try and reach the target altitude. Firmware 2.1+ required.
OFF (default)
Servo channel
i
Which servo output channel the air brake mechanism is connected to. GP6 and GP7 are the two onboard servo headers, I2C channels are for an external servo expander board.
GP6
Deploy speed
i
The speed at which the air brakes deploy. The Mercury gradually increases the servo angle until the predicted apogee matches the target rather than going full on/off. This setting controls how quickly it ramps up to full braking.
Medium (default)
Altitud objetivo
i
The target apogee altitude in meters. The air brake system will try to slow the rocket so it reaches this altitude.
$tc_not_configured
Over shoot %
i
The percentage over the target altitude to aim for until within 15% of the target. This helps prevent undershooting if the prediction is slightly off early in the coast. For example, with a 1000m target and 5% early adjustment, the Mercury will aim for 1050m until it passes 850m.
$tc_not_configured
Activation altitude
i
The air brake system activates after burnout, but won't engage until the rocket has reached this percentage of the target altitude. This prevents the brakes from deploying too early when predictions may be less accurate.
20% (default)

Files

Where the altimeter signs its log, the file carries that signature and a tick beside it. A tick means the data is unchanged since the device wrote it, which is what a record claim needs.
CSV
3068.csv
The log as columns of text. Opens in a spreadsheet, and in every simulator that reads flight data.
240 KB
Adjusted CSV2904 recalculated in your browser
The log recomputed for your own sea-level pressure and temperature. Columns: time, altitude as recorded and adjusted, raw altitude as recorded and adjusted, pressure.

This file is built here from the signed log, so it carries no signature of its own. Anyone verifying a claim should be sent to the flight page and build their own from the original.

Custom CSVbuilt in your browser
Pick any of the chart’s data sets, the worked-out ones included, and the part of the flight to cover. Values come in the units the chart is set to.
In the file
Time span

One row for every time any chosen data set has a sample. A data set with no sample at that time is left blank rather than filled in. Built from the chart’s data, so it carries no signature.

El propietario de este dispositivo ha desactivado los comentarios en sus vuelos.
Inicia sesión para comentar.