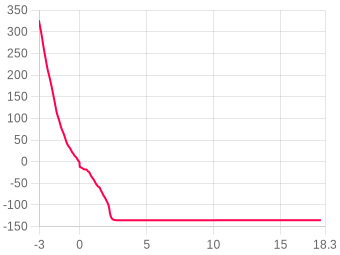
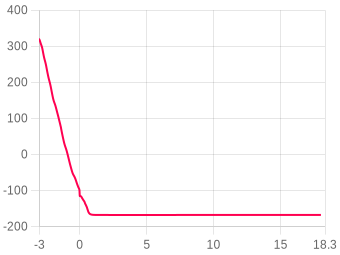
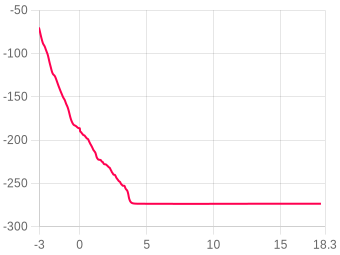
Odległość
Wybierz jednostkę odległości: Metry(m), Stopy(ft), Mile(mi) lub Kilometry(km)
Prędkość
Wybierz jednostkę prędkości: m/s, ft/s, mph lub km/h
Przyspieszenie
Wybierz jednostkę przyspieszenia: m/s² lub G
Lot 1837

Flight 1837

Mercury V1 Rev 3 · firmware 2.40
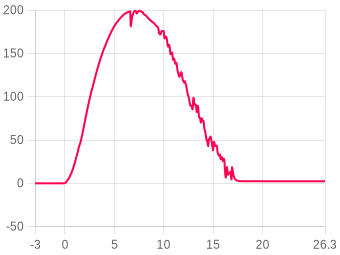
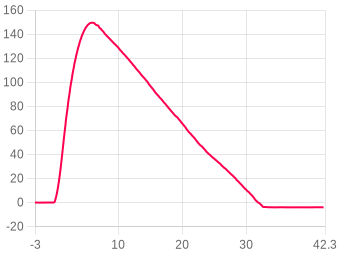
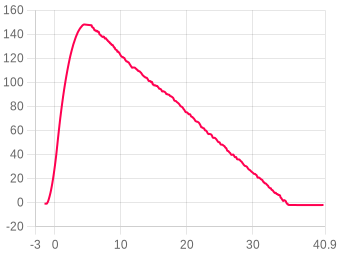
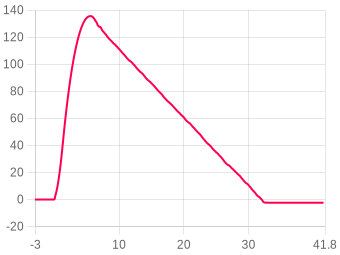
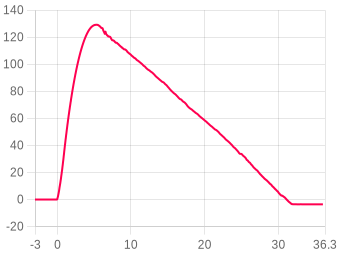
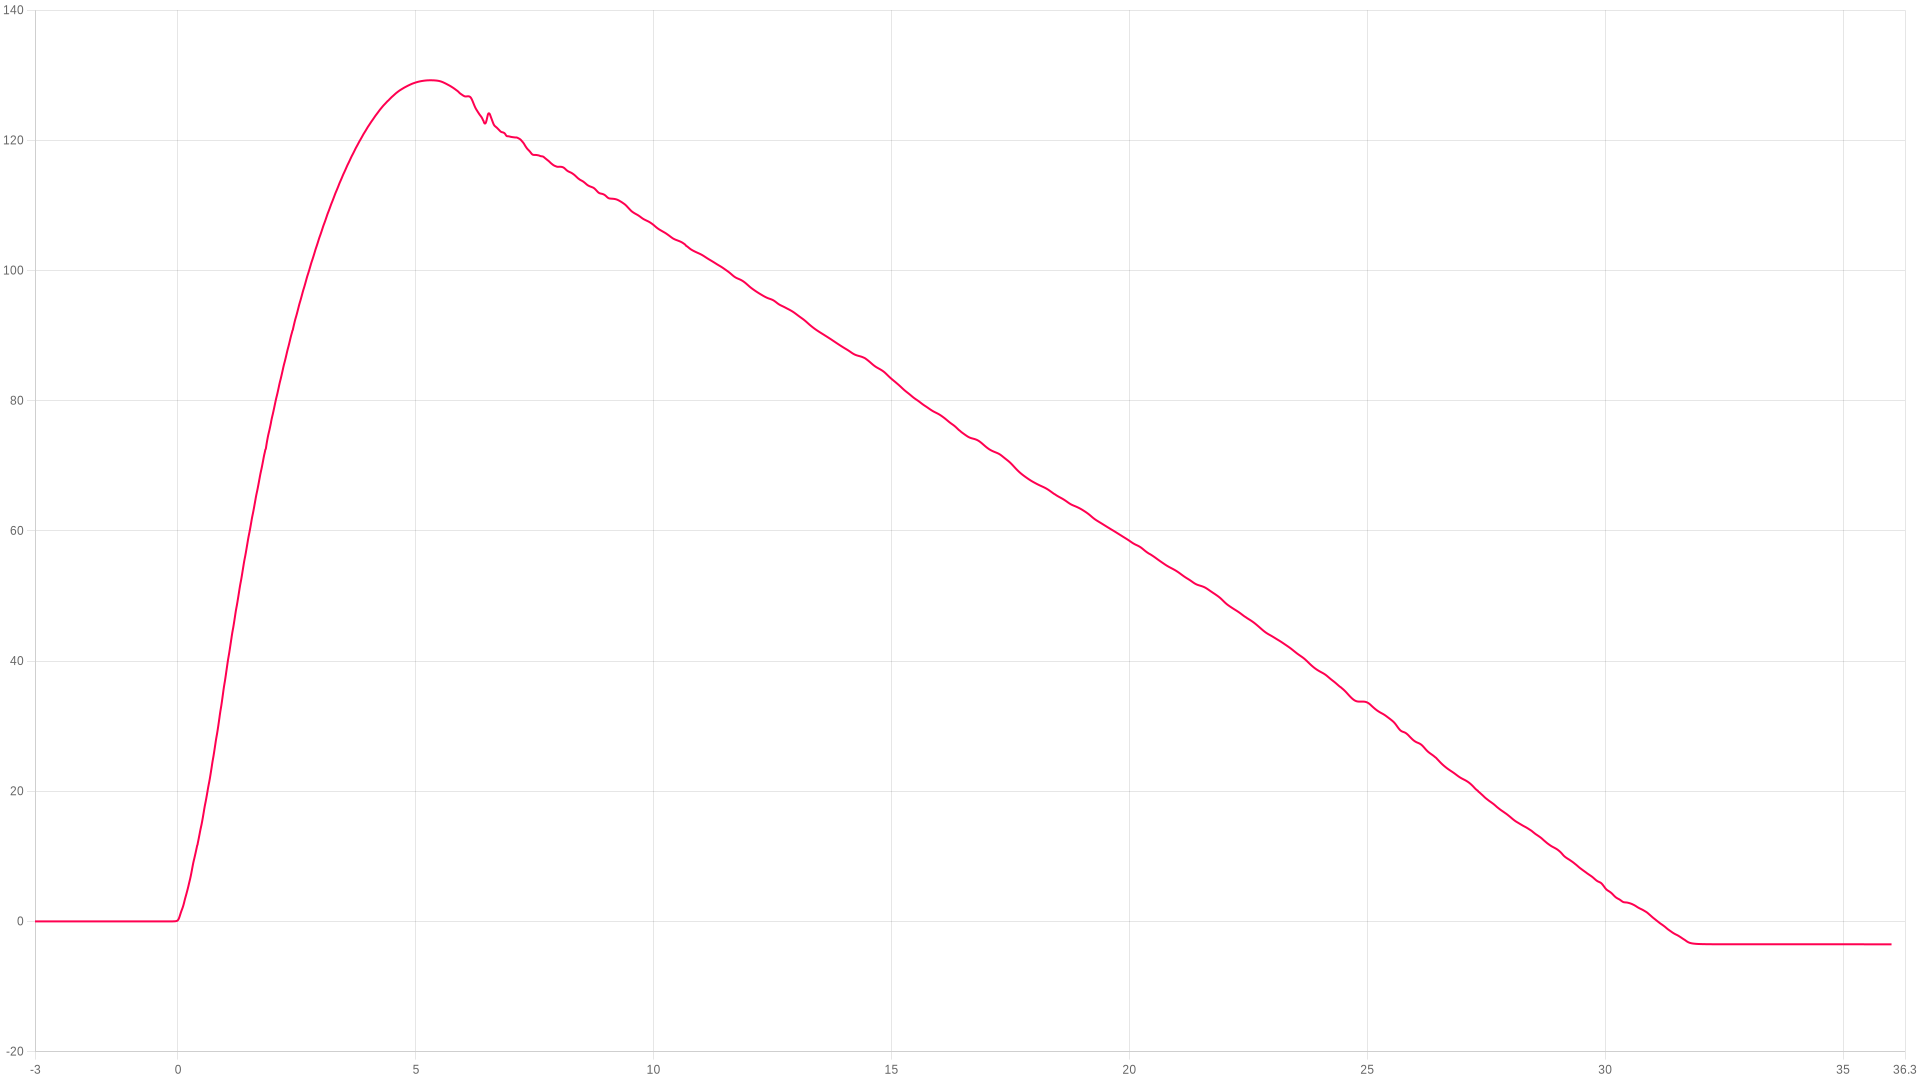
Apogeum
129.22m
5.31 s after launch
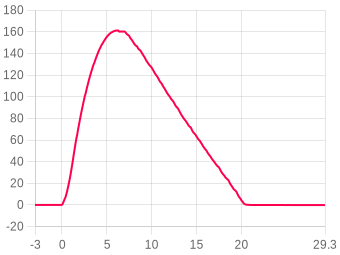
Maks. wznoszenie
48.92m/s
peak ascent
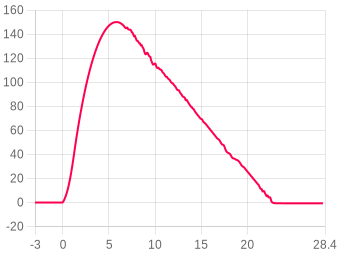
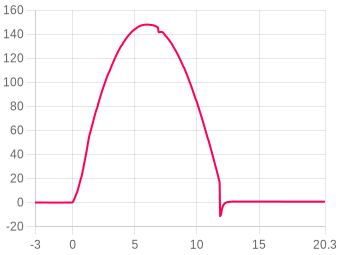
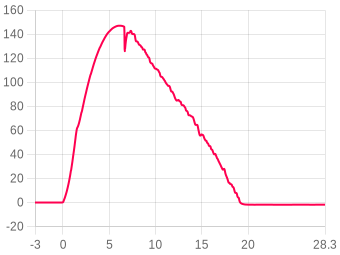
Maks. podczas spalania
11.87G
during the burn
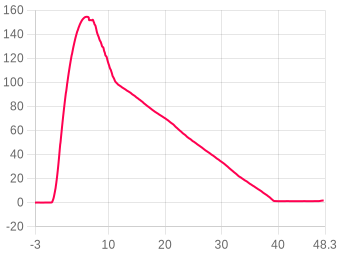
Lądowanie
32.02s
touchdown 5.22 m/s
ZOOM TO
s
s
Pokaž zdarzenia
Pobierz
Dostosuj temp. & ciśnienie ?
Obraz
Powiększenie
Kliknij i przeciągnij lub užyj gestu
Porównaj lot ?
Podsumowanie lotu

The flight, moment by moment

Liftoff
0 s
Nachylenie rampy47.30°
Thrust calc pad tilt5.4°
Launch detected
0.743 s
Wysokość25.06 m
Prędkość43.62 m/s
Wypalenie (pierwszy)
1.83 s
Wysokość72.12 m
Prędkość31.750 m/s
Apogeum
5.31 s
Wysokość129.22 Metry
Maks. nachylenie do wypalenia56.40°
Možliwy wyrzut
5.898 s
Wysokość127.47 m
Prędkość-6.89 m/s
Lądowanie
32.02 s
Wysokość-3.48 m
Maks. opadanie-13.41 m/s

Stabilność52.6%Umiarkowany

Nachylenie przy wypaleniu (20%)86.3
20% · Launch tilt 5.4°
Prędkość pochylania/odchylania (30%)33.6
25% · Coning 140.2/176.2°/s
Coning · boost (25%)24.3
25% · Spin 128.9°/s
Prostoliniowość ciągu (15%)69.4
30% · Thrust 93.4%

Rocket information

Calculated from the flight data alone
Boost acceleration17.3 m/s²
average over the burn · 1.8 g
Coast deceleration9.1 m/s²
average · gravity plus drag
Apogee lost to tilt0.57 m
flown vertical ≈ 129.7 m · from the thrust-calculated tilt
Chute opening peak19.28 G
largest deceleration after ejection
Average descent rate5.01 m/s
ejection to landing · 26.12 s
Bateria & temperatura 0% → 0% · Temperatura początek 26.7 → 27.17 °C · Start po włączeniu 2m 29s

About the stability score

Worked out from the flight log between liftoff and 80% of apogee. It is independent of the angle the altimeter was mounted at, so it measures the flight rather than the fitting.

Nachylenie przy wypaleniu (20%)20%How close to vertical it left the rod.
Prędkość pochylania/odchylania (30%)25%How much the nose swung off the rocket's own axis across the whole ascent.
Coning · boost (25%)25%The same swing during the burn, when it matters most.
Prostoliniowość ciągu (15%)30%How cleanly the motor pushed along the body.

Spin about the rocket's own axis is not counted against it — a fast, straight spin is stable. The figures beside the score are the raw measurements behind these four.

Wysokość
Apogeum129.22 Metry
Czas do apogeum5.31 s
Wysokość wypalenia72.12 m
Wys. maks. prędkości34.78 m
Wys. wyrzutu127.47 m
Wys. lądowania-3.48 m
Wysokość nagrywania-47.76 m
Prędkość
Maks. wznoszenie48.92 m/s
Maks. opadanie-13.41 m/s
Przy wypaleniu31.750 m/s
Prędk. opadania-4.898 m/s
Prędk. wyrzutu-6.89 m/s
Prędk. lądowania-5.216 m/s
Przyspieszenie
Maks. podczas spalania11.87 G
Maks. wznoszenie11.87 G
Maks. opadanie19.28 G
Śr. wznoszenie0.36 G
Śr. spalanie2.57 G
Czasy
Wypalenie (pierwszy)1.83 s
Apogeum5.31 s
Možliwy wyrzut5.898 s
Lądowanie32.02 s
Wyjście #1 WŁ0 s
Wyjście #1 WYŁ0 s
Kąty
Nachylenie rampy47.30°
Thrust calc pad tilt5.4°
Maks. nachylenie do wypalenia56.40°
Przechylenie startowe47.16°
Pochylenie startowe-2.84°
Maks. obrót (spal.)951.3 dps
Śr. obrót (spal.)223.59 dps
Recovery
Single deploy
No dual deploy detected on this flight.
Ogólne
Data przesłania21-Jun at 16:45
Próbki danych6458
Całkowity czas nagrania50.200 s
Śr. próbki/s128.6
Liczba blokad0
Start po włączeniu2m 29s
Oś referencyjnaX
Bateria & temperatura
Bateria początek0%
Bateria koniec0%
Temperatura początek26.7°C
Temperatura koniec27.17°C
Temp. MT1 startowa0°C
⚠ Niski poziom baterii — naładuj przed następnym lotem
Reguły wyjścia
Brak skonfigurowanych reguł
Notatki užytkownika
Brak notatek
Dodaj to urządzenie do swojego konta, aby edytować
Film Youtube
Brak filmu
Dodaj to urządzenie do swojego konta, aby edytować
Zdjęcia lotu 0
Brak zdjęć
Silniki lotu
1st stage · 5s delay
1×C6-5KlimaDetails
Burn time
1.6 s
Diameter
18.00 mm
Average thrust
6 N
Max thrust
15 N
Total weight
20.50 g
Propellant weight
9.60 g
Propellant type
composite
Impulse10Ns
Max thrust15N
Burn time1.6s
Impulse classC
1st stage thrustloading curve…
Motor data by ThrustCurve.org
Dodaj to urządzenie do swojego konta, aby edytować
Powiązana rakieta
Žadna rakieta nie jest powiązana z tym lotem
Flight mass
Liftoff mass147.2gestimated
Mass at burnout137.6gestimated
No mass is set for this flight, so Motor thrust (N) uses a mass estimated from the measured burn and the motors’ rated impulse. Set the rocket’s mass for the measured impulse and specific impulse.
Motor thrust (N) is on the chart, under Acceleration.
Rule events
No output rules fired during this flight.
Dopasowanie silnika (BETA)
Wciąż w trybie testowym! Pracujemy nad ustaleniem, jaki silnik był użyty.
Marka
Silnik
Wynik
Kształt
Spalanie
Klima
B4
94
85%
91.5%
Quest
B6W
63
87.4%
86.6%
Quest
B4~2
48
75%
85%
Loki
G94IB
40
63%
85.8%
TSP
D20
38
76.2%
87.9%
Contrail
J800
35
28.9%
70.2%
Estes
F50
30
56.3%
85.5%
AeroTech
F52C
30
52.7%
87.5%
Cesaroni
G106-SK
30
29.7%
83.9%
AeroTech
G54
30
69.7%
88.4%

Linked flights

Connect flights that belong together: a second altimeter flown in the same rocket, or the same rocket flown again. Linked flights appear on each other’s pages.

No linked flights yet.

Miejsce startu, data i godzina

Kliknij na mapę, aby oznaczyć miejsce startu. Przełączaj między widokiem mapy i satelity.

Imagery © Esri, Maxar, Earthstar Geographics

Kliknij na mapę · Przeciągnij, aby dostosować

Canopy height from the Meta and WRI High Resolution Canopy Height Maps v2 (Meta and World Resources Institute, 2026; source imagery © 2016 Vantor), used under CC BY 4.0. Ground elevation built from Terrain Tiles (Mapzen and AWS Open Data), derived from 3DEP and GMTED courtesy of the U.S. Geological Survey, SRTM courtesy of NASA, and ETOPO1 courtesy of NOAA. Map and imagery credited on the view above.

No launch site has been set for this flight.

Animacja danych lotu

FLIGHT 1837

129.22 Meters

ALTITUDE
0.00m
VELOCITY
0.00m/s
ACCEL
0.00G
TILT
0.00°
PITCH
0.00°
ROLL
0.00°
YAW
0.00°
TIME
0.00s
AWAITING LAUNCH
ALT
altimetercloud.com
LAUNCH T+0.00s LANDING

BURNOUT

Motor burn complete

Uwaga: Animacja lotu wymaga montażu wysokościomierza w stałej orientacji. Skalibruj czujniki dla najlepszych wyników.
Mercury V1
Revision 3
Mercury V1
Ten lot został wykonany na Mercury V1.
The hardware
Wersja sprzętuRev 3
Wersja oprogramowania2.40
Ostatnio online24-Jun at 12:54
Czujnik ciśnieniaBosch BMP 581
Akcelerometr32G 3-axis
Gyroskop2000 dgps 3-axis
MagnetometrN/A

Settings, as they were for this flight

Ogólne ustawienia lotu
Ciśnienie prognozowane
i
Set this to your local forecast pressure at sea level. This will offer you slightly improved accuracty for your flight, although it's not 100% essential every little helps!

Xcweather.co.uk is a decent place to grab pressures from for your location and time.
1013.2 mbar
Detekcja startu
i
This is the altitude above the launch pad altitude where the altimeter will trigger itself into recording / flight mode.

The altimeter keeps a constant average of the pressure while waiting for launch, it uses a simple algorithm and the pre-flight buffers to do this. The most recent 120 samples (~4 seconds) are ignored so your pre-trigger altitude won't effect the ground baseline.

For almost all uses we suggest keeping this on the 25 Meter (~82 feet) default settings. If you want to test your altimeter by throwing it in the air, or are planning a very low flight you may want to lower the setting.
25 meters
Sample ratio
i
The altimeter runs at 50Hz however you can record every sample or every X samples in order to extend the log time. For example if you set the ratio to 1 it will save 1:1 samples, or if you set it to 3 it will save 1 in 3 samples.
1:5 (hybrid, reduces after apogee)
Max samples
i
This is the maximum samples the altimeter will log per flight. When it reaches this amount it will stop and save the recording.
18000
Recording stop
i
This setting is how the altimeter decides to stop recording. You can choose either 450 (~9s) or 900 (~18s) samples stable or it will record until the max samples limit unless you press the BUTTON in Manual stop mode.

The samples stable method waits for the devices altitude not to change for the set number of samples. This is defined by not changing by more than +/- 1.0 meters for 98% of the samples, it's a reliable method to stop the recording after landing within 8-10 seconds (300 sample) or 16-20 seconds (600 sample).
Auto: 450 samples stable (~9s)
Oversampling
i
Oversampling is a internal setting of the BMP 390 pressure sensor. It is how many samples are taken for each reading. By taking multiple samples for each pressure reading the altimeter reduces noise and increases the resolution of the output.

The sensor can run at 50 samples per second in 4X mode, so we suggest leaving it in this mode as it will offer the highest accuracy.
16x Oversampling
IIR filter
i
The IIR filter is another internal sensor for the BMP390 pressure sensor. It is a Infinite impulse response filter used to enhance pressure measurement accuracy by reducing noise. It's primarily for smoothing out rapid pressure changes.

We suggest not setting this too high as it will cause delay to changes in altitude if set very high.
COEFF 7
Pressure filter
i
This filter is a software Kalman filter that runs on the altimeters processor.

The Kalman filter uses a prediction step based on a system model and then a correction step using new measurements to refine its estimate, it creates accurate most certain results from data with noise in it.
Kalman 2 (default)
Lockout change
i
This is how we detect a lockout. If the pressure changes by this much in a single sample downwards (pressure increase, lower altitude) then it's likely to be a false reading. Multiply the setting by 32 to get the speed in meters per second that it will trigger at.
0.5 meters
Sync sensors
i
The filters on the pressure sensor can cause it to lag very slightly behind the Accelerometer and Gyroscope data. The Sync sensors option detects how far out of sync these sensors are. It then corrects the Acceleration and Gyroscope readings to match the pressure sensor.
WŁĄCZONY (88 samples / 351.00ms)
Orientation
i
This is the orientation you intend to install the Altimeter in your rocket. It's needed to ensure completly accurate angles and orientation charts and reports. Check out the Manual for more information on this.
Upwards (text up)
IMU filter
i
The IMU filter, or fusion filter takes the data from each axis of the Gyroscope and Accelerometer to calculate the Pitch, Roll, Yaw and tilt angle from vertical. These filters can build up some discrepency over time so it's important to calibrate your sensors to minimise this.
Madgwick 6-Axis
Launch ALP
i
This is prevention against accidental launch detection.

With this disabled the launch is based only on pressure and something that creates a low pressure can trigger the flight by accident. For example pulling your nose cone off can even trigger it.

With this enabled the rocket also needs to have seen 8 samples (0.25 seconds) of acceleration above this setting in the last 3 seconds as well as the pressure drop to trigger. There is a backup trigger of 1.05 seconds of altitude being above the launch detect setting too.

There are very few situations where this option would cause issues, so we suggest leaving it on.
1.4G
Launch lock
i
When enabled, the altimeter locks out recording for a set period after power on to prevent false triggering during setup.
DISABLED
Static temperature
i
A fixed temperature value used for altitude calculation when the external temperature sensor is disabled or not connected.
15.00 °C
Temp sensor
i
If an external MT1 temperature sensor is connected, this controls whether it is used for logging only or also for altitude calculations.
DISABLED
Ustawienia wyjścia
Arm switch
i
When enabled, GP6 is a hardware arm switch — outputs and rules are held off until the switch is closed to ground.
DISABLED
Startup lockout
i
Outputs and rules are blocked for this many seconds after power-on while sensors settle. 0 = off.
None
Launch confirm delay
i
After launch is detected, outputs and rules won't fire until this many seconds have passed.
—
Altitude floor
i
Outputs and rules are blocked until the rocket is at least this height above the launch pad.
—
Custom dataset 1
i
User-defined expression evaluated per sample, available for charting.
—
Custom dataset 2
—
Kalibracja czujników
Przesunięcia kalibracji użyte w tym locie.
Gyroskop⚠ Gyroskop nie został skalibrowany
X0.000°
Y0.000°
Z0.000°
Akcelerometr⚠ Akcelerometr nie został skalibrowany
X0.000 mG
Y0.000 mG
Z0.000 mG
Ustawienia urządzenia
TAG urządzenia
i
A custom name or tag assigned to this device for easy identification.
Merc8360
Język
i
The language setting configured on the device.
🇬🇧 English
Tryb wyłączania
i
Controls what happens after recording. Standard shuts down normally, Delayed keeps WiFi on for 30 seconds after landing, Stay on keeps the device powered on.
Delayed 30s
Jasność LED
i
The brightness level of the LED indicators on the Mercury. Lower values save battery.
20%
WiFi TX power
i
WiFi transmit power level. Higher gives better range but uses more battery.
2 dBm (low)
Tryb uśpienia
i
Controls whether the device enters low-power sleep when idle.
Normal (sleep when idle)
Monitor baterii
i
Monitors battery voltage during the flight.
DISABLED
Cloud group
i
The cloud group / category this flight is assigned to.
Porty GP6 / GP7
Konfiguracja portów GP6 i GP7 dla kanałów pirotechnicznych, serw lub innych urządzeń.
Channel 6 mode
ON = HIGH
Ch6 min pulse (µs)
1000
Ch6 max pulse (µs)
2000
Ch6 frequency
50 Hz
Ch6 angle ON
170.00°
Ch6 angle OFF
10.00°
Ch6 on time
2.00s
Channel 7 mode
ON = HIGH
Ch7 min pulse (µs)
1000
Ch7 max pulse (µs)
2000
Ch7 frequency
50 Hz
Ch7 angle ON
170.00°
Ch7 angle OFF
10.00°
Ch7 on time
2.00s
Płytka servo I2C PCA9685
Configuration for the external I2C PCA9685 servo expansion board. This board provides up to 6 additional servo channels.
No I2C servo board was connected for this flight.
Prognoza i hamulce powietrzne
The Mercury can predict apogee while coasting after burnout. These settings control the prediction calculation and optional air brake system.
Dry mass
i
The total mass of the rocket after motor burnout (dry mass). This is used for the ballistic prediction of apogee altitude. Enter the mass without the motor propellant, or the mass at burnout.
$tc_not_configured
Drag Cd
i
The aerodynamic drag coefficient (Cd) of the rocket. This is used with the rocket area to calculate aerodynamic drag during coast. A typical model rocket has a Cd of 0.4 to 0.8. You can find this value from OpenRocket or RockSim simulations.
$tc_not_configured
Reference area
i
The cross-sectional reference area of the rocket in square meters. This is typically the area of a circle with the body tube diameter. For example a 38mm tube has an area of approximately 0.00113 m².
$tc_not_configured
Gas constant
i
The specific gas constant for dry air, used in the atmospheric model for altitude and density calculations. The standard value is 287.05 J/(kg·K). You shouldn't need to change this unless you know what you're doing.
$tc_not_configured
The following settings configure the air brake system.
Air brake enabled
i
Enables or disables the active air braking system. When enabled, the Mercury will deploy air brakes via the configured servo channel to try and reach the target altitude. Firmware 2.1+ required.
OFF (default)
Servo channel
i
Which servo output channel the air brake mechanism is connected to. GP6 and GP7 are the two onboard servo headers, I2C channels are for an external servo expander board.
GP6
Deploy speed
i
The speed at which the air brakes deploy. The Mercury gradually increases the servo angle until the predicted apogee matches the target rather than going full on/off. This setting controls how quickly it ramps up to full braking.
Medium (default)
Target altitude
i
The target apogee altitude in meters. The air brake system will try to slow the rocket so it reaches this altitude.
$tc_not_configured
Over shoot %
i
The percentage over the target altitude to aim for until within 15% of the target. This helps prevent undershooting if the prediction is slightly off early in the coast. For example, with a 1000m target and 5% early adjustment, the Mercury will aim for 1050m until it passes 850m.
$tc_not_configured
Activation altitude
i
The air brake system activates after burnout, but won't engage until the rocket has reached this percentage of the target altitude. This prevents the brakes from deploying too early when predictions may be less accurate.
20% (default)

Files

Where the altimeter signs its log, the file carries that signature and a tick beside it. A tick means the data is unchanged since the device wrote it, which is what a record claim needs.
CSV
1837.csv
The log as columns of text. Opens in a spreadsheet, and in every simulator that reads flight data.
537 KB
Adjusted CSV2904 recalculated in your browser
The log recomputed for your own sea-level pressure and temperature. Columns: time, altitude as recorded and adjusted, raw altitude as recorded and adjusted, pressure.

This file is built here from the signed log, so it carries no signature of its own. Anyone verifying a claim should be sent to the flight page and build their own from the original.

Custom CSVbuilt in your browser
Pick any of the chart’s data sets, the worked-out ones included, and the part of the flight to cover. Values come in the units the chart is set to.
In the file
Time span

One row for every time any chosen data set has a sample. A data set with no sample at that time is left blank rather than filled in. Built from the chart’s data, so it carries no signature.

Lot
Komentarze
Zaloguj się aby komentować.