Divagações sobre Programação e Eletrônica
 Divagações sobre Programação e Eletrônica
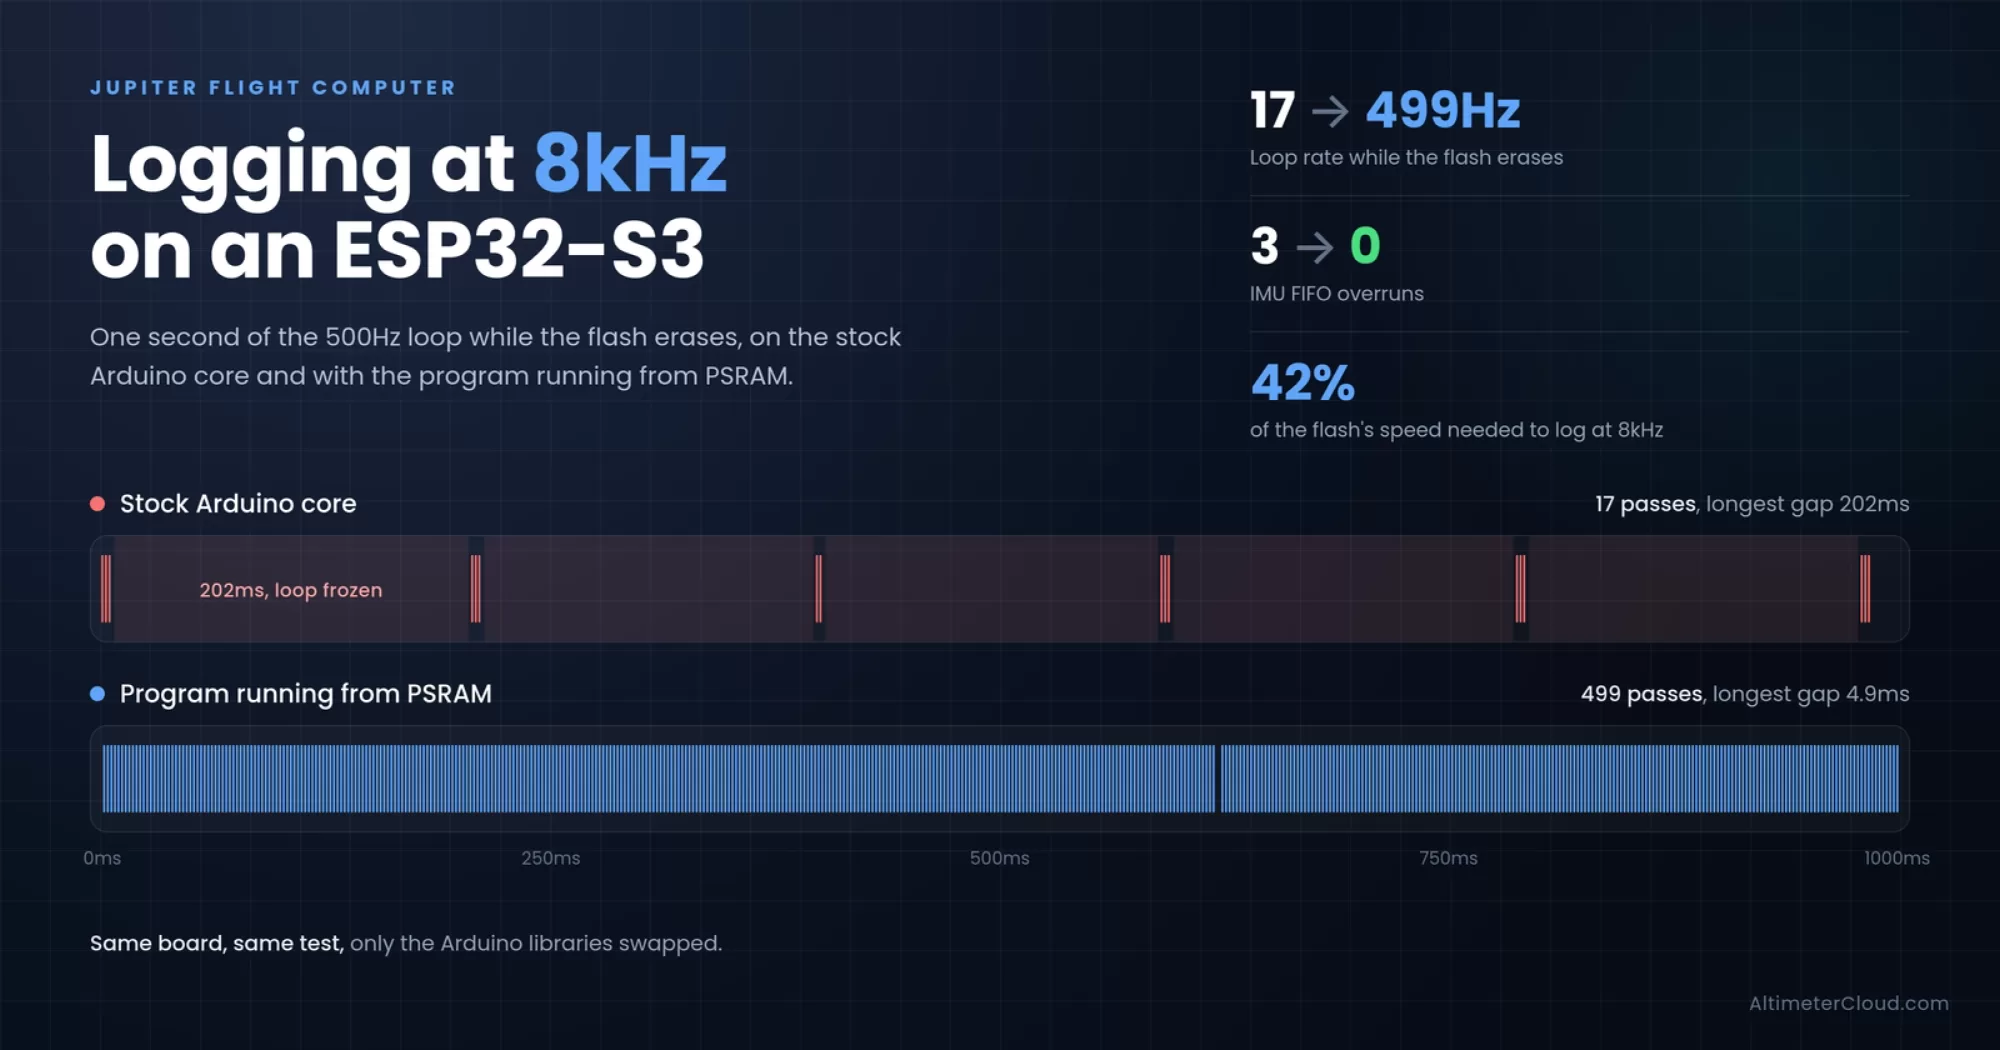
Logging em 8kHz em um ESP32-S3 no Arduino: executando o programa da PSRAM (XiP)
O ESP32-S3 consegue realmente registrar a 8kHz ou superior? Nós medimos. O limite acaba sendo a memória flash, não a CPU, e executar o programa a partir da PSRAM resolve. Resultados de teste, mais nossas bibliotecas Arduino reconstruídas para baixar.
 Divagações sobre Programação e Eletrônica
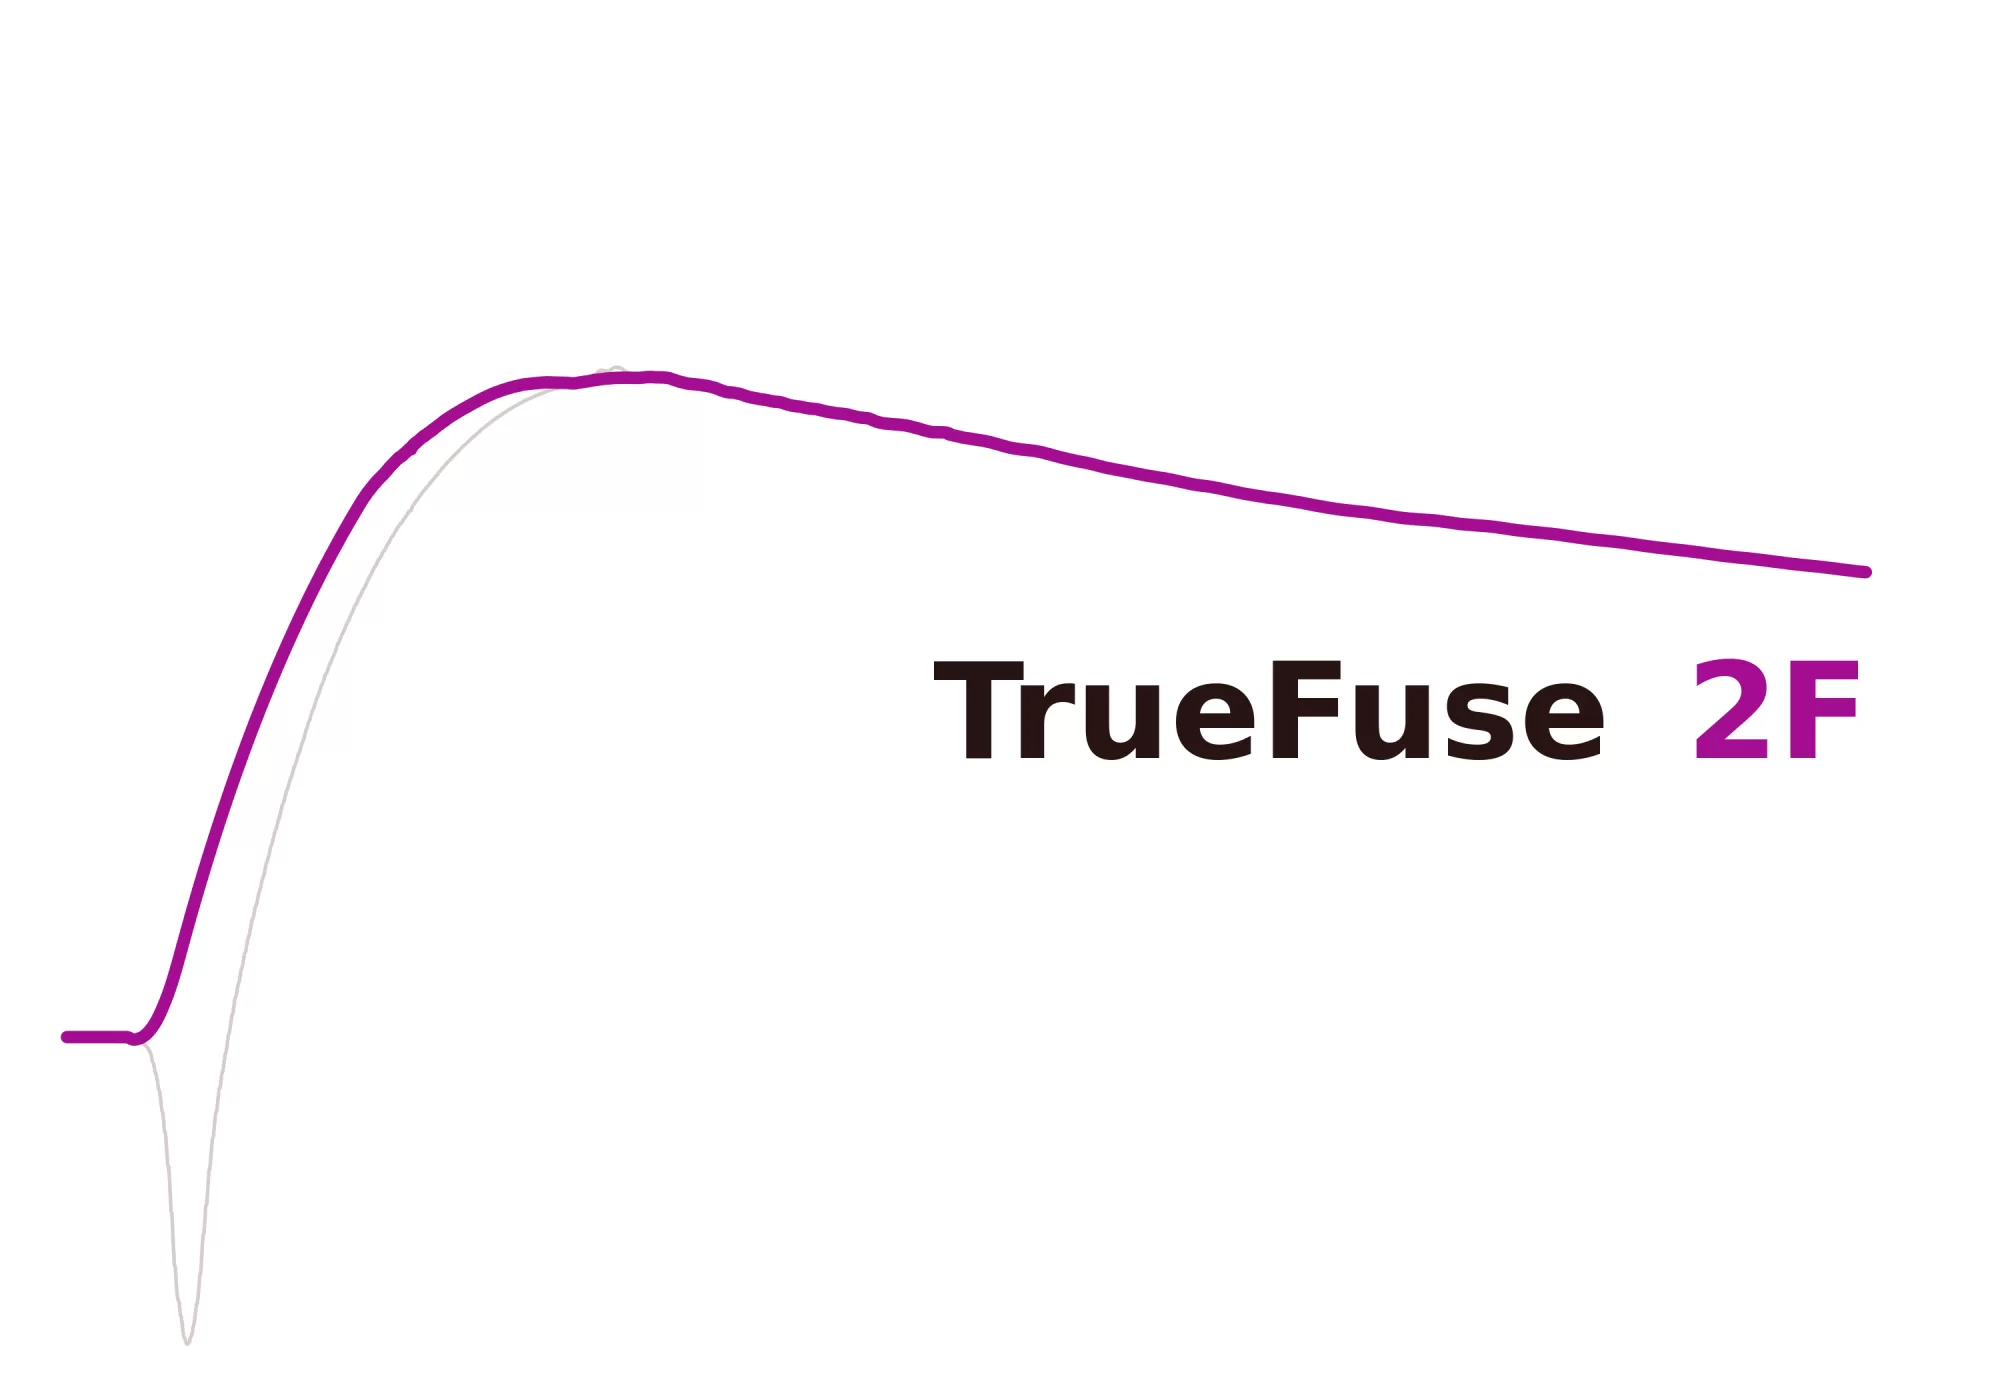
TrueFuse 2F: Measuring the Port Instead of Trusting It
The third part of the altitude fusion filter behind AltimeterCloud. A port coefficient measured rather than assumed, a slew witness taught to look both ways, an ejection charge that reads the wrong way up, and the same law ported into two firmwares that could not be built more…
Read more →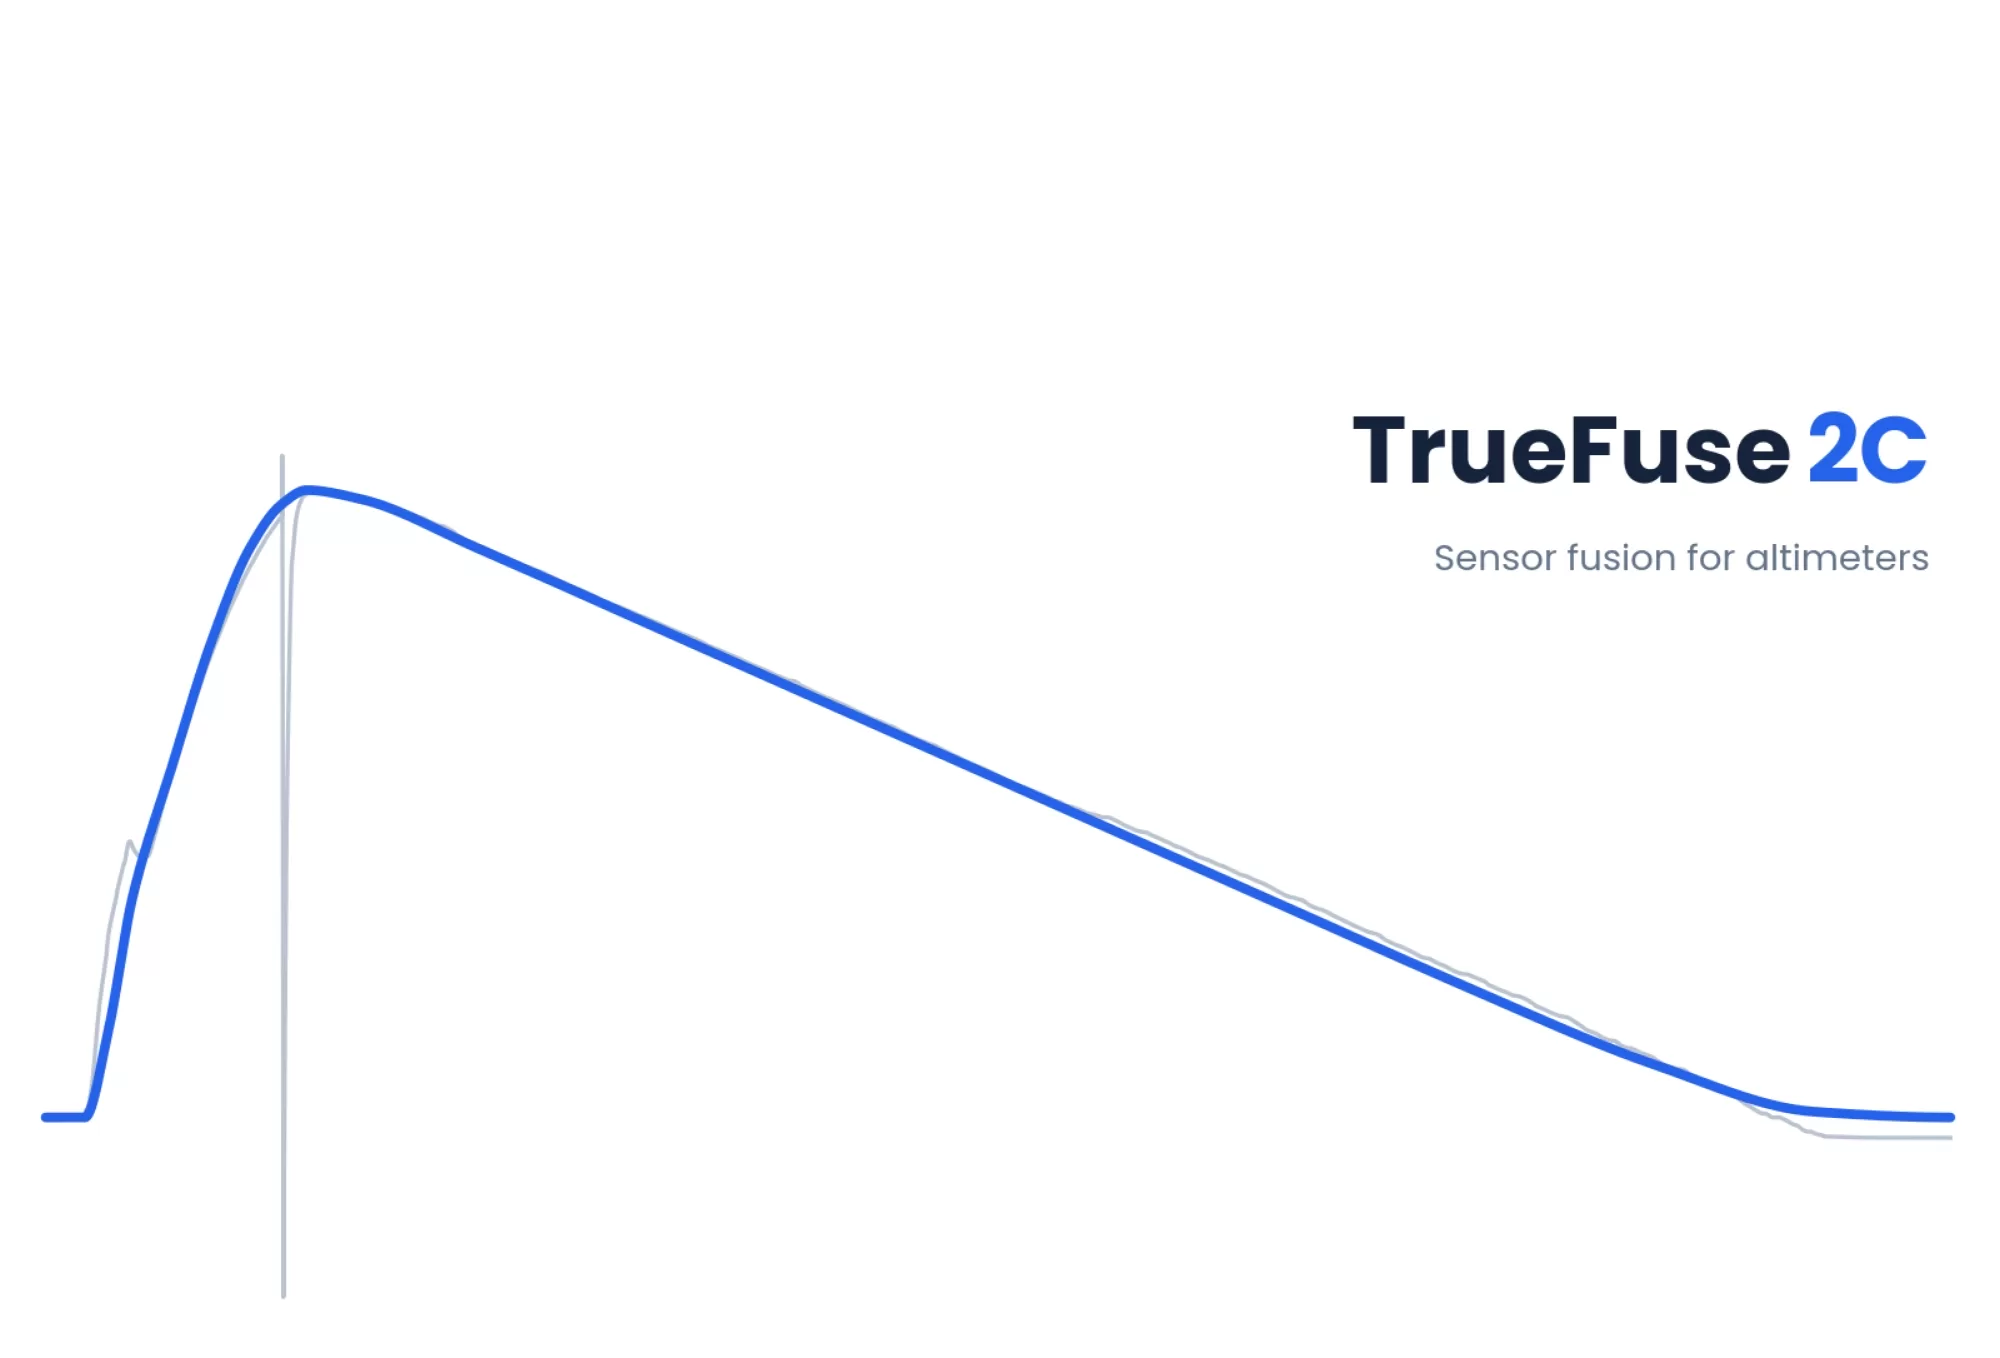 Divagações sobre Programação e Eletrônica
TrueFuse 2C: How Our Model Rocket Altimeters Fuse Sensors for Accurate Altitude
Barometric pressure sensors are superb at rest, but a rocket flight attacks them: airflow over the static port during the burn, ejection charge spikes, transonic effects, even sunlight under the parachute. TrueFuse 2C is the sensor fusion filter behind AltimeterCloud and our…
Read more →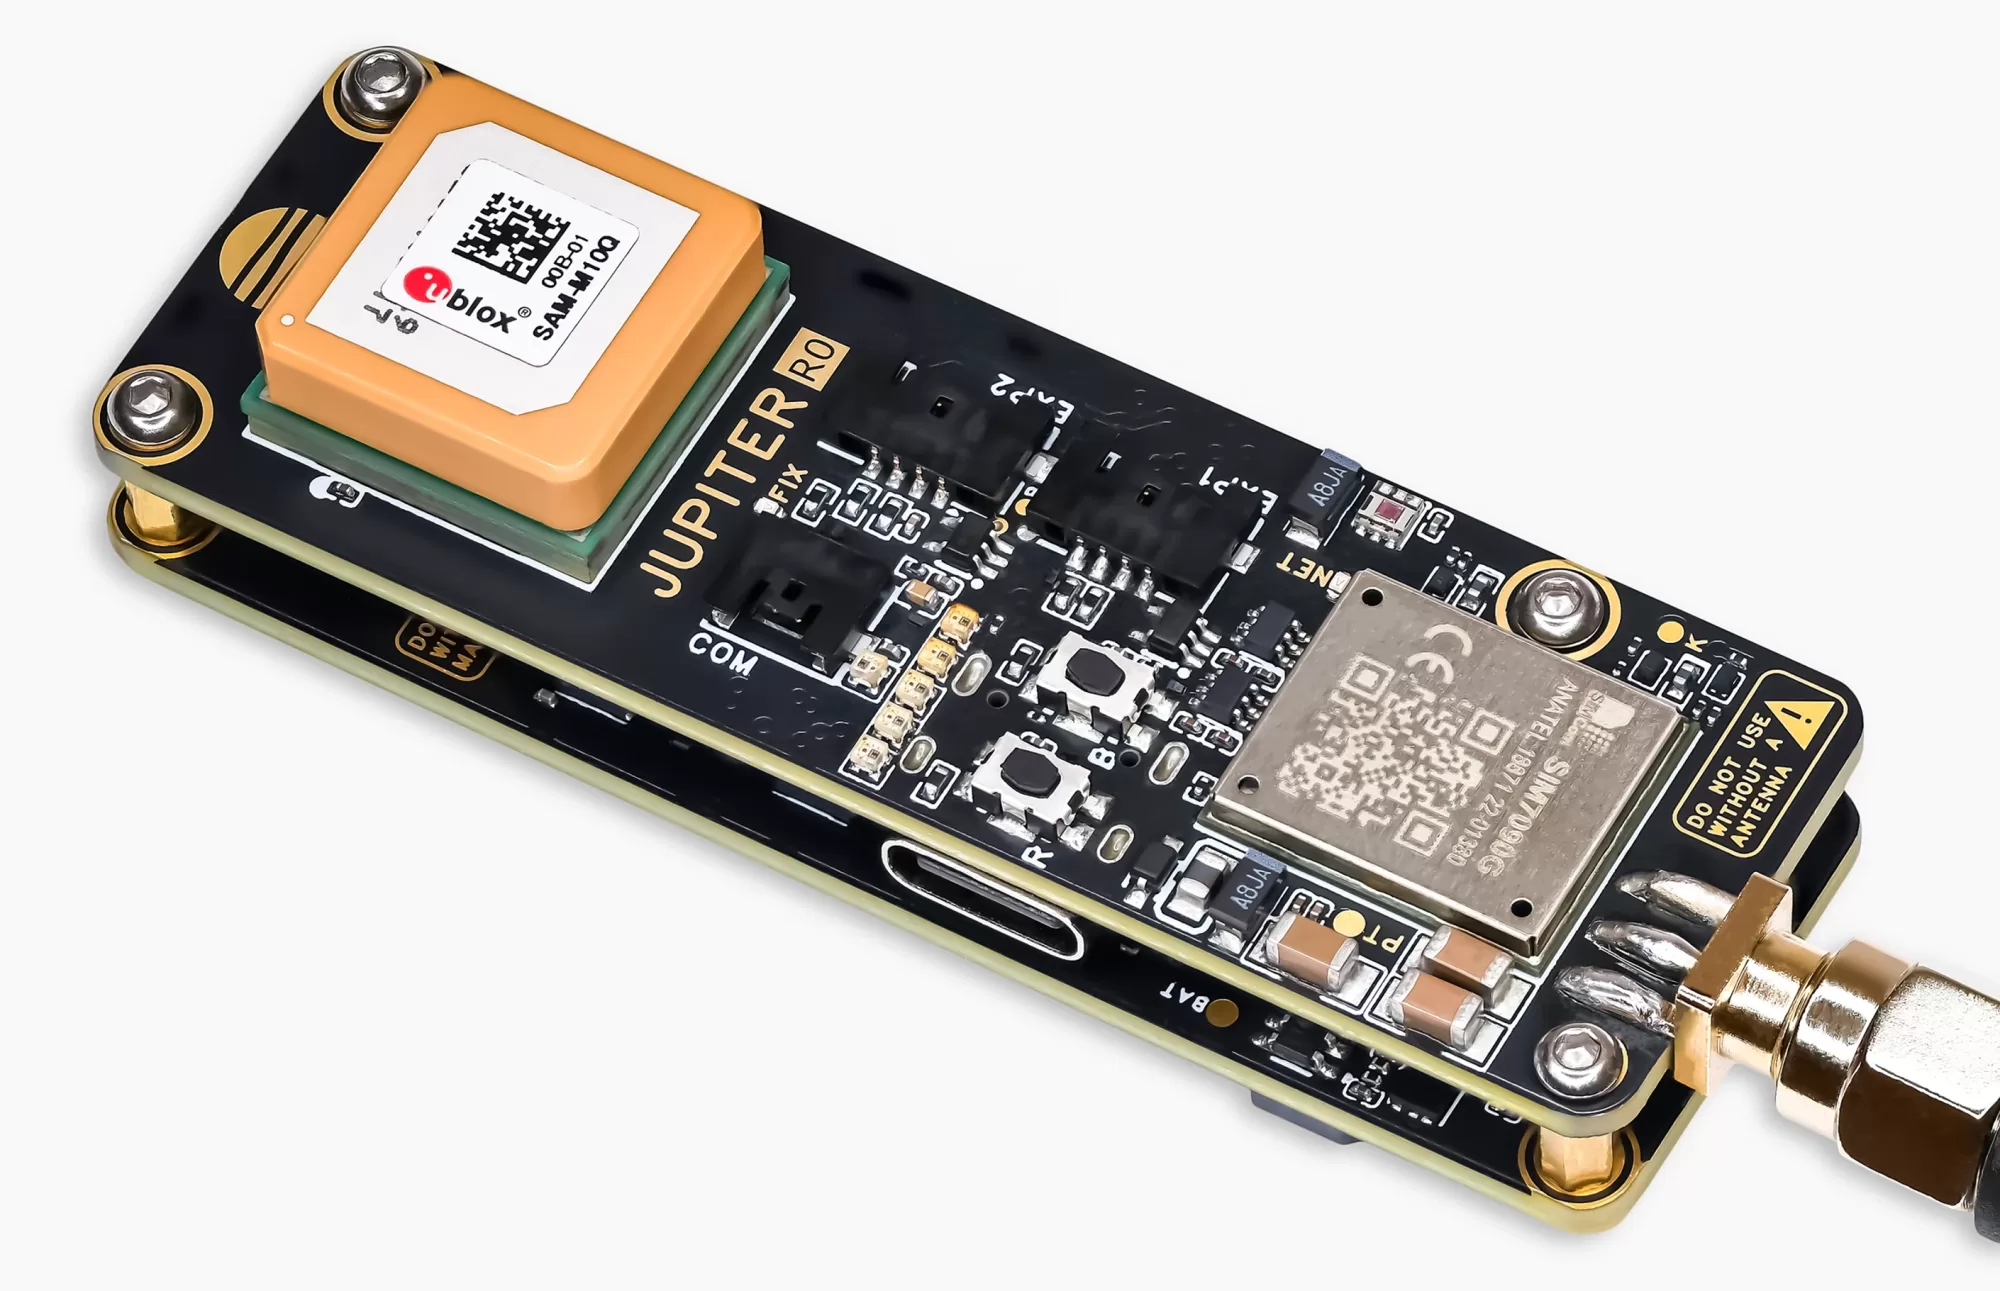 Divagações sobre Programação e Eletrônica
The u-blox SAM-M10Q in flight: settings, seeding and ground plane
A full walkthrough of GNSS on Jupiter: what the ground plane actually needs, which UBX settings matter and which to leave alone, how we build AssistNow-equivalent orbit data from public ephemeris and get it onto the device over LTE-M, and how we inject and seed it. With Arduino…
Read more →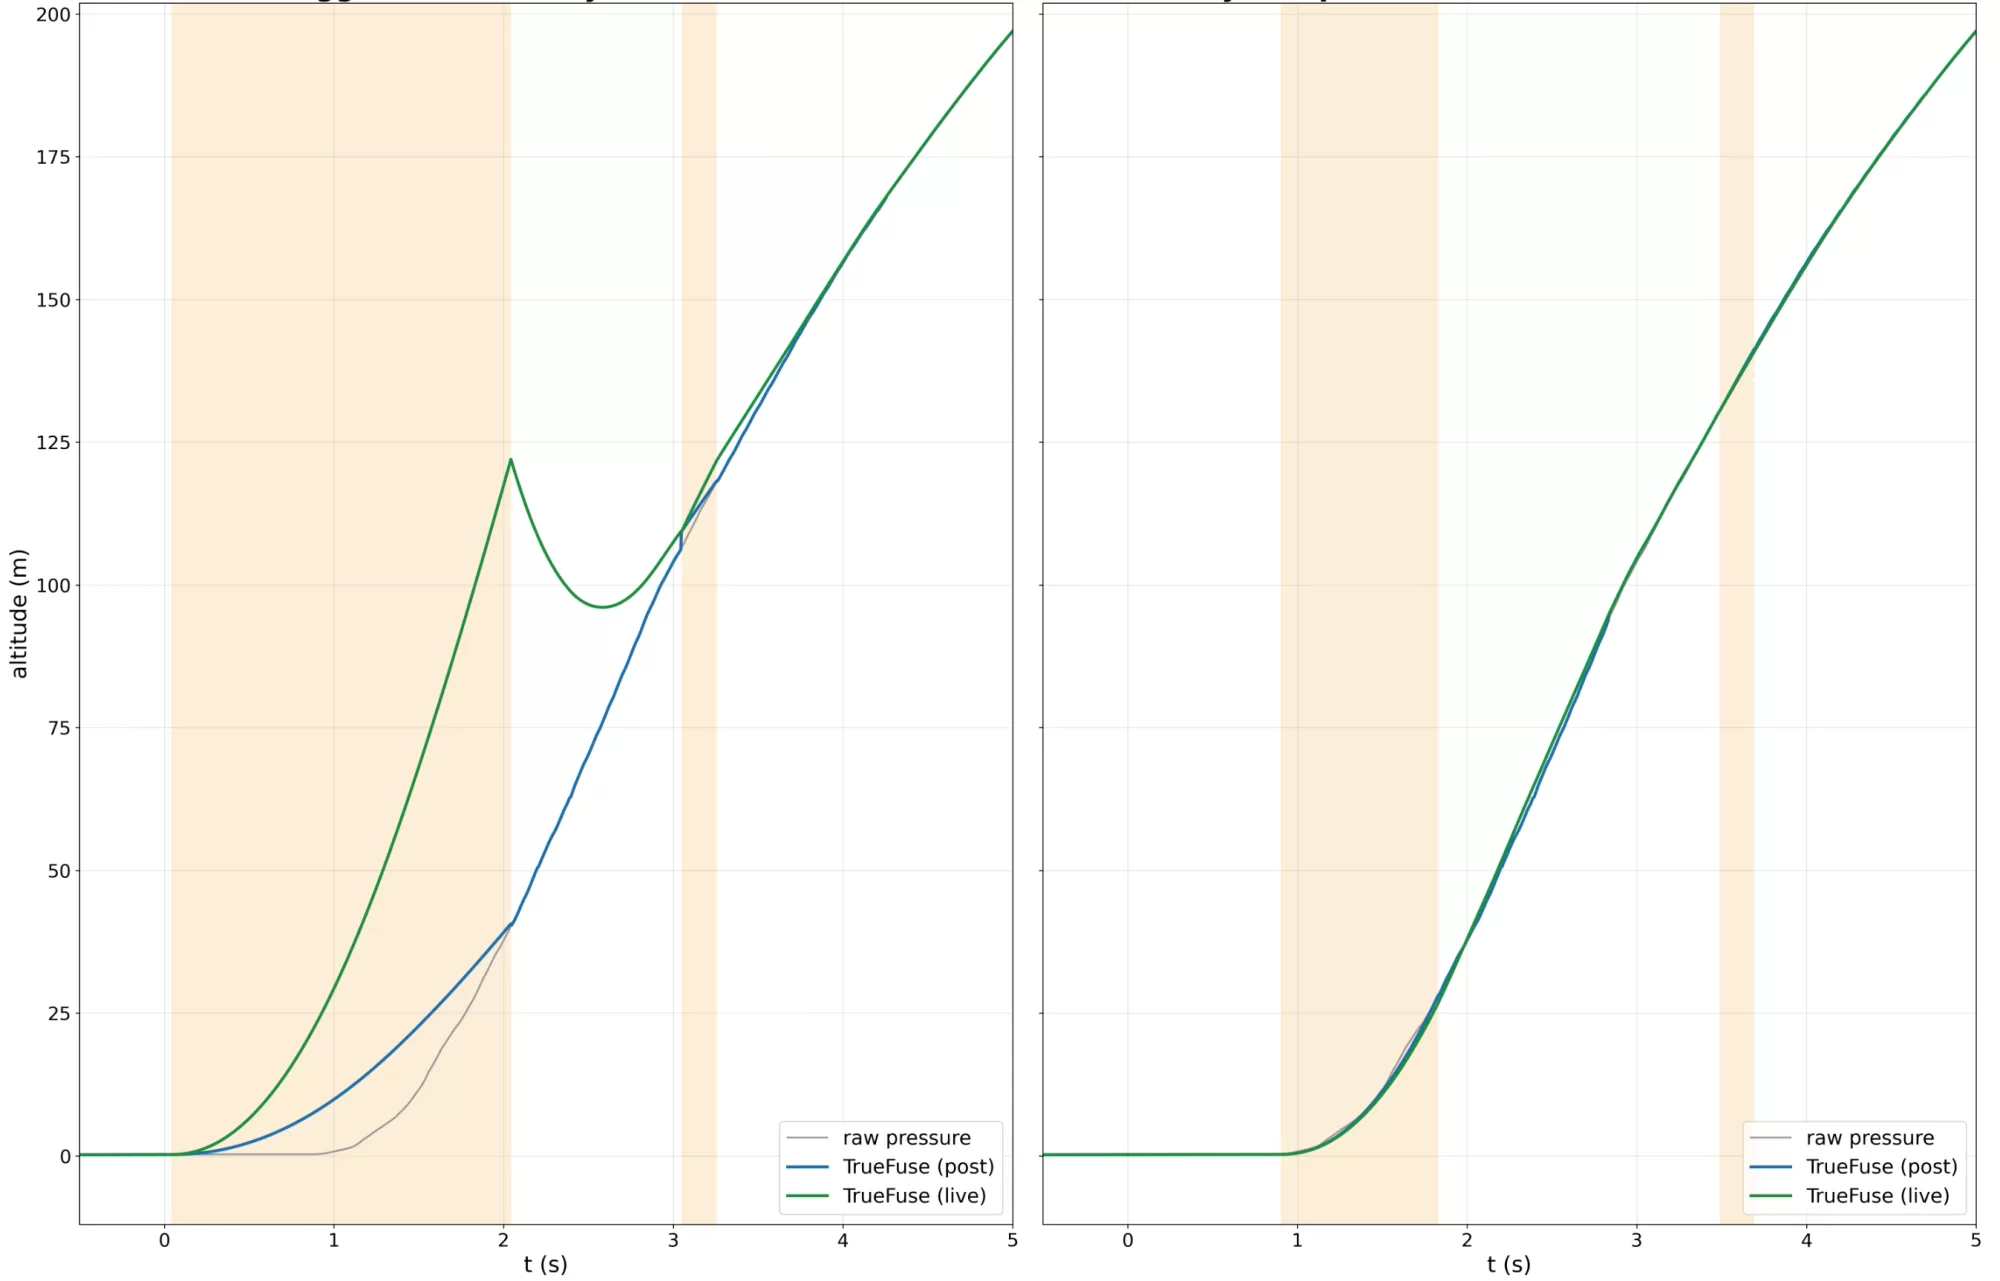 Divagações sobre Programação e Eletrônica
Atraso do sensor de pressão barométrica e como corrigi-lo
Toda altitude de pressão registrada está desatualizada no momento em que você a anota. Nosso firmware costumava medir esse atraso no lançamento, até que um log de voo mostrou um retorno de 300 ms quando a resposta real era 111 ms, e o TrueFuse começou a reparar falhas de pressão…
Read more →