Vzdálenost
Zvolte jednotku vzdálenosti: Metry(m), Stopy(ft), Míle(mi) nebo Kilometry(km)
Rychlost
Zvolte jednotku rychlosti: m/s, ft/s, mph nebo km/h
Zrychlení
Zvolte jednotku zrychlení: m/s² nebo G
Let 1734

200Hz Nano test (2)

Nano V1 Rev 4 · firmware 1.52
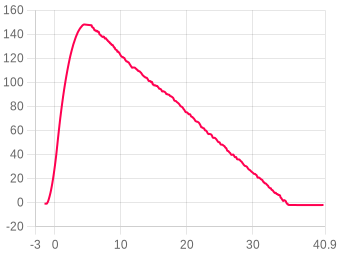
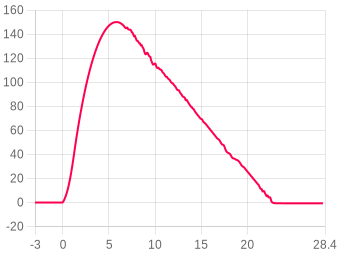
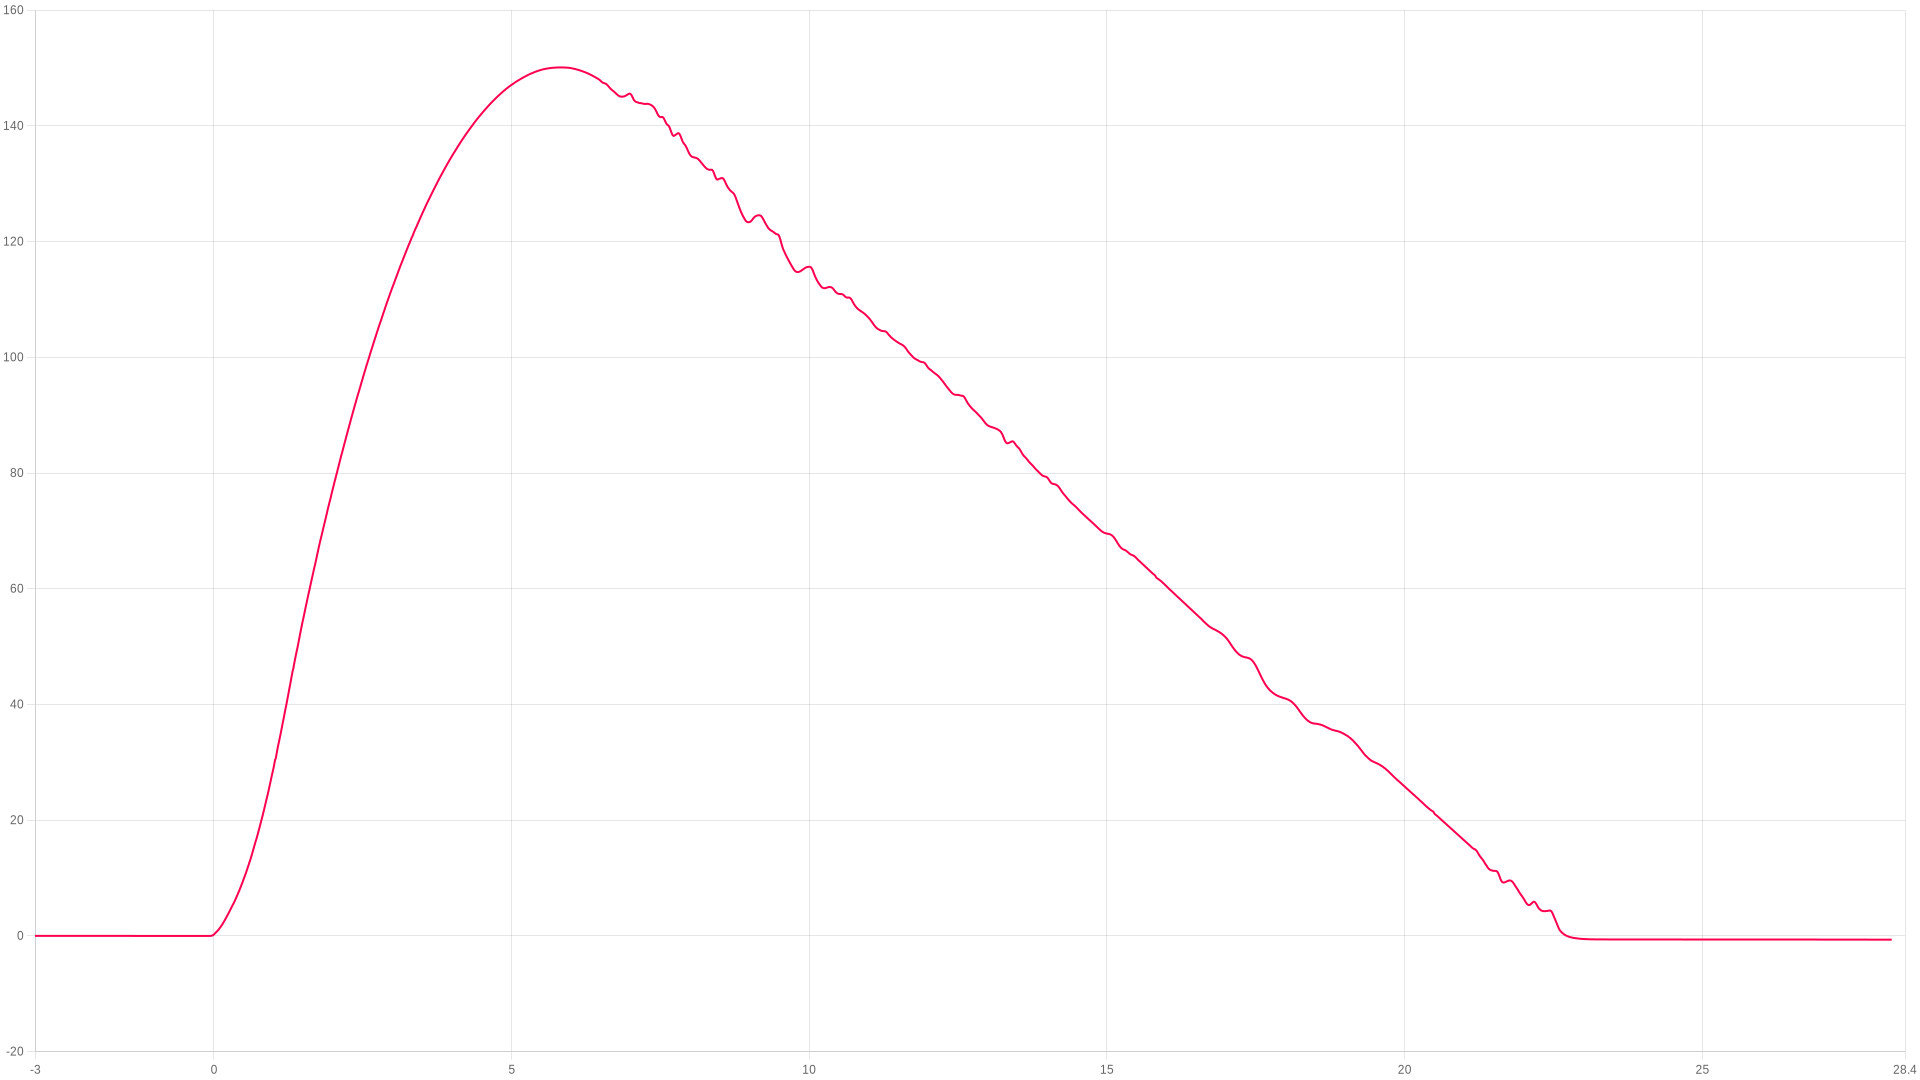
Apogeum
150.1m
5.83 s after launch
Max. stoupání
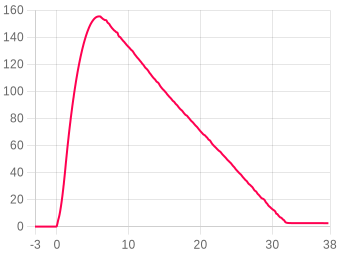
55.3m/s
peak ascent
Max. při spalování
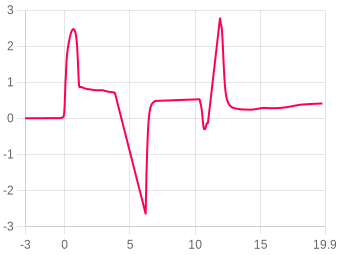
7.39G
during the burn
Přistání
22.54s
touchdown 9.81 m/s
ZOOM TO
s
s
Zobrazit události
Stáhnout
Upravit tepl. & tlak ?
Obrázek
Přiblížení
Klikněte a táhněte nebo použijte gesto
Porovnat let ?
Shrnutí letu

The flight, moment by moment

Liftoff
0 s
Náklon rampy103.01°
Thrust calc pad tilt1.6°
Launch detected
1.026 s
Výška30.12 m
Rychlost46.99 m/s
Vyhoření (první)
1.26 s
Výška42.41 m
Rychlost54.520 m/s
Možné vypuštění
1.699 s
Výška63.99 m
Rychlost45.85 m/s
Apogeum
5.82 s
Výška150.1 Metry
Max. náklon do vyhoření107.94°
Přistání
22.54 s
Výška2.38 m
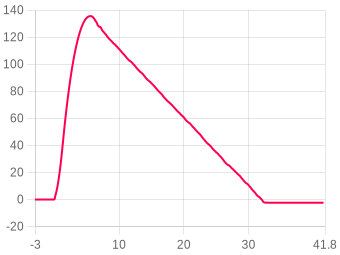
Max. klesání-32.79 m/s

Stabilita68.4%Střední

Náklon při dohoření (20%)95.8
20% · Launch tilt 1.6°
Klápění/zatáčení (30%)16.8
25% · Coning 222.5/32.5°/s
Coning · boost (25%)90.4
25% · Spin 108.2°/s
Přímost tahu (15%)75
30% · Thrust 94.6%

Rocket information

Calculated from the flight data alone
Boost acceleration43.3 m/s²
average over the burn · 4.4 g
Coast deceleration12.0 m/s²
average · gravity plus drag
Ballistic coefficient152 kg/m²
fitted to the 4.56 s coast
Apogee lost to tilt0.05 m
flown vertical ≈ 150.1 m · from the thrust-calculated tilt
Chute opening peak42.61 G
largest deceleration after ejection
Average descent rate2.95 m/s
ejection to landing · 20.84 s
Baterie & teplota 69% → 69% · Teplota začátek 18.92 → 19.07 °C · Start po zapnutí 6m 13s

About the stability score

Worked out from the flight log between liftoff and 80% of apogee. It is independent of the angle the altimeter was mounted at, so it measures the flight rather than the fitting.

Náklon při dohoření (20%)20%How close to vertical it left the rod.
Klápění/zatáčení (30%)25%How much the nose swung off the rocket's own axis across the whole ascent.
Coning · boost (25%)25%The same swing during the burn, when it matters most.
Přímost tahu (15%)30%How cleanly the motor pushed along the body.

Spin about the rocket's own axis is not counted against it — a fast, straight spin is stable. The figures beside the score are the raw measurements behind these four.

Výška
Apogeum150.1 Metry
Čas do apogea5.82 s
Výška vyhoření42.41 m
Výška max. rychlosti43.48 m
Výška vypuštění63.99 m
Výška přistání2.38 m
Výška záznamu37.50 m
Rychlost
Max. stoupání55.3 m/s
Max. klesání-32.79 m/s
Při vyhoření54.520 m/s
Rychl. klesání-8.850 m/s
Rychl. vypuštění45.85 m/s
Rychl. přistání-9.815 m/s
Zrychlení
Max. při spalování7.39 G
Max. stoupání7.39 G
Max. klesání42.61 G
Prúm. stoupání0.4 G
Prúm. spalování4 G
Časy
Vyhoření (první)1.26 s
Apogeum5.82 s
Možné vypuštění1.699 s
Přistání22.54 s
Úhly
Náklon rampy103.01°
Thrust calc pad tilt1.6°
Max. náklon do vyhoření107.94°
Klápění při startu113.36°
Klopní při startu-55.40°
Max. rotace (spal.)497.41 dps
Prúm. rotace (spal.)98.05 dps
Recovery
Single deploy
No dual deploy detected on this flight.
Obecné
Datum nahrání10/06/26-21:24:48
Datové vzorky5356
Celkový čas záznamu39.213 s
Prúm. vzorký/s136.5
Počet blokování0
Start po zapnutí6m 13s
Referenční osaZ
Baterie & teplota
Baterie začátek69%
Baterie konec69%
Teplota začátek18.92°C
Teplota konec19.07°C
Uživatelské poznámky

This second 200Hz Nano test shows the fixed altitude floor and t=0 detection.
We do however run into a new bug with the synchronising of the accelerometerIMU data to the pressure line.
This has always worked before as its look-back of 166 samples was sufficient for 50Hz logs and just scrapes through on 100Hz logs. At 200Hz though it didn't reach the start of the motor burn from launch detection so failed.
This has been fixed with a time-based look-back rather than sample-based and is now operational on the released firmware correctly.

Early and incorrect detection of the ejection was caused by the Nano bouncing around in the rocket as I threw it in loose. We'll add protection against this in the next firmware (1.53) It's the first time we've seen it happen so it's quite rare!
Přidejte toto zařízení ke svému účtu pro úpravy
Youtube video
Žádné video
Přidejte toto zařízení ke svému účtu pro úpravy
Obrázky letu 0
Žádné obrázky
Motory letu
1st stage · 5s delay
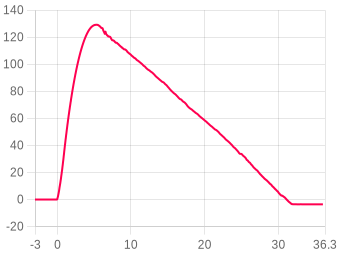
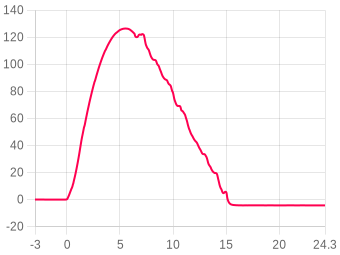
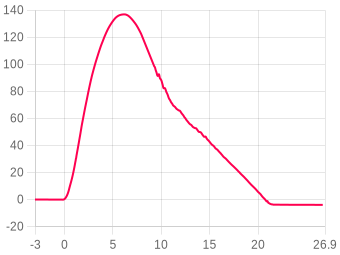
1×C6-5KlimaDetails
Burn time
1.6 s
Diameter
18.00 mm
Average thrust
6 N
Max thrust
15 N
Total weight
20.50 g
Propellant weight
9.60 g
Propellant type
composite
Impulse10Ns
Max thrust15N
Burn time1.6s
Impulse classC
1st stage thrustloading curve…
Motor data by ThrustCurve.org
Přidejte toto zařízení ke svému účtu pro úpravy
Propojená raketa
Active
1 photo
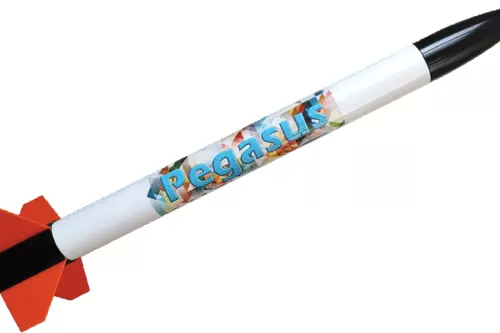
Klima Pegasus - Test Beast
Klima — Pegasus RTF
3 flights linked
Type
Kit build
Diameter
35mm
Length
495mm
Dry weight
80g
Stages
1
Recovery
Parachute
💬 No comments yet
Flight mass
Liftoff mass158.2gestimated
Mass at burnout148.6gestimated
No mass is set for this flight, so Motor thrust (N) uses a mass estimated from the measured burn and the motors’ rated impulse. Set the rocket’s mass for the measured impulse and specific impulse.
Motor thrust (N) is on the chart, under Acceleration.

Linked flights

Connect flights that belong together: a second altimeter flown in the same rocket, or the same rocket flown again. Linked flights appear on each other’s pages.

No linked flights yet.

Místo startu, datum a čas

Klikněte na mapu pro označení místa startu. Přepínejte mezi mapou a satelitním pohledem.

Imagery © Esri, Maxar, Earthstar Geographics

Klikněte na mapu · Přetáhněte pro úpravu

Canopy height from the Meta and WRI High Resolution Canopy Height Maps v2 (Meta and World Resources Institute, 2026; source imagery © 2016 Vantor), used under CC BY 4.0. Ground elevation built from Terrain Tiles (Mapzen and AWS Open Data), derived from 3DEP and GMTED courtesy of the U.S. Geological Survey, SRTM courtesy of NASA, and ETOPO1 courtesy of NOAA. Map and imagery credited on the view above.

Site nameUnnamed siteLat54.375679Lng-2.992388Ground level68.4 m · 224 ftDatum startu2026-06-10Čas startu21:30
Animace dat letu

FLIGHT 1734

150.1 Meters

ALTITUDE
0.00m
VELOCITY
0.00m/s
ACCEL
0.00G
TILT
0.00°
PITCH
0.00°
ROLL
0.00°
YAW
0.00°
TIME
0.00s
AWAITING LAUNCH
ALT
altimetercloud.com
LAUNCH T+0.00s LANDING

BURNOUT

Motor burn complete

Poznámka: Animace letu vyžaduje montáž výškoměru v pevné orientaci. Kalibrujte senzory pro nejlepší výsledky.
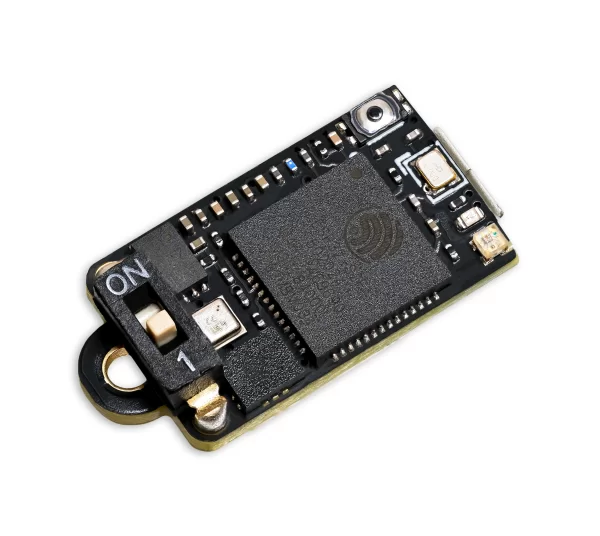
Nano V1
Revision 4
Nano V1
Tento let byl proveden na Nano V1.
The hardware
Verze hardwareRev 4
Verze software1.52
Naposledy online10/06/26-21:24:48
Snímač tlakuBosch BMP 581
Akcelerometr32G 3-axis
Gyroskop2000 dgps 3-axis

Flights from this altimeter

6 of 6
Settings, as they were for this flight

Obecná nastavení letu
Předpovězený tlak
i
Set this to your local forecast pressure at sea level. This will offer you slightly improved accuracty for your flight, although it's not 100% essential every little helps!

Xcweather.co.uk is a decent place to grab pressures from for your location and time.
1013.2 mbar
Detekce startu
i
This is the altitude above the launch pad altitude where the altimeter will trigger itself into recording / flight mode.

The altimeter keeps a constant average of the pressure while waiting for launch, it uses a simple algorithm and the pre-flight buffers to do this. The most recent 120 samples (~4 seconds) are ignored so your pre-trigger altitude won't effect the ground baseline.

For almost all uses we suggest keeping this on the 25 Meter (~82 feet) default settings. If you want to test your altimeter by throwing it in the air, or are planning a very low flight you may want to lower the setting.
30 meters
Sample ratio
i
The altimeter runs at 50Hz however you can record every sample or every X samples in order to extend the log time. For example if you set the ratio to 1 it will save 1:1 samples, or if you set it to 3 it will save 1 in 3 samples.
1:1:1 (200Hz)
Max samples
i
This is the maximum samples the altimeter will log per flight. When it reaches this amount it will stop and save the recording.
24000
Recording stop
i
This setting is how the altimeter decides to stop recording. You can choose either 450 (~9s) or 900 (~18s) samples stable or it will record until the max samples limit unless you press the BUTTON in Manual stop mode.

The samples stable method waits for the devices altitude not to change for the set number of samples. This is defined by not changing by more than +/- 1.0 meters for 98% of the samples, it's a reliable method to stop the recording after landing within 8-10 seconds (300 sample) or 16-20 seconds (600 sample).
Auto: 8s stable altitude
Oversampling
i
Oversampling is a internal setting of the BMP 390 pressure sensor. It is how many samples are taken for each reading. By taking multiple samples for each pressure reading the altimeter reduces noise and increases the resolution of the output.

The sensor can run at 50 samples per second in 4X mode, so we suggest leaving it in this mode as it will offer the highest accuracy.
16x Oversampling
IIR filter
i
The IIR filter is another internal sensor for the BMP390 pressure sensor. It is a Infinite impulse response filter used to enhance pressure measurement accuracy by reducing noise. It's primarily for smoothing out rapid pressure changes.

We suggest not setting this too high as it will cause delay to changes in altitude if set very high.
COEFF 7
Pressure filter
i
This filter is a software Kalman filter that runs on the altimeters processor.

The Kalman filter uses a prediction step based on a system model and then a correction step using new measurements to refine its estimate, it creates accurate most certain results from data with noise in it.
TruePath
Sample speed
i
The sample rate of the altimeter's sensors. 50Hz takes 50 samples per second, 100Hz takes 100 samples per second for higher resolution data.
200 Hz
Hybrid mode
i
When enabled, the altimeter records at full speed during ascent then switches to half speed after apogee to extend recording time during descent.
Enabled
Sync sensors
i
The filters on the pressure sensor can cause it to lag very slightly behind the Accelerometer and Gyroscope data. The Sync sensors option detects how far out of sync these sensors are. It then corrects the Acceleration and Gyroscope readings to match the pressure sensor.
AKTIVOVÁNO
Orientation
i
This is the orientation you intend to install the Altimeter in your rocket. It's needed to ensure completly accurate angles and orientation charts and reports. Check out the Manual for more information on this.
Down (text up)
IMU filter
i
The IMU filter, or fusion filter takes the data from each axis of the Gyroscope and Accelerometer to calculate the Pitch, Roll, Yaw and tilt angle from vertical. These filters can build up some discrepency over time so it's important to calibrate your sensors to minimise this.
Madgwick 6-Axis
Launch ALP
i
This is prevention against accidental launch detection.

With this disabled the launch is based only on pressure and something that creates a low pressure can trigger the flight by accident. For example pulling your nose cone off can even trigger it.

With this enabled the rocket also needs to have seen 8 samples (0.25 seconds) of acceleration above this setting in the last 3 seconds as well as the pressure drop to trigger. There is a backup trigger of 1.05 seconds of altitude being above the launch detect setting too.

There are very few situations where this option would cause issues, so we suggest leaving it on.
1.5G
Launch lock
i
When enabled, the altimeter locks out recording for a set period after power on to prevent false triggering during setup.
DISABLED
Static temperature
i
A fixed temperature value used for altitude calculation when the external temperature sensor is disabled or not connected.
15 °C
Kalibrace senzorú
Kalibrační offsety použité pro tento let.
Gyroskop
X2.000°
Y0.000°
Z0.000°
Akcelerometr⚠ Akcelerometr nebyl zkalibrován
X0.000 mG
Y0.000 mG
Z0.000 mG

Files

Where the altimeter signs its log, the file carries that signature and a tick beside it. A tick means the data is unchanged since the device wrote it, which is what a record claim needs.
CSV
1734.csv ✓ SIGNED
The log as columns of text. Opens in a spreadsheet, and in every simulator that reads flight data.
408 KB
WX
1734_weather.json.gz
The weather for 48 hours either side of the launch, within 15 km of the launch site: NOAA GFS every hour, at the surface and up to about 31 km, and the NOAA GEFS ensemble where this site holds it. JSON, gzip compressed. Weather data by Open-Meteo.com (CC BY 4.0) and NOAA. For 2026-06-10 21:30 local time at 54.3757, -2.9924.
211 KB
Adjusted CSV2904 recalculated in your browser
The log recomputed for your own sea-level pressure and temperature. Columns: time, altitude as recorded and adjusted, raw altitude as recorded and adjusted, pressure.

This file is built here from the signed log, so it carries no signature of its own. Anyone verifying a claim should be sent to the flight page and build their own from the original.

Custom CSVbuilt in your browser
Pick any of the chart’s data sets, the worked-out ones included, and the part of the flight to cover. Values come in the units the chart is set to.
In the file
Time span

One row for every time any chosen data set has a sample. A data set with no sample at that time is left blank rather than filled in. Built from the chart’s data, so it carries no signature.

Let
Komentáře
Přihlásit se pro komentování.