Distance
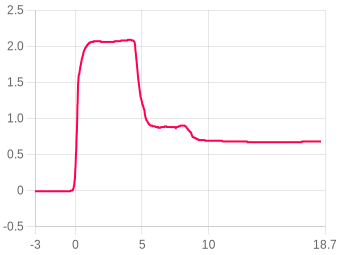
You can choose which units to use for distance from Meters(m), Feet(ft), Miles(mi) & Kilometers(km)
Velocity
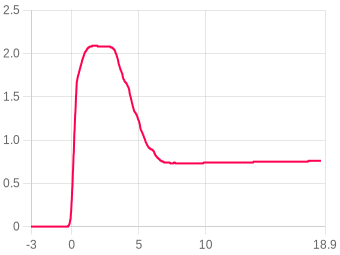
You can pick which units to use for Velocity/speed such as Meters per second (m/s), Feet per second (ft/s), Miles per hour (mph) and Kilometers per hour (kph)
Acceleration
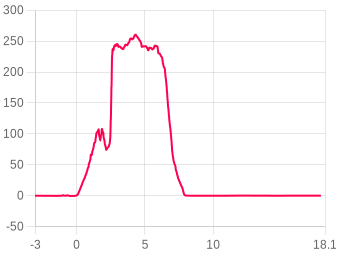
You can choose acceleration units to display from either Meters per second squared (m/s^2) or Gravity (G)
Flight 3042

Flight 3042

Edit title
firmware 1.0
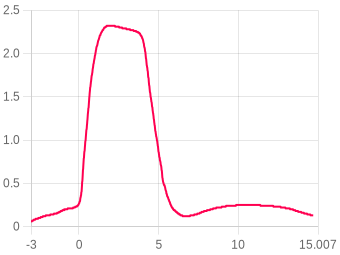
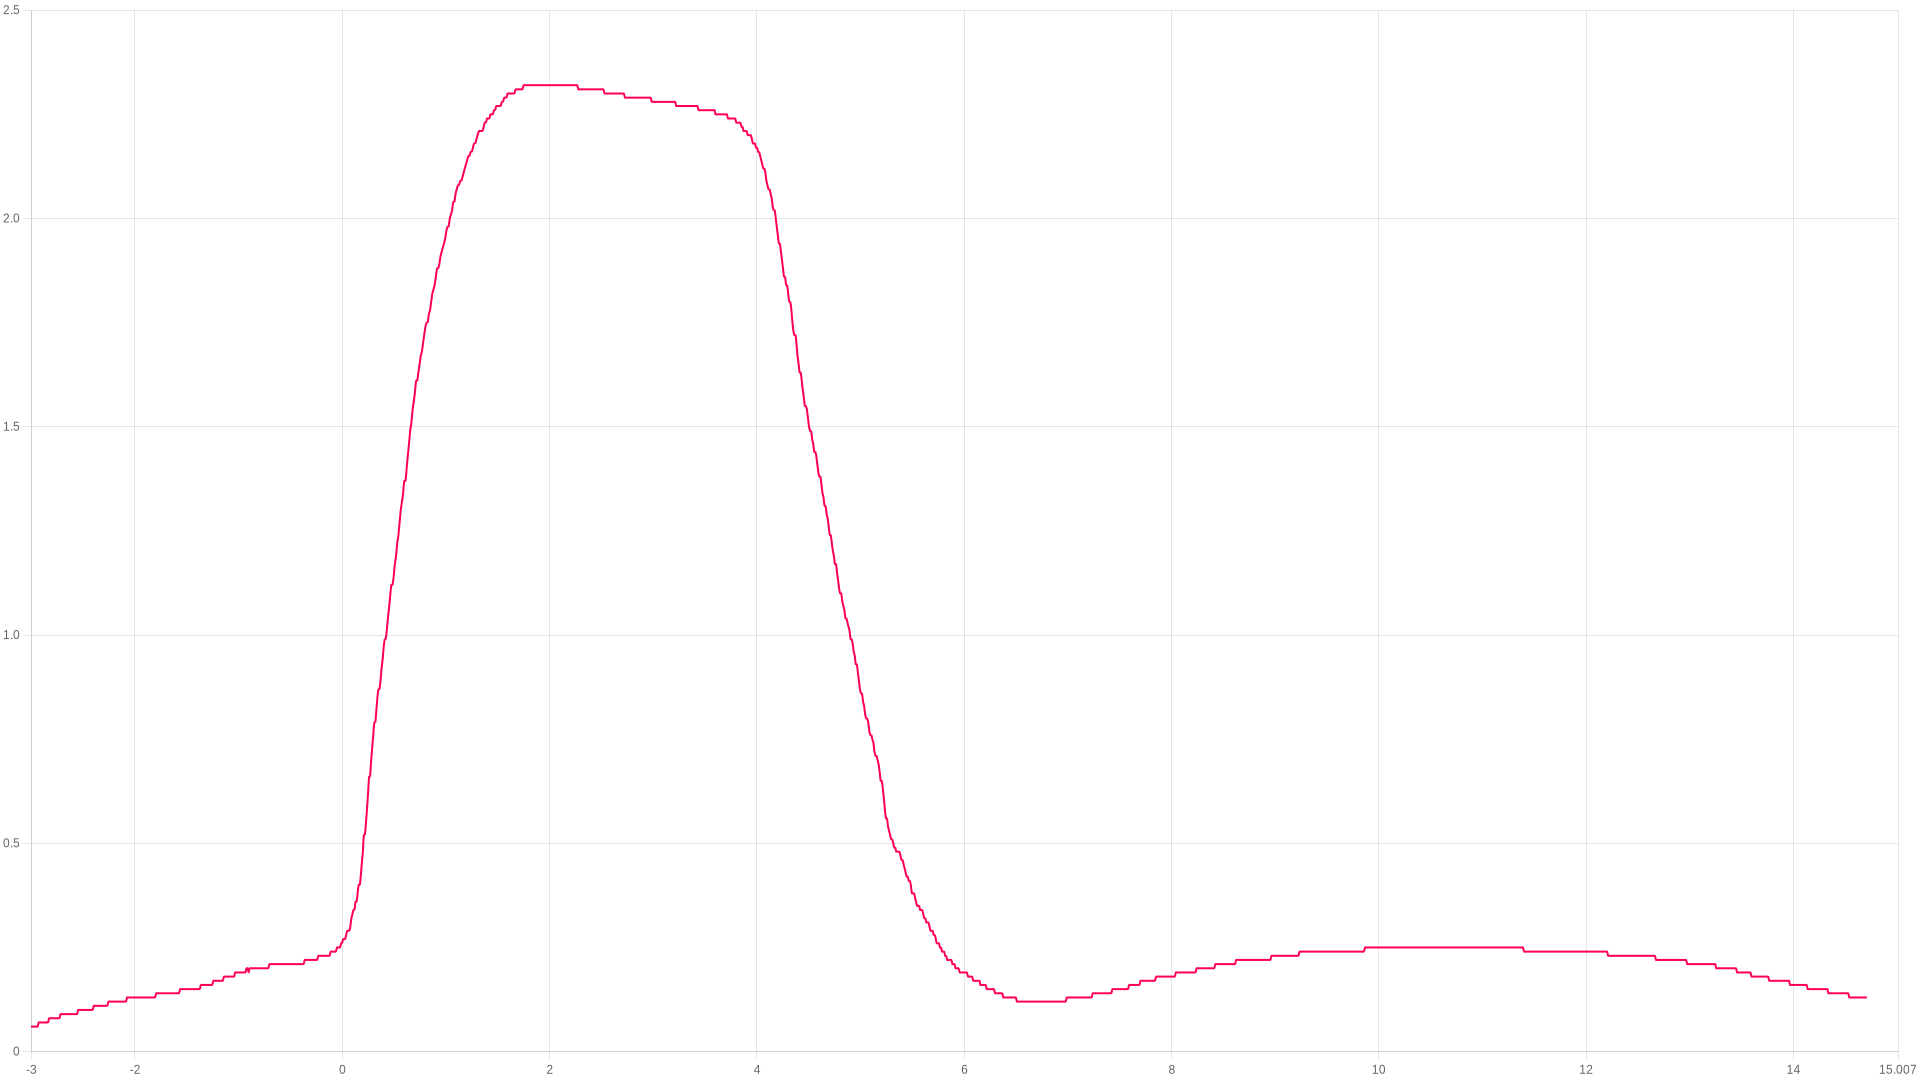
Apogee
2.29m
2.95 s after launch
Max ascent
2.46m/s
peak ascent
Max during burn
0G
during the burn
Landing
0s
touchdown 0 m/s
ZOOM TO
s
s

Save a zoom

Saves the current zoom as a zoom of interest, so anyone reading this flight can see what you want to show them by clicking a button under the chart.

Not the zoom you wanted? Close this, set the chart up as you like it, then save again.

0 of 6 saved
Show events
Adjust temp & pressure ?
Image
Zooming
Drag to zoom, pinch on mobile
Compare flight ?
Custom labels ?
Add custom labels ▾
Flight summary

The flight, moment by moment

Liftoff
0 s
Launch pad tilt0.00°
Thrust calc pad tilt0°
Landing
0 s
Altitude0.26 m
Max descent-1.57 m/s
Apogee
2.95 s
Altitude2.29 Meters
Max tilt to burnout0.00°
Burnout (first)
3.44 s
Altitude2.25 m
Velocity2.46396328993965 m/s

Stability0%Poor

Launch straightness (20%)0
20% · Launch tilt 0°
Coning · full (25%)0
25% · Coning 0/0°/s
Coning · boost (25%)0
25% · Spin 0°/s
Thrust straightness (30%)0
30% · Thrust 0%
Battery & temperature 0% → 0% · Temperature start 0 → 0 °C · Launch after startup 0s

About the stability score

Worked out from the flight log between liftoff and 80% of apogee. It is independent of the angle the altimeter was mounted at, so it measures the flight rather than the fitting.

Launch straightness (20%)20%How close to vertical it left the rod.
Coning · full (25%)25%How much the nose swung off the rocket's own axis across the whole ascent.
Coning · boost (25%)25%The same swing during the burn, when it matters most.
Thrust straightness (30%)30%How cleanly the motor pushed along the body.

Spin about the rocket's own axis is not counted against it — a fast, straight spin is stable. The figures beside the score are the raw measurements behind these four.

Altitude
Apogee2.29 Meters
Time to apogee2.95 s
Burnout altitude2.25 m
Max velocity altitude0.68 m
Ejection altitude0.26 m
Landing altitude0.26 m
Recording altitude m
Velocity
Max ascent2.46 m/s
Max descent-1.57 m/s
At burnout2.46396328993965 m/s
Descent velocity0.000 m/s
Ejection velocity0.440 m/s
Landing velocity0.000 m/s
Acceleration
Max during burn0 G
Max ascent0 G
Max descent0 G
Average ascent0 G
Average burn0 G
Times
Burnout (first)3.44 s
Apogee2.95 s
Possible ejection0 s
Landing0 s
Angles
Launch pad tilt0.00°
Thrust calc pad tilt0°
Max tilt to burnout0.00°
Launch roll0.00°
Launch pitch0.00°
Max spin (burn)0 dps
Avg spin (burn)0 dps
Recovery
Single deploy
No dual deploy detected on this flight.
General
Upload date09-Oct at 05:24
Data samples69200
Total recording time35 s
Average samples/s1991 of 2000 set
Number of lockouts0
Launch after startup0s
Reference axis
Battery & temperature
Battery start0%
Battery end0%
Temperature start0°C
Temperature end0°C
⚠ Low power — charge before next flight
User notes
No notes added

Your notes for this flight

⚠These notes are public. Anyone who opens this flight can read them, including people you share the link with and anyone who finds it through search.
Bold, headings, lists and links are kept. Anything else is removed when saved.
Youtube video
No video added
Flight images 0
No images added
Flight motors
No motors have been added to this flight
Add a motor
Linked rocket
🚀
Link a rocket to this flight

Linked flights

Connect flights that belong together: a second altimeter flown in the same rocket, or the same rocket flown again. Linked flights appear on each other’s pages.

No linked flights yet. Pick one of your flights below to link it.

Launch site, date & time

Click anywhere on the map to mark your launch site. Switch between map and satellite view using the buttons below.

Imagery © Esri, Maxar, Earthstar Geographics

Click the map to place a marker · Drag to adjust

Canopy height: Version 2 High Resolution Canopy Height Maps by WRI and Meta was accessed in September 2026 from https://registry.opendata.aws/dataforgood-fb-forestsv2. Meta and World Resources Institute (WRI) - 2026. Version 2 High Resolution Canopy Height Maps (CHMv2). Source imagery for CHM © 2016 Vantor, licensed under CC BY 4.0. Where that is not yet in the database: ETH Global Canopy Height 2020, CC BY 4.0, from Lang, N., Jetz, W., Schindler, K. and Wegner, J. D. (2023), A high-resolution canopy height model of the Earth, Nature Ecology & Evolution. Both reduced to height bands by Altimeter Cloud. Ground height: Terrain Tiles (Mapzen / Tilezen, on AWS Open Data), reduced into resolution tiers by Altimeter Cloud: ArcticDEM terrain data DEM(s) were created from DigitalGlobe, Inc., imagery and funded under National Science Foundation awards 1043681, 1559691, and 1542736; Australia terrain data © Commonwealth of Australia (Geoscience Australia) 2017; Austria terrain data © offene Daten Österreichs – Digitales Geländemodell (DGM) Österreich; Canada terrain data contains information licensed under the Open Government Licence – Canada; Europe terrain data produced using Copernicus data and information funded by the European Union - EU-DEM layers; Global ETOPO1 terrain data U.S. National Oceanic and Atmospheric Administration; Mexico terrain data source: INEGI, Continental relief, 2016; New Zealand terrain data Copyright 2011 Crown copyright (c) Land Information New Zealand and the New Zealand Government (All rights reserved); Norway terrain data © Kartverket; United Kingdom terrain data © Environment Agency copyright and/or database right 2015. All rights reserved; United States 3DEP (formerly NED) and global GMTED2010 and SRTM terrain data courtesy of the U.S. Geological Survey. Map and imagery credited on the view above.

Lat— Lng— Ground level—

Ground level is read from our elevation store at the marked point, the same ground the view above is drawn from.

✓ Launch site saved.
✗ Could not save. Please try again.
Flight data animation

FLIGHT 3042

2.29 Meters

ALTITUDE
0.00m
VELOCITY
0.00m/s
ACCEL
0.00G
TILT
0.00°
PITCH
0.00°
ROLL
0.00°
YAW
0.00°
TIME
0.00s
AWAITING LAUNCH
ALT
altimetercloud.com
LAUNCH T+0.00s LANDING

BURNOUT

Motor burn complete

Note: Flight profile animation requires your altimeter to be mounted in a fixed orientation that you choose in your settings. For best results please calibrate your sensors as well.

Settings, as they were for this flight

Flown settings

Flight detection

Detect and log flights when disarmed
On
Gyroscope range
4000 dps
High-G accelerometer range
256 g
Include magnetometer in fusion
On
Installed orientation
Upright (antenna down)
Launch acceleration gate
2500 mG
Launch detect threshold
1 m
Launch lockout
0 s
Lockout sensitivity
Standard
Maximum record time
99999 s
Maximum samples
50000
Recording stop
Auto landing plus 10 seconds
Sample ratio (coast and idle)
5
Sample ratio (flight and landing)
1
Sync sensors to barometer
On

Apogee prediction

Air gas constant
287.0500 J/kgK
Automatic weather
On
Calculate air density
On
Drag coefficient
0.7500
Fixed ambient temperature
15.0000
Fixed sea-level pressure
1013.2500
Reference area
100.0000 mm2
Rocket mass
300.0000 g

Outputs

OUT1 power-good handling
Ignore
OUT1 resistance high
6.0000 Ω
OUT1 resistance low
0.5000 Ω
OUT2 power-good handling
Ignore
OUT2 resistance high
6.0000 Ω
OUT2 resistance low
0.5000 Ω
OUT3 power-good handling
Ignore
OUT3 resistance high
6.0000 Ω
OUT3 resistance low
0.5000 Ω

Safety & arming

Acceleration magnitude
2500 mG
Arm LED pin
0
Arming lockout after power-on
30 s
Arming mode
0
Arming timeout
60 s
Audio arm pin
11252
Audio arming
On
Block any rule from triggering until thresholds are met
Off
Buzzer options when armed
Every 5 s
Disarm after arming
14400 s
Disarm after landing
60 s
Disarm after launch
14400 s
Disarm after recording ends
60 s
Duration threshold
200 ms
Enable automatic arming
On
Expansion high-current output modules
On
Expansion ports used as GPIO outputs
Off
Expansion ports used as servo signals
Off
Expansion servo controllers
Off
External switch port purpose
Disabled
GPIO arm pin
0
GPIO pin arming
Off
GPIO port ARM state
3V3 = ARMED / GND = DISARMED
Hold to arm / disarm
5 s
Magnet arming (BMM350)
On
Magnet sensitivity
Normal
Minimum altitude above pad
100 m
Minimum time after launch
2 s
Minimum time since power-on
30 s
Require arming to test-fire outputs
On
Require launch detect before outputs
On
Seen within the last
60 s

Air brake

Air brake
Off
Air brake angle after burnout
-1
Air brake apogee angle
-1
Air brake at apogee
Hold position
Air brake prediction cushion
5.0000
Air brake response
1
Air brake servo channel
0
Air brake start braking at
1
Air brake target apogee
300.0000

Power

Battery type
0
Buck-boost mode
Low noise in flight, efficient on the pad
Buzzer
On, but silent in flight
Custom cell chemistry
Unspecified (linear)
Custom empty voltage
6600 mV
Custom full voltage
8400 mV
Resistance monitoring
On
Smart power (pad wait)
eMode 1
Super-cap initial output PWM duty
50
Super-cap output PWM frequency
10
Super-cap protection threshold
80

After-landing tracking

After-landing tracking, battery 0-20%
900
After-landing tracking, battery 20-40%
240
After-landing tracking, battery 40-60%
30
After-landing tracking, battery 60-100%
20
Power down modem between pings
Off
Sleep sensors between pings
On
Upload flights automatically
On

SIM & cellular

APN
iot.1nce.net
APN authentication
None
APN password
not set
APN username
not set
Cell rescan interval
10 min
Cellular region
Global
Data usage alert
On
Device name
Jupiter9506
Flight-log upload pace
400 ms
PDP type
IPv4
Primary network search
0
SIM PIN
not set
SIM type
Built-in 1NCE

General

Failsafe SMS
On
Intercom mode
Master
Rule evaluation order
not set
Time zone offset
0 min

Servos

Servo 1 default angle
90
Servo 1 max angle
180
Servo 1 min angle
0
Servo 10 default angle
90
Servo 10 max angle
180
Servo 10 min angle
0
Servo 11 default angle
90
Servo 11 max angle
180
Servo 11 min angle
0
Servo 12 default angle
90
Servo 12 max angle
180
Servo 12 min angle
0
Servo 13 default angle
90
Servo 13 max angle
180
Servo 13 min angle
0
Servo 14 default angle
90
Servo 14 max angle
180
Servo 14 min angle
0
Servo 15 default angle
90
Servo 15 max angle
180
Servo 15 min angle
0
Servo 16 default angle
90
Servo 16 max angle
180
Servo 16 min angle
0
Servo 2 default angle
90
Servo 2 max angle
180
Servo 2 min angle
0
Servo 3 default angle
90
Servo 3 max angle
180
Servo 3 min angle
0
Servo 4 default angle
90
Servo 4 max angle
180
Servo 4 min angle
0
Servo 5 default angle
90
Servo 5 max angle
180
Servo 5 min angle
0
Servo 6 default angle
90
Servo 6 max angle
180
Servo 6 min angle
0
Servo 7 default angle
90
Servo 7 max angle
180
Servo 7 min angle
0
Servo 8 default angle
90
Servo 8 max angle
180
Servo 8 min angle
0
Servo 9 default angle
90
Servo 9 max angle
180
Servo 9 min angle
0
Servo board CPU frequency
25000000
Servo board external clock
0
Servo board frequency (Hz)
50
Servo board max pulse (us)
2400
Servo board min pulse (us)
600

Expansion ports

EXP1 module type
0
EXP1_A frequency (Hz)
50
EXP1_A max angle
180
EXP1_A max pulse (us)
2000
EXP1_A min angle
0
EXP1_A min pulse (us)
1000
EXP1_A pin mode
0
EXP1_A start angle
90
EXP1_B frequency (Hz)
50
EXP1_B max angle
180
EXP1_B max pulse (us)
2000
EXP1_B min angle
0
EXP1_B min pulse (us)
1000
EXP1_B pin mode
0
EXP1_B start angle
90
EXP2 module type
0
EXP2_A frequency (Hz)
50
EXP2_A max angle
180
EXP2_A max pulse (us)
2000
EXP2_A min angle
0
EXP2_A min pulse (us)
1000
EXP2_A pin mode
0
EXP2_A start angle
90
EXP2_B frequency (Hz)
50
EXP2_B max angle
180
EXP2_B max pulse (us)
2000
EXP2_B min angle
0
EXP2_B min pulse (us)
1000
EXP2_B pin mode
0
EXP2_B start angle
90
EXP3 module type
0
EXP3_A pin mode
0
EXP3_B pin mode
0
EXP4 module type
0
EXP4_A frequency (Hz)
50
EXP4_A max angle
180
EXP4_A max pulse (us)
2000
EXP4_A min angle
0
EXP4_A min pulse (us)
1000
EXP4_A pin mode
0
EXP4_A start angle
90
EXP4_B frequency (Hz)
50
EXP4_B max angle
180
EXP4_B max pulse (us)
2000
EXP4_B min angle
0
EXP4_B min pulse (us)
1000
EXP4_B pin mode
0
EXP4_B start angle
90
Expansion power
Off

Other

Imu Freq
2000
Imu Hg Freq
2000
Lev G1
10
Lev G1 ms
500
Lev G2
30
Lev G2 ms
100
Lev Gyro
2500
Lev Gyro ms
500
Lev Win S
3
Lz1 Imu
2000
Lz1 Mag
100
Lz2 Imu
2000
Lz2 Mag
100
Lz3 Imu
1000
Lz3 Mag
100
Lz4 Imu
2000
Lz4 Mag
100
Lz5 Imu
250
Lz5 Mag
100

Datasets

Dataset 1 expression
not set
Dataset 2 expression
not set
Dataset 3 expression
not set
Dataset 4 expression
not set
Dataset 5 expression
not set
Dataset 6 expression
not set

GNSS

AGNSS cache lifetime
2 days
Enable GNSS seeding
On
GNSS source
Onboard

Logging

Compression effort
5
Maximum logs kept
5
Maximum size per boot
1048576 bytes
Rules
No rules were configured for this flight.

Files

Where the altimeter signs its log, the file carries that signature and a tick beside it. A tick means the data is unchanged since the device wrote it, which is what a record claim needs.
LOG
3042.aclz
The altimeter's own compressed log, exactly as the device wrote it. This is the file to keep for a record claim.
245 KB
Adjusted CSV2904 recalculated in your browser
The log recomputed for your own sea-level pressure and temperature. Columns: time, altitude as recorded and adjusted, raw altitude as recorded and adjusted, pressure.

This file is built here from the signed log, so it carries no signature of its own. Anyone verifying a claim should be sent to the flight page and build their own from the original.

Flight
Comments
Sign in to leave a comment.