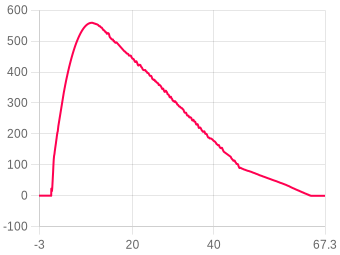
Distance
You can choose which units to use for distance from Meters(m), Feet(ft), Miles(mi) & Kilometers(km)
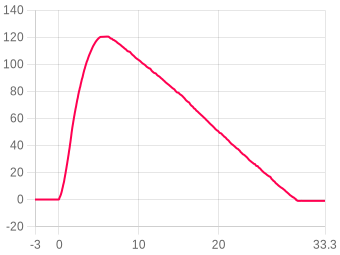
Velocity
You can pick which units to use for Velocity/speed such as Meters per second (m/s), Feet per second (ft/s), Miles per hour (mph) and Kilometers per hour (kph)
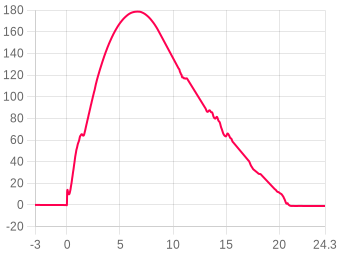
Acceleration
You can choose acceleration units to display from either Meters per second squared (m/s^2) or Gravity (G)

Arreaux Ascender F115

Mercury Plus Rev 0 · firmware 1.00
Apogee
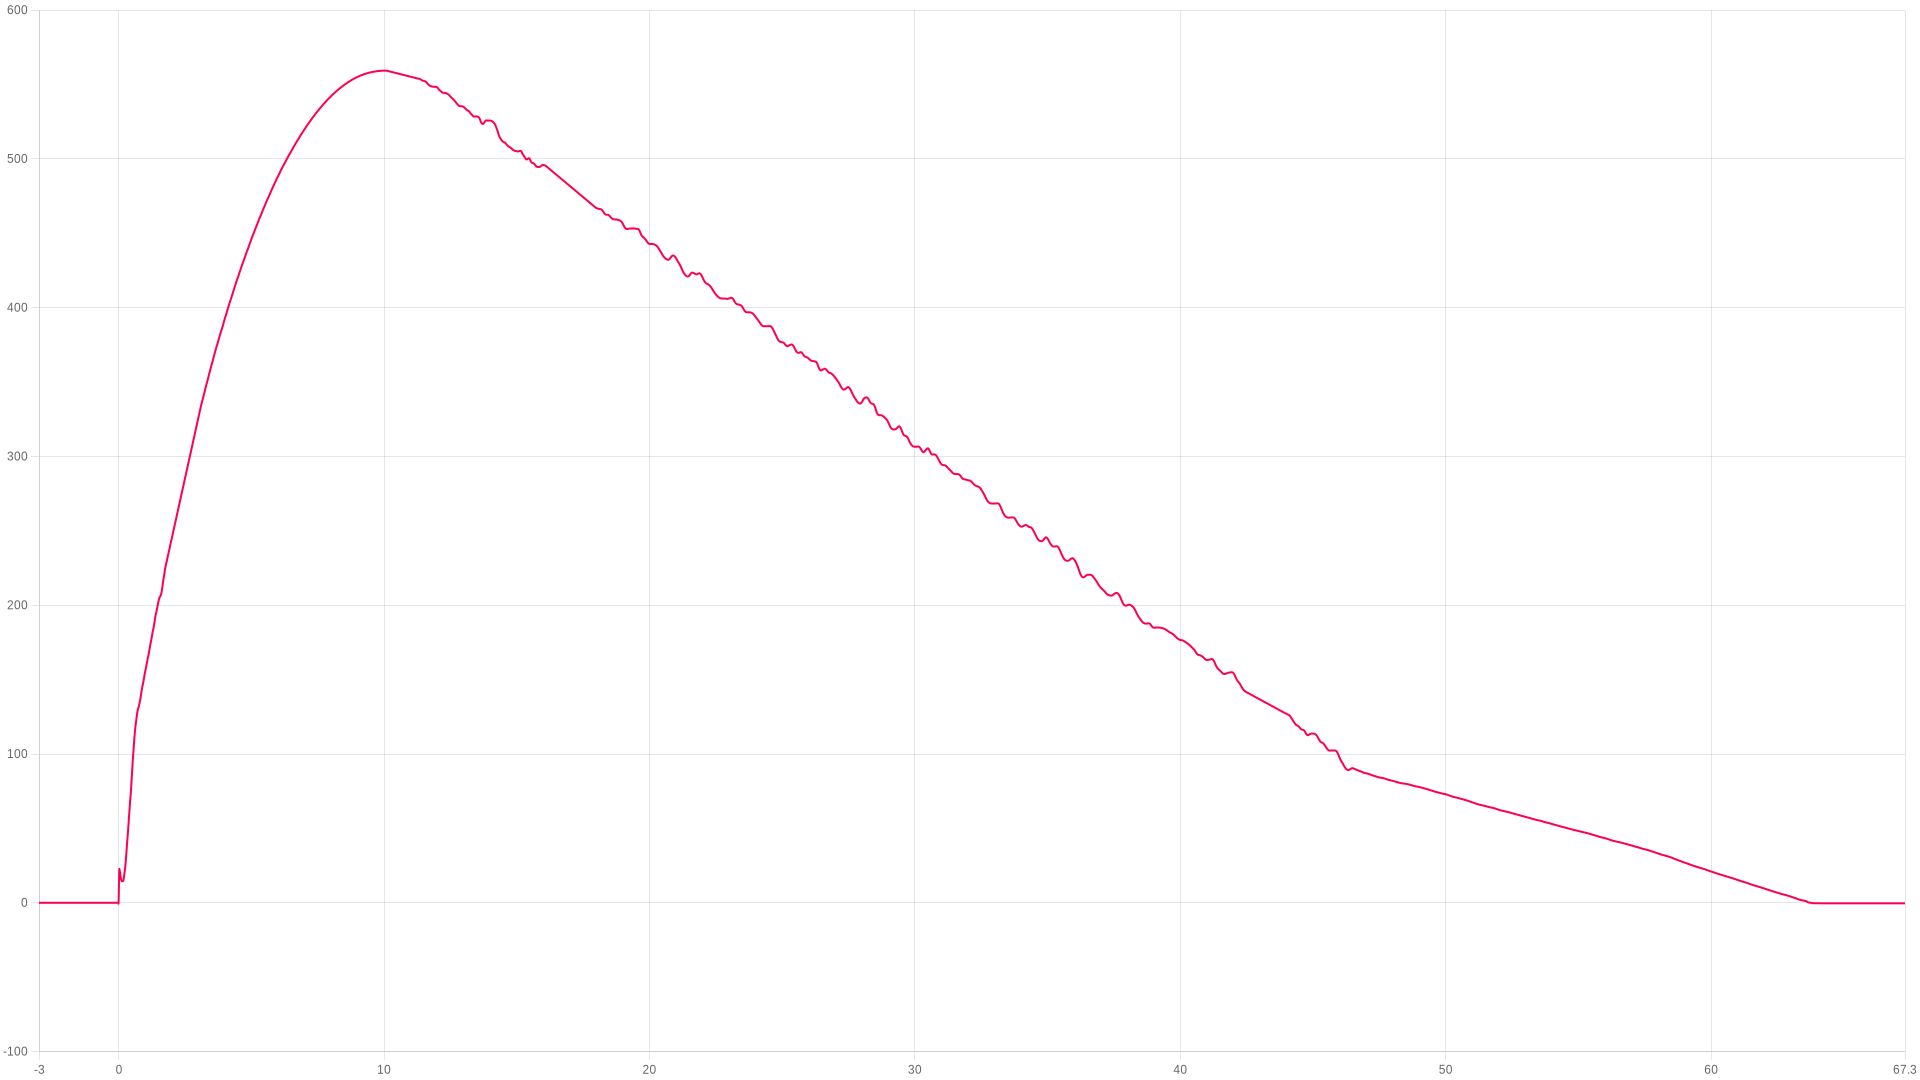
559.36m
10.08 s after launch
Max ascent
261.73m/s
peak ascent
Max during burn
38.5G
during the burn
Landing
63.61s
touchdown 5.63 m/s
ZOOM TO
s
s
Show events
Download
Adjust temp & pressure ?
Image
Zooming
Drag to zoom, pinch on mobile
Compare flight ?
Something look wrong with this flight's data?
Tell us what looks wrong and we'll look into it. It helps us find and fix problems in the firmware and on the site, and we can correct this flight.
You're not logged in, so we can't let you know when we've looked into it.
Flight summary

The flight, moment by moment

Liftoff
0 s
Rail angle2.8°
Orientation4.96°
Launch detected
0.3 s
Altitude35.38 m
Velocity176.31 m/s
Burnout (first)
0.72 s
Altitude130.26 m
Velocity134.520 m/s
Apogee
10.08 s
Altitude559.36 Meters
Max tilt to burnout7.77°
Possible ejection
10.364 s
Altitude558.15 m
Velocity-4.51 m/s
Landing
63.61 s
Altitude0.7 m
Max descent-44.04 m/s

Stability85.6%Excellent

Launch straightness (20%)92.9
20% · Rail angle 2.8°
Coning · full (25%)97.4
25% · Coning 16.1/40.6°/s
Coning · boost (25%)85.8
25% · Spin 252.2°/s
Thrust straightness (30%)70.8
30% · Thrust 93.7%

Rocket information

Calculated from the flight data alone
Boost acceleration186.8 m/s²
average over the burn · 19.1 g
Coast deceleration14.4 m/s²
average · gravity plus drag
Ballistic coefficient328 kg/m²
fitted to the 9.36 s coast
Apogee lost to tilt0.33 m
flown vertical ≈ 559.6 m · from the tilt at burnout
Chute opening peak39.92 G
largest deceleration after ejection
Average descent rate10.46 m/s
ejection to landing · 53.25 s
Battery & temperature 89% → 84% · Temperature start 21.12 → 21.77 °C · Launch after startup 15m 6s

About the stability score

Worked out from the flight log between liftoff and 80% of apogee. It is independent of the angle the altimeter was mounted at, so it measures the flight rather than the fitting.

Launch straightness (20%)20%How close to vertical it left the rod.
Coning · full (25%)25%How much the nose swung off the rocket's own axis across the whole ascent.
Coning · boost (25%)25%The same swing during the burn, when it matters most.
Thrust straightness (30%)30%How cleanly the motor pushed along the body.

Spin about the rocket's own axis is not counted against it — a fast, straight spin is stable. The figures beside the score are the raw measurements behind these four.

Altitude
Apogee559.36 Meters
Time to apogee10.08 s
Burnout altitude130.26 m
Max velocity altitude70.02 m
Ejection altitude558.15 m
Landing altitude0.7 m
Recording altitude131.32 m
Velocity
Max ascent261.73 m/s
Max descent-44.04 m/s
At burnout134.520 m/s
Descent velocity-9.923 m/s
Ejection velocity-4.51 m/s
Landing velocity-5.631 m/s
Acceleration
Max during burn38.5 G
Max ascent38.5 G
Max descent39.92 G
Average ascent1.08 G
Average burn19.36 G
Times
Burnout (first)0.72 s
Apogee10.08 s
Possible ejection10.364 s
Landing63.61 s
Output #1 ON0 s
Output #1 OFF0 s
Angles
Rail angle ?2.8° ± 4.01°
Rail kick ?not measured
Max tilt to burnout ?7.77°
Orientation ?4.96°
Mount offset ?not measured
Launch roll-3.62°
Launch pitch3.39°
Max spin (burn)326.73 dps
Avg spin (burn)82.17 dps
Recovery
Single deploy
No dual deploy detected on this flight.
General
Upload date24-Oct at 23:11
Data samples9232
Total recording time88.800 s
Average samples/s103.9
Number of lockouts1
Launch after startup15m 6s
Reference axisX
Battery & temperature
Battery start89%
Battery end84%
Temperature start21.12°C
Temperature end21.77°C
MT1 launch temp0°C
Something look wrong with this flight's data?
Tell us what looks wrong and we'll look into it. It helps us find and fix problems in the firmware and on the site, and we can correct this flight.
You're not logged in, so we can't let you know when we've looked into it.
User notes
No notes added
Add this device to your account to edit
Youtube video
No video added
Add this device to your account to edit
Flight images 0
No images added
Flown as
Motor configuration
Custom
1× AeroTech F115SN-12A-10, set on this flight
Loaded weight
518.8 g
set on this flight · estimated 533.2 g from the rated impulse

Measured burn

from this flight’s thrust and its loaded weight
Total impulse, NFPA 112576.58 Ns
rated 79.15 Ns, 3.2% under, within the 20% NFPA 1125 allows
Total impulse, absolute76.93 Ns
Measured asF107
sold as a F115SN-12A
Burn time, NFPA 11250.72 s
0.08 to 0.79 s
Average thrust106.7 N
impulse over burn time
Peak thrust200.8 N
at 0.10 s
Specific impulse204 s
38.5 g of propellant
Mass at burnout480.3 g
loaded weight less propellant
NFPA 1125, the code motors are certified to by NAR, Tripoli and CAR: the burn runs from where the thrust first rises above 5% of its peak to where it falls below it (7.8.3), and the total impulse from that rise to the last measurable thrust before ejection (7.8.5). Absolute counts every newton from liftoff. The same code lets a production lot vary 20% from its mean impulse for a model rocket motor and 10% for high power (7.8.6). Both figures follow the loaded weight: 1% out on the weight is about 1% out on the impulse.
Flight motors
1st stage · 10s delay
1×F115SN-12A-10AeroTechDetails
Burn time
0.69 s
Diameter
29.00 mm
Average thrust
114.16 N
Max thrust
146.7 N
Total weight
92.50 g
Propellant weight
38.50 g
Propellant type
Slo Nine
Impulse79.15Ns
Max thrust146.7N
Burn time0.69s
Impulse classF
1st stage thrustloading curve…
Motor data by ThrustCurve.org
Add this device to your account to edit
Linked rocket
🚀
Active
Arreaux Ascender
2 flights linked
Type
Scratch built
Diameter
50.8mm
Length
1041.4mm
Empty weight
15g
Stages
1
Fins
3
Body
Kraft paper
💬 No comments yet
Rule events
No output rules fired during this flight.
Motor match (BETA)
Very much in testing mode! We are working out how to guess which motor a flight flew on.
Brand
Motor
Score
Shape
Burn
AeroTech
F115SN
122
94%
98.3%
AeroTech
H283ST
111
93.2%
94.5%
Cesaroni
H399-WT
109
89.4%
93.2%
Cesaroni
F70-WT
100
92.8%
98.3%
AeroTech
J1799N
95
89.3%
95.1%
AeroTech
D21T
90
90.5%
95.3%
Cesaroni
H340-SS
90
90.6%
95.7%
Cesaroni
H255-WT
84
91.4%
93.6%
AeroTech
I599N
84
84.5%
90.9%
AeroTech
J1299N
84
85.7%
91.3%

Linked flights

Connect flights that belong together: a second altimeter flown in the same rocket, or the same rocket flown again. Linked flights appear on each other’s pages.

No linked flights yet.

Launch site, date & time

Click anywhere on the map to mark your launch site. Switch between map and satellite view using the buttons below.

Imagery © Esri, Maxar, Earthstar Geographics

Click the map to place a marker · Drag to adjust

Canopy height from the Meta and WRI High Resolution Canopy Height Maps v2 (Meta and World Resources Institute, 2026; source imagery © 2016 Vantor), used under CC BY 4.0. Ground elevation built from Terrain Tiles (Mapzen and AWS Open Data), derived from 3DEP and GMTED courtesy of the U.S. Geological Survey, SRTM courtesy of NASA, and ETOPO1 courtesy of NOAA. Map and imagery credited on the view above.

Site nameJMRC 1Lat42.200046Lng-83.965386Ground level292.8 m · 961 ftLaunch date2026-10-24Launch time10:33
Flight data animation

FLIGHT 3161

559.36 Meters

ALTITUDE
0.00m
VELOCITY
0.00m/s
ACCEL
0.00G
TILT
0.00°
PITCH
0.00°
ROLL
0.00°
YAW
0.00°
TIME
0.00s
AWAITING LAUNCH
ALT
altimetercloud.com
LAUNCH T+0.00s LANDING

BURNOUT

Motor burn complete

Note: Flight profile animation requires your altimeter to be mounted in a fixed orientation that you choose in your settings. For best results please calibrate your sensors as well.
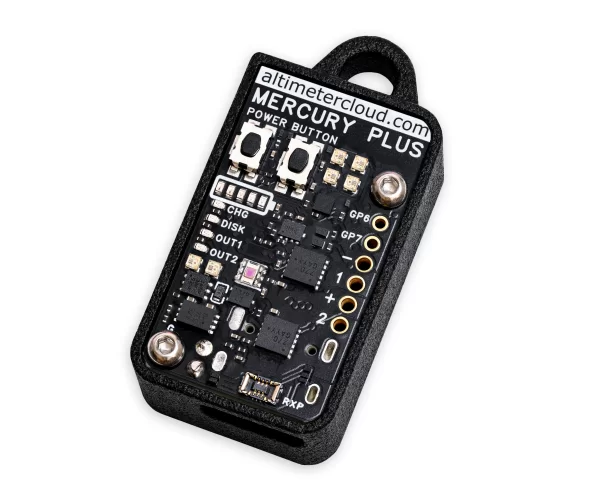
Mercury Plus
Rocketry Ltd

Mercury Plus

256G High-performance WiFi-enabled altimeter. This flight was flown on a Mercury Plus.
Hardware version Rev 0Software version 1.00Last online 08-Nov at 16:36

Specifications

Electronics

Microcontroller
ESP32-C632-bit ESP32-C6 160MHz
Accelerometer
ISM6HG2563-axis 256G (High) & 3-axis 16G (Low)
Barometer
Bosch BMP581300 to 1250 hPa within specification
Gyroscope
ISM6HG2564000 dgps 3-axis
High current outputs
2x 15A high current low resistance high side switches
Servo support
Yes: 2 Directly or 16 via the I2C expansion port

Logging

Maximum sample rate
433 Hz
Most samples in a log
30,000
Longest log
50 minAt 10Hz although default settings are 433Hz with 1:8 hybrid mode

Size, weight and battery

Size
30 x 16.9 x 10.8mm
Weight
4.6 g4.6 g with the smallest battery
Battery voltage
3 to 4.2 V
Battery life
6on the smallest battery

Documents

Settings, as they were for this flight

General flight settings
Forecast pressure
i
Set this to your local forecast pressure at sea level. This will offer you slightly improved accuracty for your flight, although it's not 100% essential every little helps!

Xcweather.co.uk is a decent place to grab pressures from for your location and time.
1013.2 mbar
Launch detect
i
This is the altitude above the launch pad altitude where the altimeter will trigger itself into recording / flight mode.

The altimeter keeps a constant average of the pressure while waiting for launch, it uses a simple algorithm and the pre-flight buffers to do this. The most recent 120 samples (~4 seconds) are ignored so your pre-trigger altitude won't effect the ground baseline.

For almost all uses we suggest keeping this on the 25 Meter (~82 feet) default settings. If you want to test your altimeter by throwing it in the air, or are planning a very low flight you may want to lower the setting.
35 meters
Sample rate
i
The base sample rate of the altimeter's sensors in samples per second. This setting was deprecated in firmware 2.0+.
32 Hz
Sample ratio
i
The altimeter runs at 50Hz however you can record every sample or every X samples in order to extend the log time. For example if you set the ratio to 1 it will save 1:1 samples, or if you set it to 3 it will save 1 in 3 samples.
1:5 (hybrid, reduces after apogee)
Max samples
i
This is the maximum samples the altimeter will log per flight. When it reaches this amount it will stop and save the recording.
18000
Recording stop
i
This setting is how the altimeter decides to stop recording. You can choose either 450 (~9s) or 900 (~18s) samples stable or it will record until the max samples limit unless you press the BUTTON in Manual stop mode.

The samples stable method waits for the devices altitude not to change for the set number of samples. This is defined by not changing by more than +/- 1.0 meters for 98% of the samples, it's a reliable method to stop the recording after landing within 8-10 seconds (300 sample) or 16-20 seconds (600 sample).
Auto: 450 samples stable (~9s)
Oversampling
i
Oversampling is a internal setting of the BMP 390 pressure sensor. It is how many samples are taken for each reading. By taking multiple samples for each pressure reading the altimeter reduces noise and increases the resolution of the output.

The sensor can run at 50 samples per second in 4X mode, so we suggest leaving it in this mode as it will offer the highest accuracy.
16x Oversampling
IIR filter
i
The IIR filter is another internal sensor for the BMP390 pressure sensor. It is a Infinite impulse response filter used to enhance pressure measurement accuracy by reducing noise. It's primarily for smoothing out rapid pressure changes.

We suggest not setting this too high as it will cause delay to changes in altitude if set very high.
COEFF 7
Pressure filter
i
This filter is a software Kalman filter that runs on the altimeters processor.

The Kalman filter uses a prediction step based on a system model and then a correction step using new measurements to refine its estimate, it creates accurate most certain results from data with noise in it.
Kalman 2 (default)
Lockout change
i
This is how we detect a lockout. If the pressure changes by this much in a single sample downwards (pressure increase, lower altitude) then it's likely to be a false reading. Multiply the setting by 32 to get the speed in meters per second that it will trigger at.
0.5 meters
Sync sensors
i
The filters on the pressure sensor can cause it to lag very slightly behind the Accelerometer and Gyroscope data. The Sync sensors option detects how far out of sync these sensors are. It then corrects the Acceleration and Gyroscope readings to match the pressure sensor.
ENABLED (5 samples / 38.00ms)
Orientation
i
This is the orientation you intend to install the Altimeter in your rocket. It's needed to ensure completly accurate angles and orientation charts and reports. Check out the Manual for more information on this.
Upwards (text up)
IMU filter
i
The IMU filter, or fusion filter takes the data from each axis of the Gyroscope and Accelerometer to calculate the Pitch, Roll, Yaw and tilt angle from vertical. These filters can build up some discrepency over time so it's important to calibrate your sensors to minimise this.
Madgwick 6-Axis
Launch ALP
i
This is prevention against accidental launch detection.

With this disabled the launch is based only on pressure and something that creates a low pressure can trigger the flight by accident. For example pulling your nose cone off can even trigger it.

With this enabled the rocket also needs to have seen 8 samples (0.25 seconds) of acceleration above this setting in the last 3 seconds as well as the pressure drop to trigger. There is a backup trigger of 1.05 seconds of altitude being above the launch detect setting too.

There are very few situations where this option would cause issues, so we suggest leaving it on.
1.4G
Launch lock
i
When enabled, the altimeter locks out recording for a set period after power on to prevent false triggering during setup.
DISABLED
Static temperature
i
A fixed temperature value used for altitude calculation when the external temperature sensor is disabled or not connected.
15 °C
Temp sensor
i
If an external MT1 temperature sensor is connected, this controls whether it is used for logging only or also for altitude calculations.
DISABLED
Output settings
Arm switch
i
When enabled, GP6 is a hardware arm switch — outputs and rules are held off until the switch is closed to ground.
DISABLED
Startup lockout
i
Outputs and rules are blocked for this many seconds after power-on while sensors settle. 0 = off.
None
Launch confirm delay
i
After launch is detected, outputs and rules won't fire until this many seconds have passed.
2 s
Altitude floor
i
Outputs and rules are blocked until the rocket is at least this height above the launch pad.
50 m
Custom dataset 1
i
User-defined expression evaluated per sample, available for charting.
—
Custom dataset 2
—
Sensor calibration
Calibration offsets used during this flight.
Gyroscope⚠ Gyroscope has not been calibrated
X0.000°
Y0.000°
Z0.000°
Accelerometer⚠ Accelerometer has not been calibrated
X0.000 mG
Y0.000 mG
Z0.000 mG
Device settings
Device TAG
i
A custom name or tag assigned to this device for easy identification.
Merc3532
Language
i
The language setting configured on the device.
🇬🇧 English
Shutdown mode
i
Controls what happens after recording. Standard shuts down normally, Delayed keeps WiFi on for 30 seconds after landing, Stay on keeps the device powered on.
Delayed 30s
LED brightness
i
The brightness level of the LED indicators on the Mercury. Lower values save battery.
20%
WiFi TX power
i
WiFi transmit power level. Higher gives better range but uses more battery.
2 dBm (low)
Sleep mode
i
Controls whether the device enters low-power sleep when idle.
Normal (sleep when idle)
Battery monitor
i
Monitors battery voltage during the flight.
DISABLED
Cloud group
i
The cloud group / category this flight is assigned to.
General use
GP6 / GP7 ports
GP port control was not available until firmware 2.0
I2C PCA9685 Servo Board
GP port control was not available until firmware 2.0
Prediction and air brakes
This feature was not available until version 2.10+

Files

Where the altimeter signs its log, the file carries that signature and a tick beside it. A tick means the data is unchanged since the device wrote it, which is what a record claim needs.
CSV
3161.csv
The log as columns of text. Opens in a spreadsheet, and in every simulator that reads flight data.
773 KB
WX
3161_weather.json.gz
The weather for 48 hours either side of the launch, within 15 km of the launch site: NOAA GFS every hour, at the surface and up to about 31 km, and the NOAA GEFS ensemble where this site holds it. JSON, gzip compressed. Weather data by Open-Meteo.com (CC BY 4.0) and NOAA. For 2026-10-24 11:00 local time at 42.2000, -83.9654.
1043 KB
Adjusted CSV2904 recalculated in your browser
The log recomputed for your own sea-level pressure and temperature. Columns: time, altitude as recorded and adjusted, raw altitude as recorded and adjusted, pressure.

This file is built here from the signed log, so it carries no signature of its own. Anyone verifying a claim should be sent to the flight page and build their own from the original.

Custom CSVbuilt in your browser
Pick any of the chart’s data sets, the worked-out ones included, and the part of the flight to cover. Values come in the units the chart is set to.
In the file
Time span

One row for every time any chosen data set has a sample. A data set with no sample at that time is left blank rather than filled in. Built from the chart’s data, so it carries no signature.

Sign in to leave a comment.