News, guides & articles
 Programming & Electronics ramblings
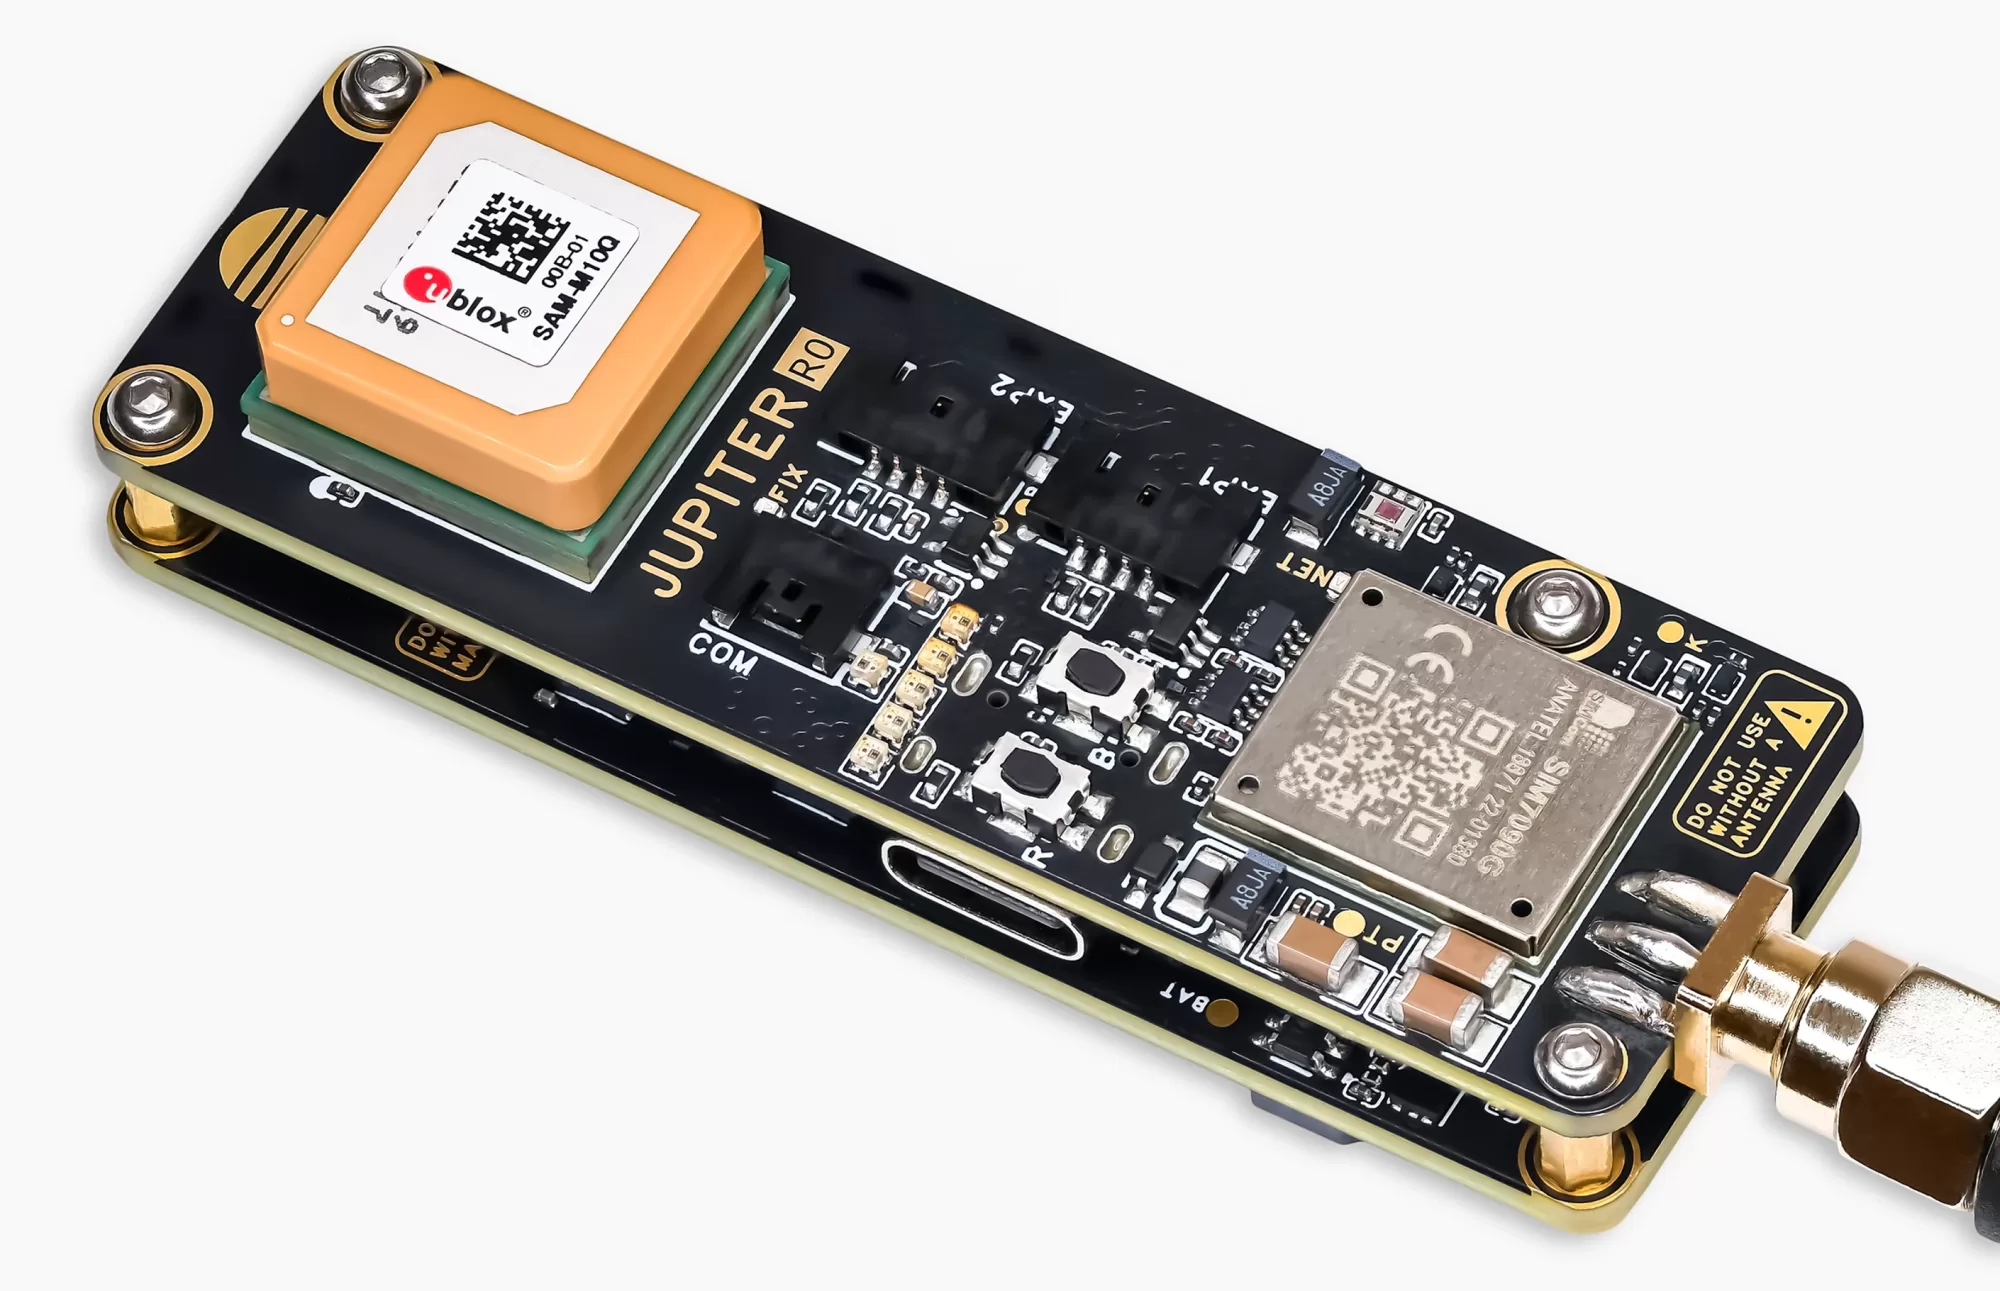
The u-blox SAM-M10Q in flight: settings, seeding and ground plane
A full walkthrough of GNSS on Jupiter: what the ground plane actually needs, which UBX settings matter and which to leave alone, how we build AssistNow-equivalent orbit data from public ephemeris and get it onto the device over LTE-M, and how we inject and seed it. With Arduino…
Read more →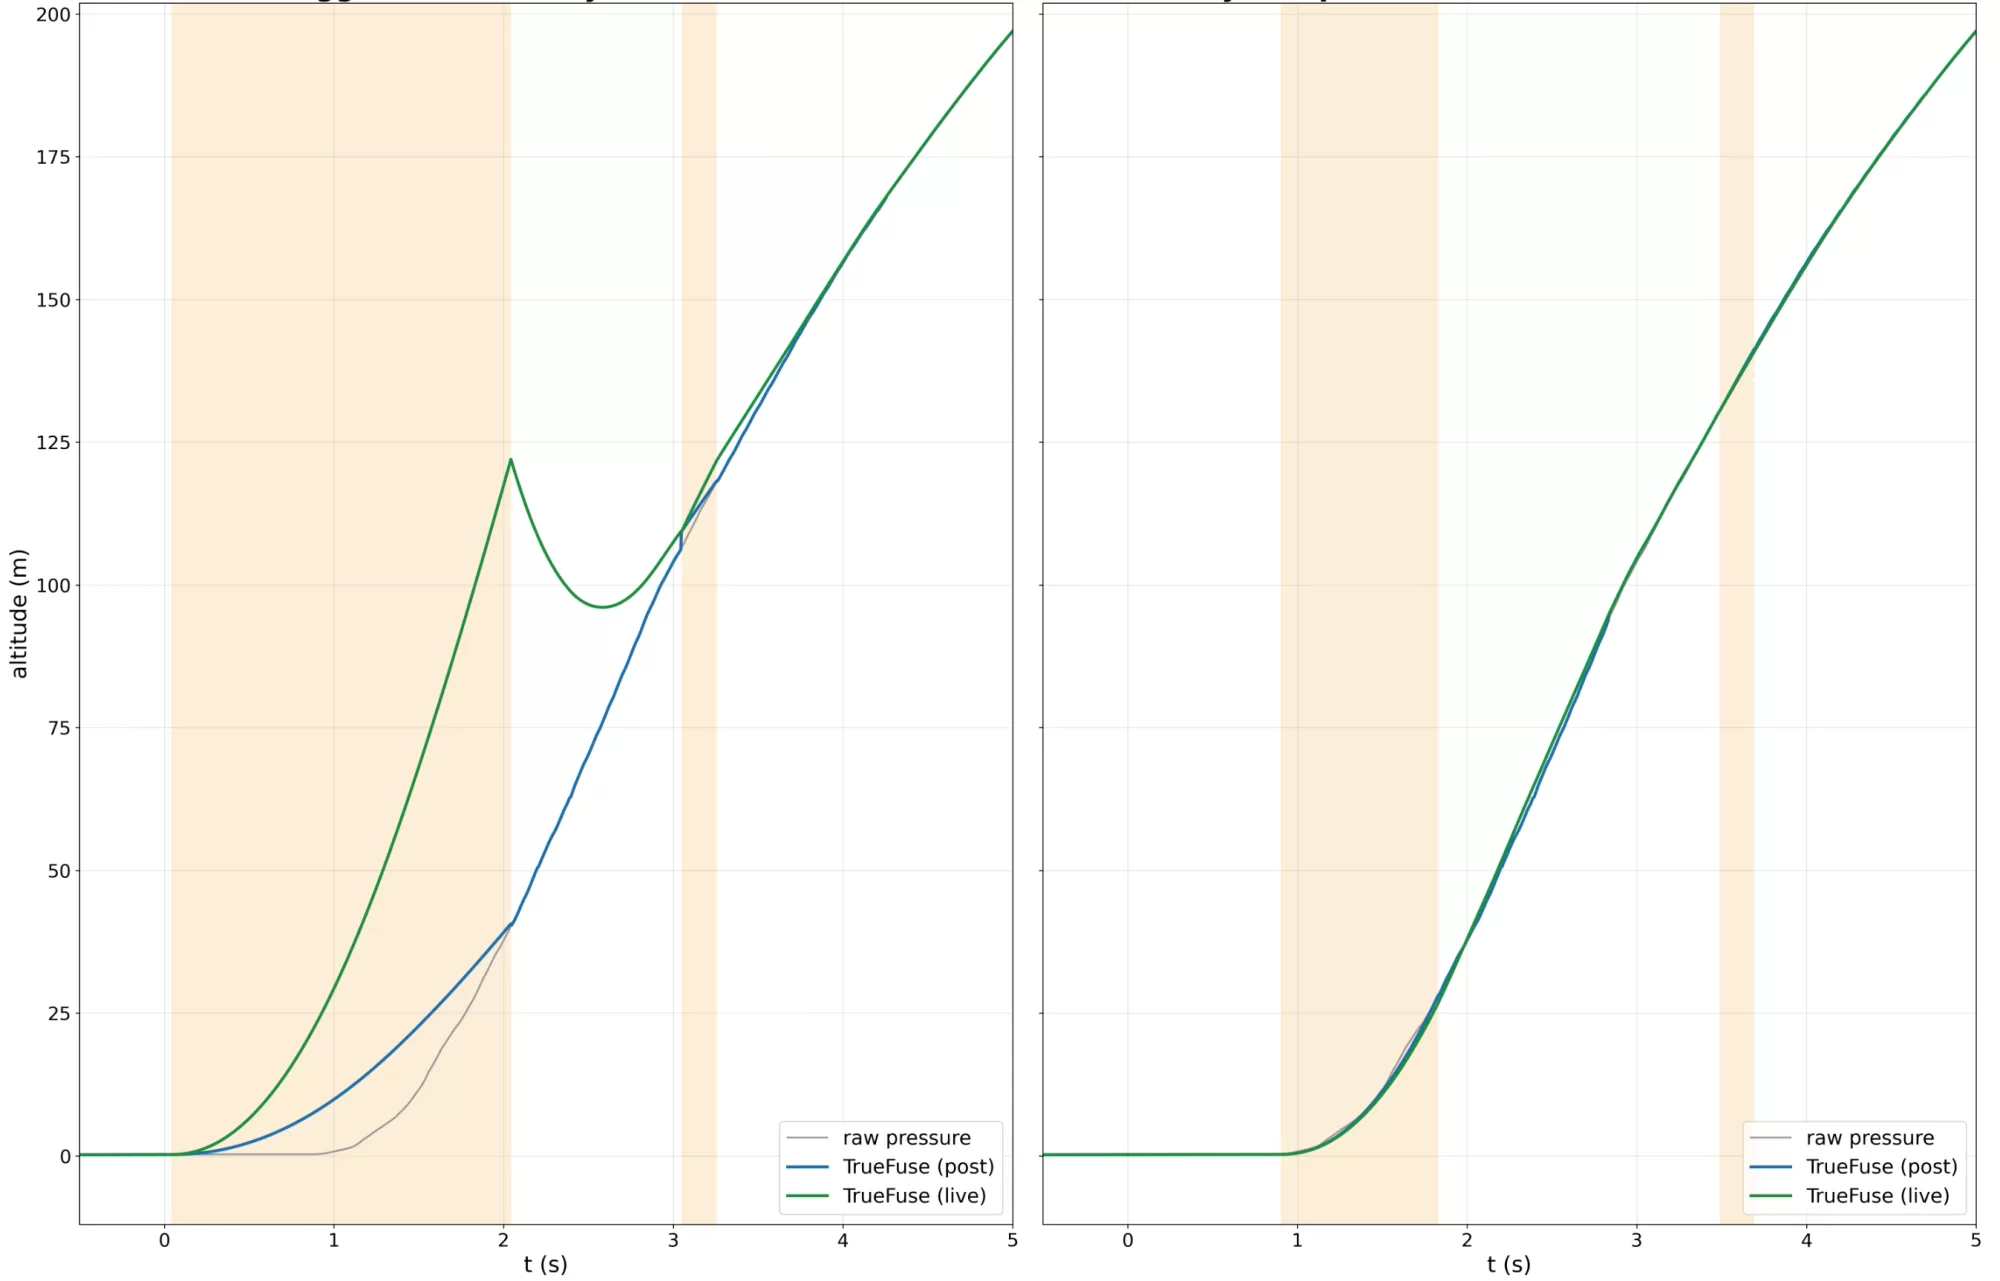 Programming & Electronics ramblings
Barometric pressure sensor lag and how to correct it
Every logged pressure altitude is out of date by the time you write it down. Our firmware used to measure that lag at launch, until a flight log showed it returning 300 ms where the real answer was 111 ms, and TrueFuse started repairing pressure faults that were never there.…
Read more →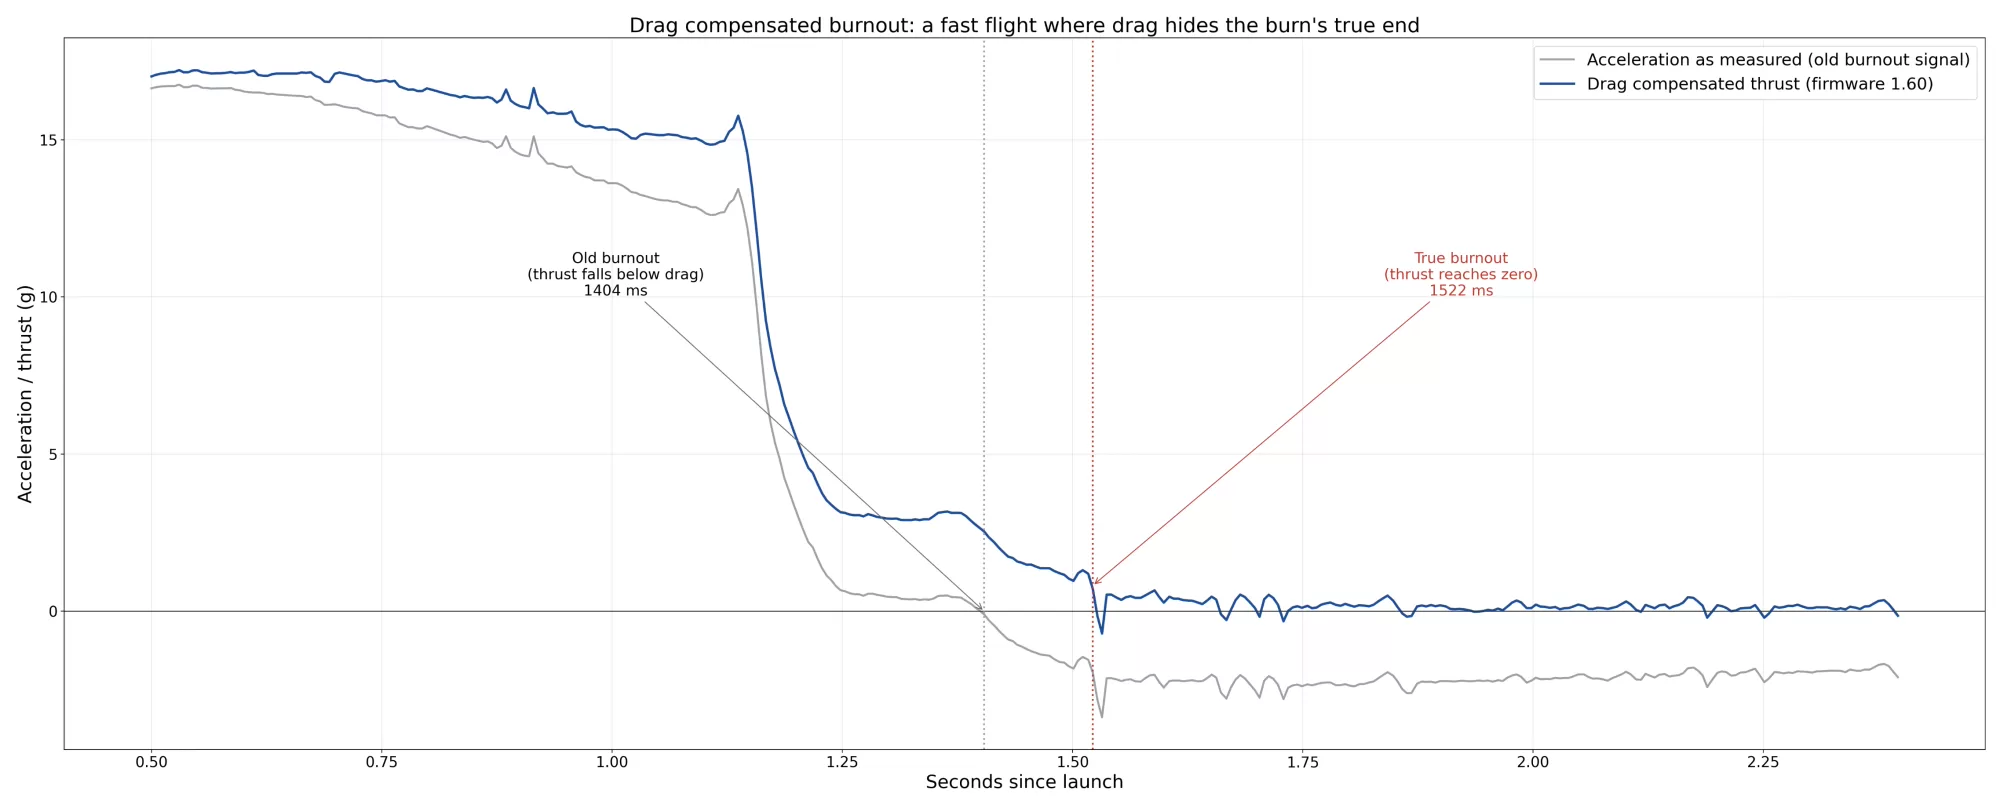 Product Updates
New Nano altimeter firmware (v1.60)
There is a big new update to the Nano firmware. Come and find out about version 1.6
New Nano altimeter firmware (v1.53)
Version 1.53 of our firmware for the Nano. There are some big feature fixes and improvements for the Nano altimeter.
 Product Updates
New Mercury V1 firmware - v2.41 - Changelog
The new version 2.41 firmware is here for the Mercury V1 altimeters, it's the single biggest firmware update we've done yet.
 Product Updates
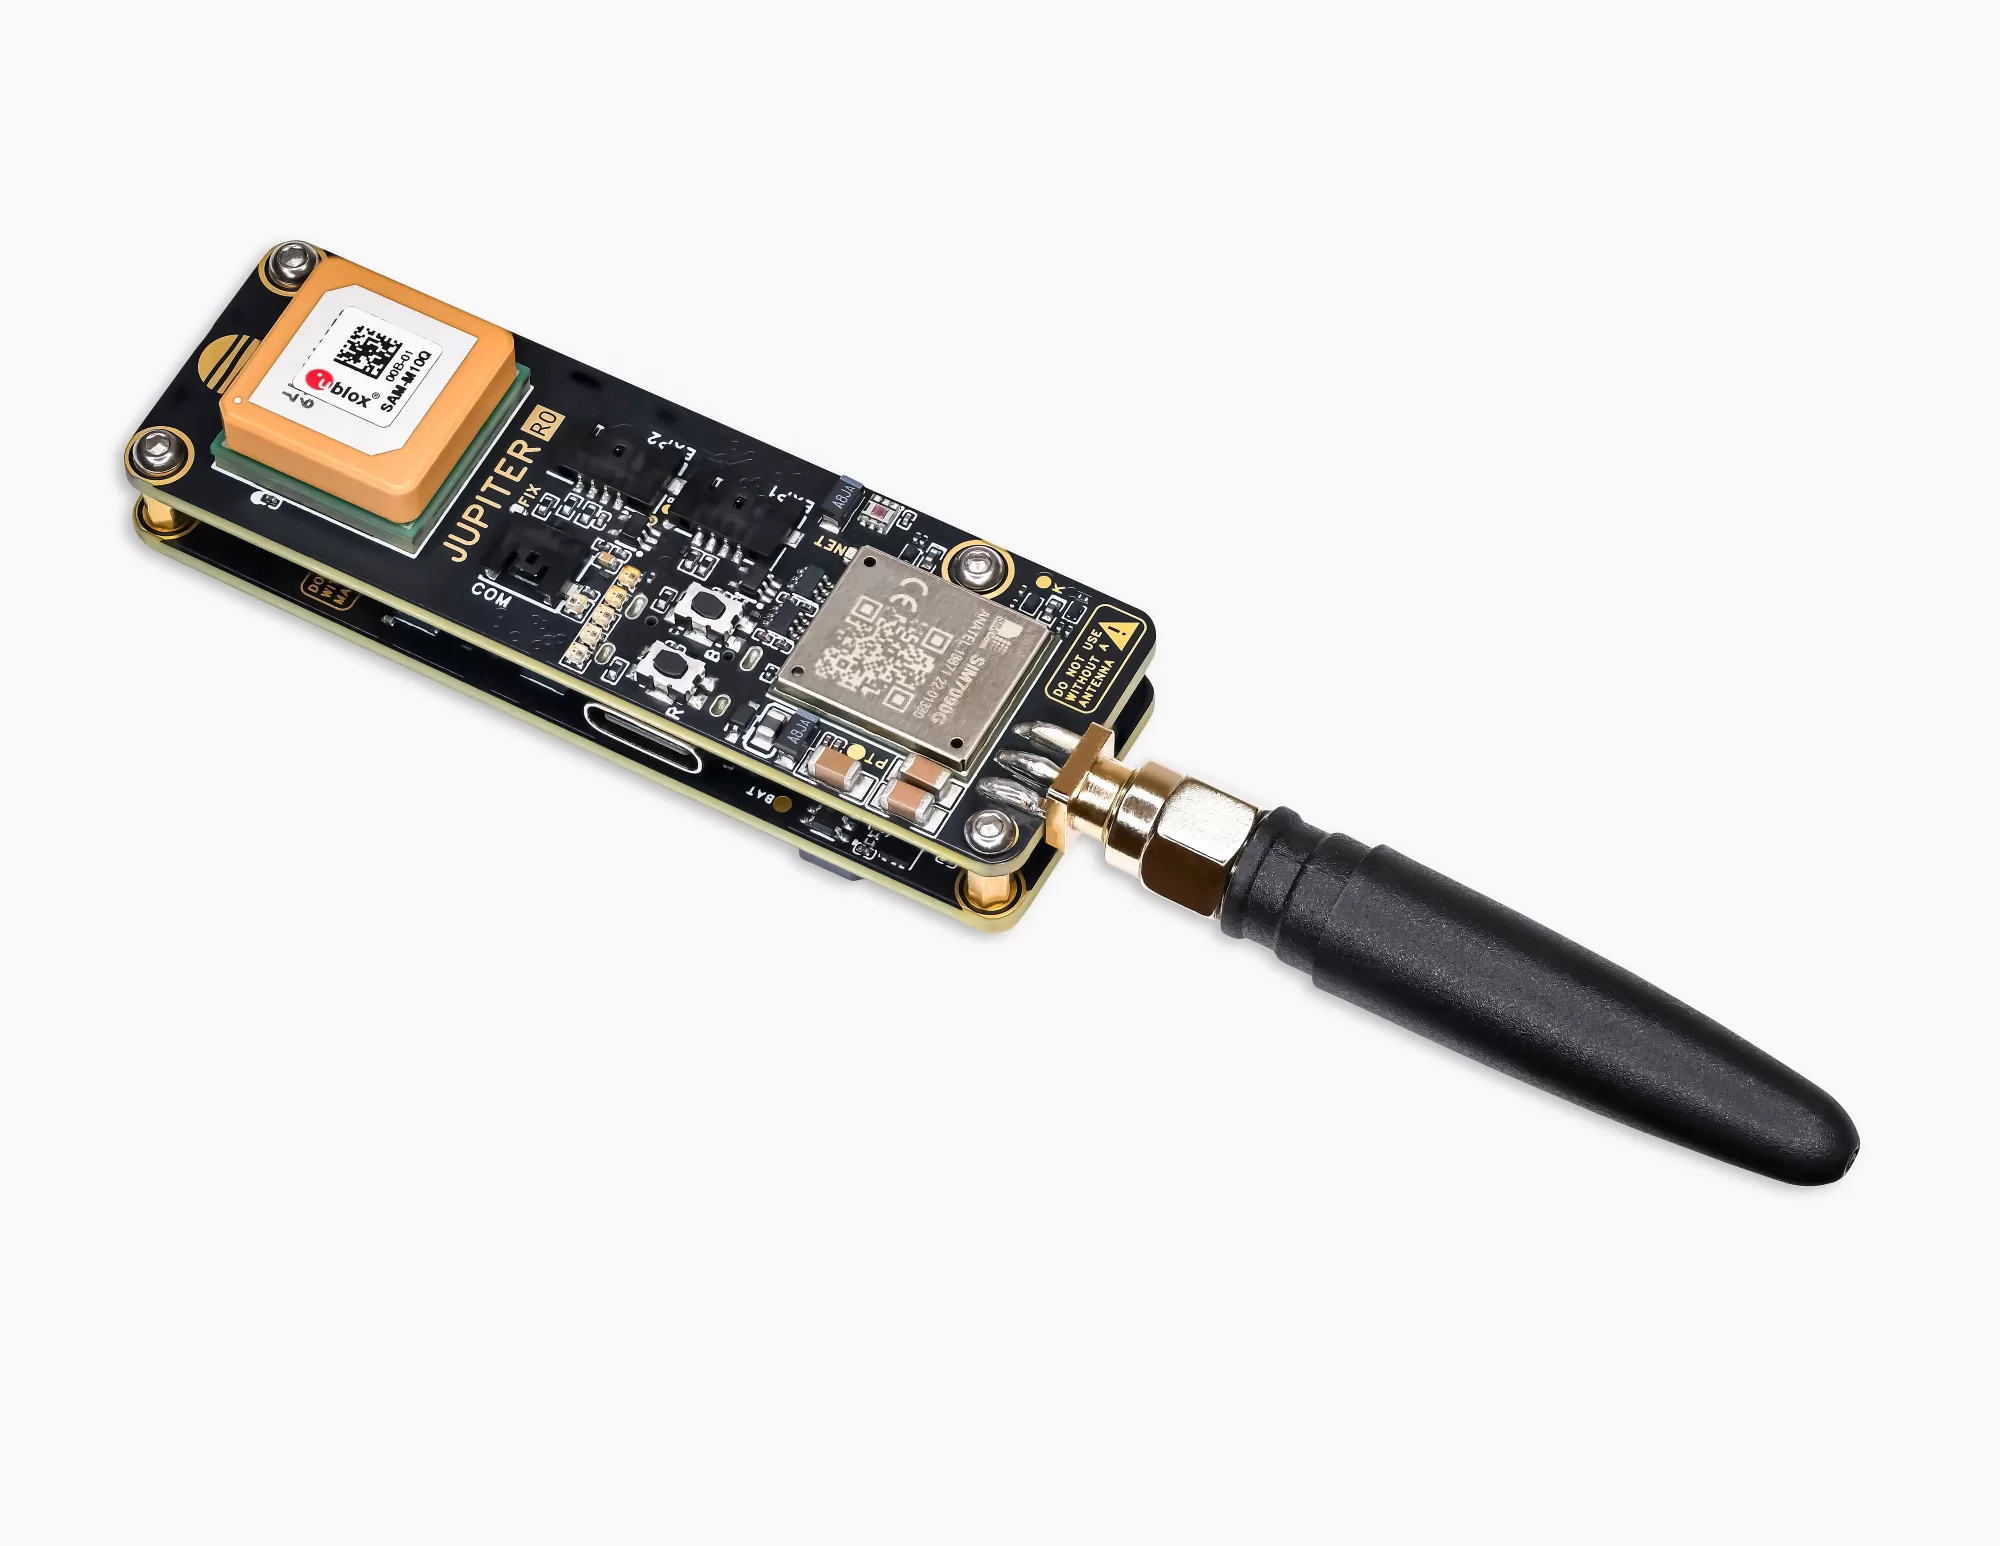
The Jupiter is nearly here
Our flagship flight computer & tracker first revision test boards have arrived.
And the best bit is every part on them is working as planned.
The Jupiter comes with a 10 year line rental included SIM card and cellular communication. It includes 500MB of data which is…
 Product Updates
GNSS/GPS Expansion boards for the Jupiter series products
Our new Jupiter series GNSS expansion boards are ready to go. This allows you to mount a secondary GNSS sensor in a different orientation to the onboard one, offering you extended reliabilty and peace of mind.